Important note: On September 7, 2026, the KITTI and KITTI-360 servers had to be restored to the backed-up state of August 7, 2026. Results within this period have to be resubmitted.

Bird's Eye View Evaluation 2017


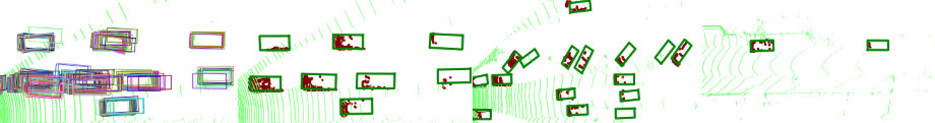
The bird's eye view benchmark consists of 7481 training images and 7518 test images as well as the corresponding point clouds, comprising a total of 80.256 labeled objects. For evaluation, we compute precision-recall curves. To rank the methods we compute average precision. We require that all methods use the same parameter set for all test pairs. Our development kit provides details about the data format as well as MATLAB / C++ utility functions for reading and writing the label files.

We evaluate bird's eye view detection performance using the PASCAL criteria also used for 2D object detection. Far objects are thus filtered based on their bounding box height in the image plane. As only objects also appearing on the image plane are labeled, objects in don't car areas do not count as false positives. We note that the evaluation does not take care of ignoring detections that are not visible on the image plane — these detections might give rise to false positives. For cars we require a bounding box overlap of 70% in bird's eye view, while for pedestrians and cyclists we require an overlap of 50%. Difficulties are defined as follows:

  • Easy: Min. bounding box height: 40 Px, Max. occlusion level: Fully visible, Max. truncation: 15 %
  • Moderate: Min. bounding box height: 25 Px, Max. occlusion level: Partly occluded, Max. truncation: 30 %
  • Hard: Min. bounding box height: 25 Px, Max. occlusion level: Difficult to see, Max. truncation: 50 %

All methods are ranked based on the moderately difficult results.

Note 2: On 08.10.2019, we have followed the suggestions of the Mapillary team in their paper Disentangling Monocular 3D Object Detection and use 40 recall positions instead of the 11 recall positions proposed in the original Pascal VOC benchmark. This results in a more fair comparison of the results, please check their paper. The last leaderboards right before this change can be found here: Object Detection Evaluation, 3D Object Detection Evaluation, Bird's Eye View Evaluation.
Important Policy Update: As more and more non-published work and re-implementations of existing work is submitted to KITTI, we have established a new policy: from now on, only submissions with significant novelty that are leading to a peer-reviewed paper in a conference or journal are allowed. Minor modifications of existing algorithms or student research projects are not allowed. Such work must be evaluated on a split of the training set. To ensure that our policy is adopted, new users must detail their status, describe their work and specify the targeted venue during registration. Furthermore, we will regularly delete all entries that are 6 months old but are still anonymous or do not have a paper associated with them. For conferences, 6 month is enough to determine if a paper has been accepted and to add the bibliography information. For longer review cycles, you need to resubmit your results.
Additional information used by the methods
  • Stereo: Method uses left and right (stereo) images
  • Flow: Method uses optical flow (2 temporally adjacent images)
  • Multiview: Method uses more than 2 temporally adjacent images
  • Laser Points: Method uses point clouds from Velodyne laser scanner
  • Additional training data: Use of additional data sources for training (see details)

Car


Method Setting Code Moderate Easy Hard Runtime Environment
1 VirConv-S code 93.52 % 95.99 % 90.38 % 0.09 s 1 core @ 2.5 Ghz (C/C++)
H. Wu, C. Wen, S. Shi and C. Wang: Virtual Sparse Convolution for Multimodal 3D Object Detection. CVPR 2023.
2 UDeerPEP code 93.40 % 95.34 % 89.07 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
Z. Dong, H. Ji, X. Huang, W. Zhang, X. Zhan and J. Chen: PeP: a Point enhanced Painting method for unified point cloud tasks. 2023.
3 VirConv-T code 92.65 % 96.11 % 89.69 % 0.09 s 1 core @ 2.5 Ghz (C/C++)
H. Wu, C. Wen, S. Shi and C. Wang: Virtual Sparse Convolution for Multimodal 3D Object Detection. CVPR 2023.
4 LongSF code 92.24 % 95.93 % 87.39 % 0.08 s 1 core @ 2.5 Ghz (C/C++)
P. Gao and P. Zhang: LongSF: Long State Fusion with SSMs for Multimodal 3D Object Detection. 2026.
5 kfc 92.19 % 95.92 % 87.27 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
6 auto_test 92.16 % 95.99 % 87.24 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
7 GraR-Po code 92.12 % 95.79 % 87.11 % 0.06 s 1 core @ 2.5 Ghz (Python + C/C++)
H. Yang, Z. Liu, X. Wu, W. Wang, W. Qian, X. He and D. Cai: Graph R-CNN: Towards Accurate 3D Object Detection with Semantic-Decorated Local Graph. ECCV 2022.
8 codif code 92.12 % 95.92 % 87.29 % 0.8 s 1 core @ 2.5 Ghz (C/C++)
9 TSSTDet 92.11 % 95.80 % 89.23 % 0.08 s 1 core @ 2.5 Ghz (C/C++)
H. Hoang, D. Bui and M. Yoo: TSSTDet: Transformation-Based 3-D Object Detection via a Spatial Shape Transformer. IEEE Sensors Journal 2024.
10 MVFusion code 92.10 % 95.22 % 84.98 % 0.06 s 1 core @ 2.5 Ghz (C/C++)
11 LPFusion 92.09 % 95.58 % 87.11 % 0.01 s 1 core @ 2.5 Ghz (Python)
12 MPCF code 92.07 % 95.92 % 87.29 % 0.08 s 1 core @ 2.5 Ghz (C/C++)
P. Gao and P. Zhang: MPCF: Multi-Phase Consolidated Fusion for Multi-Modal 3D Object Detection with Pseudo Point Cloud. 2024.
13 TED code 92.05 % 95.44 % 87.30 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
H. Wu, C. Wen, W. Li, R. Yang and C. Wang: Transformation-Equivariant 3D Object Detection for Autonomous Driving. AAAI 2023.
14 TRTConv-L 92.04 % 95.55 % 87.23 % 0.01 s 1 core @ 2.5 Ghz (Python)
ERROR: Wrong syntax in BIBTEX file.
15 BiLG 91.96 % 95.79 % 87.18 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
16 OV-SMoE 91.92 % 95.79 % 87.14 % 0.08 s 1 core @ 2.5 Ghz (C/C++)
17 ViKIENet 91.87 % 95.69 % 88.99 % 0.04 s 1 core @ 2.5 Ghz (C/C++)
Z. Yu, B. Qiu and A. Khong: ViKIENet: Towards Efficient 3D Object Detection with Virtual Key Instance Enhanced Network. CVPR 2025.
18 VPFNet code 91.86 % 93.02 % 86.94 % 0.06 s 2 cores @ 2.5 Ghz (Python)
H. Zhu, J. Deng, Y. Zhang, J. Ji, Q. Mao, H. Li and Y. Zhang: VPFNet: Improving 3D Object Detection with Virtual Point based LiDAR and Stereo Data Fusion. IEEE Transactions on Multimedia 2022.
19 SFD code 91.85 % 95.64 % 86.83 % 0.1 s 1 core @ 2.5 Ghz (Python + C/C++)
X. Wu, L. Peng, H. Yang, L. Xie, C. Huang, C. Deng, H. Liu and D. Cai: Sparse Fuse Dense: Towards High Quality 3D Detection with Depth Completion. CVPR 2022.
20 SE-SSD
This method makes use of Velodyne laser scans.
code 91.84 % 95.68 % 86.72 % 0.03 s 1 core @ 2.5 Ghz (Python + C/C++)
W. Zheng, W. Tang, L. Jiang and C. Fu: SE-SSD: Self-Ensembling Single-Stage Object Detector From Point Cloud. CVPR 2021.
21 ACFNet 91.78 % 92.91 % 87.06 % 0.11 s 1 core @ 2.5 Ghz (C/C++)
Y. Tian, X. Zhang, X. Wang, J. Xu, J. Wang, R. Ai, W. Gu and W. Ding: ACF-Net: Asymmetric Cascade Fusion for 3D Detection With LiDAR Point Clouds and Images. IEEE Transactions on Intelligent Vehicles 2023.
22 ICD-PSOC 91.76 % 95.27 % 88.49 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
23 GraR-Vo code 91.72 % 95.27 % 86.51 % 0.04 s 1 core @ 2.5 Ghz (C/C++)
H. Yang, Z. Liu, X. Wu, W. Wang, W. Qian, X. He and D. Cai: Graph R-CNN: Towards Accurate 3D Object Detection with Semantic-Decorated Local Graph. ECCV 2022.
24 PVT-SSD 91.63 % 95.23 % 86.43 % 0.05 s 1 core @ 2.5 Ghz (Python + C/C++)
H. Yang, W. Wang, M. Chen, B. Lin, T. He, H. Chen, X. He and W. Ouyang: PVT-SSD: Single-Stage 3D Object Detector with Point-Voxel Transformer. CVPR 2023.
25 SPANet 91.59 % 95.59 % 86.53 % 0.06 s 1 core @ 2.5 Ghz (C/C++)
Y. Ye: SPANet: Spatial and Part-Aware Aggregation Network for 3D Object Detection. Pacific Rim International Conference on Artificial Intelligence 2021.
26 ViKIENet-R 91.56 % 94.87 % 88.55 % 0.06 s 1 core @ 2.5 Ghz (C/C++)
Z. Yu, B. Qiu and A. Khong: ViKIENet: Towards Efficient 3D Object Detection with Virtual Key Instance Enhanced Network. CVPR 2025.
27 CasA code 91.54 % 95.19 % 86.82 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
H. Wu, J. Deng, C. Wen, X. Li and C. Wang: CasA: A Cascade Attention Network for 3D Object Detection from LiDAR point clouds. IEEE Transactions on Geoscience and Remote Sensing 2022.
28 LoGoNet code 91.52 % 95.48 % 87.09 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
X. Li, T. Ma, Y. Hou, B. Shi, Y. Yang, Y. Liu, X. Wu, Q. Chen, Y. Li, Y. Qiao and others: LoGoNet: Towards Accurate 3D Object Detection with Local-to-Global Cross-Modal Fusion. CVPR 2023.
29 GraR-Pi code 91.52 % 95.06 % 86.42 % 0.03 s 1 core @ 2.5 Ghz (C/C++)
H. Yang, Z. Liu, X. Wu, W. Wang, W. Qian, X. He and D. Cai: Graph R-CNN: Towards Accurate 3D Object Detection with Semantic-Decorated Local Graph. ECCV 2022.
30 TRTConv-T 91.49 % 95.27 % 88.93 % 0.05 s 1 core @ 2.5 Ghz (Python + C/C++)
ERROR: Wrong syntax in BIBTEX file.
31 MS-R code 91.49 % 94.69 % 88.47 % 1 s 1 core @ 2.5 Ghz (C/C++)
32 UPIDet code 91.36 % 92.96 % 86.80 % 0.11 s 1 core @ 2.5 Ghz (C/C++)
Y. Zhang, Q. Zhang, J. Hou, Y. Yuan and G. Xing: Unleash the Potential of Image Branch for Cross-modal 3D Object Detection. Thirty-seventh Conference on Neural Information Processing Systems 2023.
33 BADet code 91.32 % 95.23 % 86.48 % 0.14 s 1 core @ 2.5 Ghz (C/C++)
R. Qian, X. Lai and X. Li: BADet: Boundary-Aware 3D Object Detection from Point Clouds. Pattern Recognition 2022.
34 ICD-PSI 91.29 % 94.60 % 88.48 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
35 CasA++ code 91.22 % 94.57 % 88.43 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
H. Wu, J. Deng, C. Wen, X. Li and C. Wang: CasA: A Cascade Attention Network for 3D Object Detection from LiDAR point clouds. IEEE Transactions on Geoscience and Remote Sensing 2022.
36 ImagePG code 91.14 % 94.91 % 86.64 % 1 s 1 core @ 2.5 Ghz (C/C++)
M. Lee, S. Moon, S. Lee, R. Mahjourian and J. Kim: Image-Guided Semantic Pseudo- LiDAR Point Generation for 3D Object Detection. Proceedings of the IEEE/CVF Winter Conference on Applications of Computer Vision (WACV) 2026.
37 3D HANet code 91.13 % 94.33 % 86.33 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
Q. Xia, Y. Chen, G. Cai, G. Chen, D. Xie, J. Su and Z. Wang: 3D HANet: A Flexible 3D Heatmap Auxiliary Network for Object Detection. IEEE Transactions on Geoscience and Remote Sensing 2023.
38 SA-SSD code 91.03 % 95.03 % 85.96 % 0.04 s 1 core @ 2.5 Ghz (Python)
C. He, H. Zeng, J. Huang, X. Hua and L. Zhang: Structure Aware Single-stage 3D Object Detection from Point Cloud. CVPR 2020.
39 L-AUG 91.00 % 94.52 % 88.08 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
T. Cortinhal, I. Gouigah and E. Aksoy: Semantics-aware LiDAR-Only Pseudo Point Cloud Generation for 3D Object Detection. 2023.
40 3D Dual-Fusion code 90.86 % 93.08 % 86.44 % 0.1 s 1 core @ 2.5 Ghz (Python)
Y. Kim, K. Park, M. Kim, D. Kum and J. Choi: 3D Dual-Fusion: Dual-Domain Dual-Query Camera-LiDAR Fusion for 3D Object Detection. arXiv preprint arXiv:2211.13529 2022.
41 GraphAlign(ICCV2023) code 90.73 % 94.46 % 88.34 % 0.03 s GPU @ 2.0 Ghz (Python)
Z. Song, H. Wei, L. Bai, L. Yang and C. Jia: GraphAlign: Enhancing accurate feature alignment by graph matching for multi-modal 3D object detection. Proceedings of the IEEE/CVF International Conference on Computer Vision 2023.
42 MMLab PV-RCNN
This method makes use of Velodyne laser scans.
code 90.65 % 94.98 % 86.14 % 0.08 s 1 core @ 2.5 Ghz (Python + C/C++)
S. Shi, C. Guo, L. Jiang, Z. Wang, J. Shi, X. Wang and H. Li: PV-RCNN: Point-Voxel Feature Set Abstraction for 3D Object Detection. CVPR 2020.
43 SQD code 90.63 % 95.44 % 88.04 % 0.06 s 1 core @ 2.5 Ghz (C/C++)
Y. Mo, Y. Wu, J. Zhao, Z. Hou, W. Huang, Y. Hu, J. Wang and J. Yan: Sparse Query Dense: Enhancing 3D Object Detection with Pseudo Points. ACM MM Oral 2024.
44 VPFNet code 90.52 % 93.94 % 86.25 % 0.2 s 1 core @ 2.5 Ghz (C/C++)
C. Wang, H. Chen and L. Fu: VPFNet: Voxel-Pixel Fusion Network for Multi-class 3D Object Detection. 2021.
C. Wang, H. Chen, Y. Chen, P. Hsiao and L. Fu: VoPiFNet: Voxel-Pixel Fusion Network for Multi-Class 3D Object Detection. IEEE Transactions on Intelligent Transportation Systems 2024.
45 PDV code 90.48 % 94.56 % 86.23 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
J. Hu, T. Kuai and S. Waslander: Point Density-Aware Voxels for LiDAR 3D Object Detection. CVPR 2022.
46 M3DeTR code 90.37 % 94.41 % 85.98 % n/a s GPU @ 1.0 Ghz (Python)
T. Guan, J. Wang, S. Lan, R. Chandra, Z. Wu, L. Davis and D. Manocha: M3DeTR: Multi-representation, Multi- scale, Mutual-relation 3D Object Detection with Transformers. 2021.
47 VoTr-TSD code 90.34 % 94.03 % 86.14 % 0.07 s 1 core @ 2.5 Ghz (C/C++)
J. Mao, Y. Xue, M. Niu, H. Bai, J. Feng, X. Liang, H. Xu and C. Xu: Voxel Transformer for 3D Object Detection. ICCV 2021.
48 DSA-PV-RCNN
This method makes use of Velodyne laser scans.
code 90.13 % 92.42 % 85.93 % 0.08 s 1 core @ 2.5 Ghz (Python + C/C++)
P. Bhattacharyya, C. Huang and K. Czarnecki: SA-Det3D: Self-Attention Based Context-Aware 3D Object Detection. 2021.
49 LumiNet 90.13 % 95.79 % 85.06 % 0.1 s 1 core @ 2.5 Ghz (Python)
50 XView 90.12 % 92.27 % 85.94 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
L. Xie, G. Xu, D. Cai and X. He: X-view: Non-egocentric Multi-View 3D Object Detector. 2021.
51 GraR-VoI code 90.10 % 95.69 % 86.85 % 0.07 s 1 core @ 2.5 Ghz (Python + C/C++)
H. Yang, Z. Liu, X. Wu, W. Wang, W. Qian, X. He and D. Cai: Graph R-CNN: Towards Accurate 3D Object Detection with Semantic-Decorated Local Graph. ECCV 2022.
52 WinMamba code 90.07 % 93.46 % 87.94 % 0.1 s 1 core @ 2.5 Ghz (Python)
53 CAT-Det 90.07 % 92.59 % 85.82 % 0.3 s GPU @ 2.5 Ghz (Python + C/C++)
Y. Zhang, J. Chen and D. Huang: CAT-Det: Contrastively Augmented Transformer for Multi-modal 3D Object Detection. CVPR 2022.
54 3ONet 90.07 % 95.87 % 85.09 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
H. Hoang and M. Yoo: 3ONet: 3-D Detector for Occluded Object Under Obstructed Conditions. IEEE Sensors Journal 2023.
55 PointVit V1 89.95 % 95.94 % 82.40 % .006 s 1 core @ 2.5 Ghz (Python + C/C++)
V. Sood, Bnalin and G. Pandey: Point Virtual Transformer. 2026.
56 SVGA-Net 89.88 % 92.07 % 85.59 % 0.03s 1 core @ 2.5 Ghz (Python + C/C++)
Q. He, Z. Wang, H. Zeng, Y. Zeng and Y. Liu: SVGA-Net: Sparse Voxel-Graph Attention Network for 3D Object Detection from Point Clouds. AAAI 2022.
57 EBM3DOD code 89.86 % 95.64 % 84.56 % 0.12 s 1 core @ 2.5 Ghz (Python)
F. Gustafsson, M. Danelljan and T. Schön: Accurate 3D Object Detection using Energy- Based Models. arXiv preprint arXiv:2012.04634 2020.
58 CIA-SSD
This method makes use of Velodyne laser scans.
code 89.84 % 93.74 % 82.39 % 0.03 s 1 core @ 2.5 Ghz (Python + C/C++)
W. Zheng, W. Tang, S. Chen, L. Jiang and C. Fu: CIA-SSD: Confident IoU-Aware Single-Stage Object Detector From Point Cloud. AAAI 2021.
59 MLF-DET 89.82 % 93.38 % 84.78 % 0.09 s 1 core @ 2.5 Ghz (C/C++)
Z. Lin, Y. Shen, S. Zhou, S. Chen and N. Zheng: MLF-DET: Multi-Level Fusion for Cross- Modal 3D Object Detection. International Conference on Artificial Neural Networks 2023.
60 SparseFormer code 89.81 % 92.48 % 85.36 % 0.06 s 1 core @ 2.5 Ghz (C/C++)
ERROR: Wrong syntax in BIBTEX file.
61 CLOCs_PVCas code 89.80 % 93.05 % 86.57 % 0.1 s 1 core @ 2.5 Ghz (Python)
S. Pang, D. Morris and H. Radha: CLOCs: Camera-LiDAR Object Candidates Fusion for 3D Object Detection . 2020 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2020.
62 GLENet-VR code 89.76 % 93.48 % 84.89 % 0.04 s 1 core @ 2.5 Ghz (C/C++)
Y. Zhang, Q. Zhang, Z. Zhu, J. Hou and Y. Yuan: GLENet: Boosting 3D object detectors with generative label uncertainty estimation. International Journal of Computer Vision 2023.
Y. Zhang, J. Hou and Y. Yuan: A Comprehensive Study of the Robustness for LiDAR-based 3D Object Detectors against Adversarial Attacks. International Journal of Computer Vision 2023.
63 RDIoU code 89.75 % 94.90 % 84.67 % 0.03 s 1 core @ 2.5 Ghz (Python + C/C++)
H. Sheng, S. Cai, N. Zhao, B. Deng, J. Huang, X. Hua, M. Zhao and G. Lee: Rethinking IoU-based Optimization for Single- stage 3D Object Detection. ECCV 2022.
64 PointVit V2 89.67 % 93.59 % 82.12 % .006 s 1 core @ 2.5 Ghz (Python + C/C++)
V. Sood, Bnalin and G. Pandey: Point Virtual Transformer. 2026.
65 EBM3DOD baseline code 89.63 % 95.44 % 84.34 % 0.05 s 1 core @ 2.5 Ghz (Python)
F. Gustafsson, M. Danelljan and T. Schön: Accurate 3D Object Detection using Energy- Based Models. arXiv preprint arXiv:2012.04634 2020.
66 PointVit P1 89.57 % 93.44 % 82.08 % 0.05 s 1 core @ 2.5 Ghz (C/C++)
V. Sood, Bnalin and G. Pandey: Point Virtual Transformer. 2026.
67 3D-CVF at SPA
This method makes use of Velodyne laser scans.
code 89.56 % 93.52 % 82.45 % 0.06 s 1 core @ 2.5 Ghz (C/C++)
J. Yoo, Y. Kim, J. Kim and J. Choi: 3D-CVF: Generating Joint Camera and LiDAR Features Using Cross-View Spatial Feature Fusion for 3D Object Detection. ECCV 2020.
68 OcTr 89.56 % 93.08 % 86.74 % 0.06 s GPU @ 2.5 Ghz (Python + C/C++)
C. Zhou, Y. Zhang, J. Chen and D. Huang: OcTr: Octree-based Transformer for 3D Object Detection. CVPR 2023.
69 Struc info fusion II 89.54 % 95.26 % 82.31 % 0.05 s GPU @ 2.5 Ghz (Python)
P. An, J. Liang, J. Ma, K. Yu and B. Fang: Struc info fusion. Submitted to CVIU 2021.
70 SASA
This method makes use of Velodyne laser scans.
code 89.51 % 92.87 % 86.35 % 0.04 s 1 core @ 2.5 Ghz (Python + C/C++)
C. Chen, Z. Chen, J. Zhang and D. Tao: SASA: Semantics-Augmented Set Abstraction for Point-based 3D Object Detection. arXiv preprint arXiv:2201.01976 2022.
71 Fast-CLOCs 89.49 % 93.03 % 86.40 % 0.1 s GPU @ 2.5 Ghz (Python)
S. Pang, D. Morris and H. Radha: Fast-CLOCs: Fast Camera-LiDAR Object Candidates Fusion for 3D Object Detection. Proceedings of the IEEE/CVF Winter Conference on Applications of Computer Vision (WACV) 2022.
72 IA-SSD (single) code 89.48 % 93.14 % 84.42 % 0.013 s 1 core @ 2.5 Ghz (C/C++)
Y. Zhang, Q. Hu, G. Xu, Y. Ma, J. Wan and Y. Guo: Not All Points Are Equal: Learning Highly Efficient Point-based Detectors for 3D LiDAR Point Clouds. CVPR 2022.
73 CLOCs code 89.48 % 92.91 % 86.42 % 0.1 s 1 core @ 2.5 Ghz (Python)
S. Pang, D. Morris and H. Radha: CLOCs: Camera-LiDAR Object Candidates Fusion for 3D Object Detection . 2020 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2020.
74 DPFusion code 89.47 % 95.20 % 86.49 % 0.07 s 1 core @ 2.5 Ghz (C/C++)
Y. Mo, Y. Wu, J. Zhao, Y. Hu, J. Wang and J. Yan: Enhancing LiDAR Point Features with Foundation Model Priors for 3D Object Detection. ITSC 2025.
75 PA3DNet 89.46 % 93.11 % 84.60 % 0.1 s GPU @ 2.5 Ghz (Python + C/C++)
M. Wang, L. Zhao and Y. Yue: PA3DNet: 3-D Vehicle Detection with Pseudo Shape Segmentation and Adaptive Camera- LiDAR Fusion. IEEE Transactions on Industrial Informatics 2023.
76 PG-RCNN code 89.46 % 93.39 % 86.54 % 0.06 s GPU @ 1.5 Ghz (Python)
I. Koo, I. Lee, S. Kim, H. Kim, W. Jeon and C. Kim: PG-RCNN: Semantic Surface Point Generation for 3D Object Detection. 2023.
77 DFAF3D 89.45 % 93.14 % 84.22 % 0.05 s 1 core @ 2.5 Ghz (Python)
Q. Tang, X. Bai, J. Guo, B. Pan and W. Jiang: DFAF3D: A dual-feature-aware anchor-free single-stage 3D detector for point clouds. Image and Vision Computing 2023.
78 DVF-V 89.42 % 93.12 % 86.50 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
A. Mahmoud, J. Hu and S. Waslander: Dense Voxel Fusion for 3D Object Detection. WACV 2023.
79 Struc info fusion I 89.38 % 94.91 % 84.29 % 0.05 s 1 core @ 2.5 Ghz (Python)
P. An, J. Liang, J. Ma, K. Yu and B. Fang: Struc info fusion. Submitted to CVIU 2021.
80 BtcDet
This method makes use of Velodyne laser scans.
code 89.34 % 92.81 % 84.55 % 0.09 s GPU @ 2.5 Ghz (Python + C/C++)
Q. Xu, Y. Zhong and U. Neumann: Behind the Curtain: Learning Occluded Shapes for 3D Object Detection. Proceedings of the AAAI Conference on Artificial Intelligence 2022.
81 IA-SSD (multi) code 89.33 % 92.79 % 84.35 % 0.014 s 1 core @ 2.5 Ghz (C/C++)
Y. Zhang, Q. Hu, G. Xu, Y. Ma, J. Wan and Y. Guo: Not All Points Are Equal: Learning Highly Efficient Point-based Detectors for 3D LiDAR Point Clouds. CVPR 2022.
82 LGFE 89.22 % 92.94 % 84.22 % 0.03 s 1 core @ 2.5 Ghz (Python)
83 ACDet code 89.21 % 92.87 % 85.80 % 0.05 s 1 core @ 2.5 Ghz (C/C++)
J. Xu, G. Wang, X. Zhang and G. Wan: ACDet: Attentive Cross-view Fusion for LiDAR-based 3D Object Detection. 3DV 2022.
84 DVF-PV 89.20 % 93.08 % 86.28 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
A. Mahmoud, J. Hu and S. Waslander: Dense Voxel Fusion for 3D Object Detection. WACV 2023.
85 STD code 89.19 % 94.74 % 86.42 % 0.08 s GPU @ 2.5 Ghz (Python + C/C++)
Z. Yang, Y. Sun, S. Liu, X. Shen and J. Jia: STD: Sparse-to-Dense 3D Object Detector for Point Cloud. ICCV 2019.
86 Point-GNN
This method makes use of Velodyne laser scans.
code 89.17 % 93.11 % 83.90 % 0.6 s GPU @ 2.5 Ghz (Python)
W. Shi and R. Rajkumar: Point-GNN: Graph Neural Network for 3D Object Detection in a Point Cloud. CVPR 2020.
87 HMFI code 89.17 % 93.04 % 86.37 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
X. Li, B. Shi, Y. Hou, X. Wu, T. Ma, Y. Li and L. He: Homogeneous Multi-modal Feature Fusion and Interaction for 3D Object Detection. ECCV 2022.
88 SSL-PointGNN code 89.16 % 92.92 % 83.99 % 0.56 s GPU @ 1.5 Ghz (Python)
E. Erçelik, E. Yurtsever, M. Liu, Z. Yang, H. Zhang, P. Topçam, M. Listl, Y. Çaylı and A. Knoll: 3D Object Detection with a Self-supervised Lidar Scene Flow Backbone. arXiv preprint arXiv:2205.00705 2022.
89 MoAd code 89.13 % 92.90 % 86.25 % 0.01 s 1 core @ 2.5 Ghz (C/C++)
90 SPG_mini
This method makes use of Velodyne laser scans.
code 89.12 % 92.80 % 86.27 % 0.09 s GPU @ 2.5 Ghz (Python)
Q. Xu, Y. Zhou, W. Wang, C. Qi and D. Anguelov: SPG: Unsupervised Domain Adaptation for 3D Object Detection via Semantic Point Generation. Proceedings of the IEEE conference on computer vision and pattern recognition (ICCV) 2021.
91 EQ-PVRCNN code 89.09 % 94.55 % 86.42 % 0.2 s GPU @ 2.5 Ghz (Python + C/C++)
Z. Yang, L. Jiang, Y. Sun, B. Schiele and J. Jia: A Unified Query-based Paradigm for Point Cloud Understanding. Proceedings of the IEEE Conference on Computer Vision and Pattern Recognition 2022.
92 VoxSeT code 89.07 % 92.70 % 86.29 % 33 ms 1 core @ 2.5 Ghz (C/C++)
C. He, R. Li, S. Li and L. Zhang: Voxel Set Transformer: A Set-to-Set Approach to 3D Object Detection from Point Clouds. CVPR 2022.
93 3DSSD code 89.02 % 92.66 % 85.86 % 0.04 s GPU @ 2.5 Ghz (Python + C/C++)
Z. Yang, Y. Sun, S. Liu and J. Jia: 3DSSD: Point-based 3D Single Stage Object Detector. CVPR 2020.
94 RagNet3D code 89.01 % 92.87 % 86.36 % 0.05 s 1 core @ 2.5 Ghz (C/C++)
J. Chen, Y. Han, Z. Yan, J. Qian, J. Li and J. Yang: Ragnet3d: Learning Distinguishable Representation for Pooled Grids in 3d Object Detection. Available at SSRN 4979473 .
95 EPNet++ 89.00 % 95.41 % 85.73 % 0.1 s GPU @ 2.5 Ghz (Python)
Z. Liu, T. Huang, B. Li, X. Chen, X. Wang and X. Bai: EPNet++: Cascade Bi-Directional Fusion for Multi-Modal 3D Object Detection. IEEE Transactions on Pattern Analysis and Machine Intelligence 2022.
96 Focals Conv code 89.00 % 92.67 % 86.33 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
Y. Chen, Y. Li, X. Zhang, J. Sun and J. Jia: Focal Sparse Convolutional Networks for 3D Object Detection. Proceedings of the IEEE Conference on Computer Vision and Pattern Recognition 2022.
97 USVLab BSAODet code 88.90 % 92.66 % 86.23 % 0.04 s 1 core @ 2.5 Ghz (C/C++)
W. Xiao, Y. Peng, C. Liu, J. Gao, Y. Wu and X. Li: Balanced Sample Assignment and Objective for Single-Model Multi-Class 3D Object Detection. IEEE Transactions on Circuits and Systems for Video Technology 2023.
98 LGD 88.87 % 94.51 % 83.67 % 0.03 s 1 core @ 2.5 Ghz (Python)
99 H^23D R-CNN code 88.87 % 92.85 % 86.07 % 0.03 s 1 core @ 2.5 Ghz (C/C++)
J. Deng, W. Zhou, Y. Zhang and H. Li: From Multi-View to Hollow-3D: Hallucinated Hollow-3D R-CNN for 3D Object Detection. IEEE Transactions on Circuits and Systems for Video Technology 2021.
100 Pyramid R-CNN 88.84 % 92.19 % 86.21 % 0.07 s 1 core @ 2.5 Ghz (C/C++)
J. Mao, M. Niu, H. Bai, X. Liang, H. Xu and C. Xu: Pyramid R-CNN: Towards Better Performance and Adaptability for 3D Object Detection. ICCV 2021.
101 CityBrainLab-CT3D code 88.83 % 92.36 % 84.07 % 0.07 s 1 core @ 2.5 Ghz (Python + C/C++)
H. Sheng, S. Cai, Y. Liu, B. Deng, J. Huang, X. Hua and M. Zhao: Improving 3D Object Detection with Channel- wise Transformer. ICCV 2021.
102 Voxel R-CNN code 88.83 % 94.85 % 86.13 % 0.04 s GPU @ 3.0 Ghz (C/C++)
J. Deng, S. Shi, P. Li, W. Zhou, Y. Zhang and H. Li: Voxel R-CNN: Towards High Performance Voxel-based 3D Object Detection . AAAI 2021.
103 HVNet 88.82 % 92.83 % 83.38 % 0.03 s GPU @ 2.0 Ghz (Python)
M. Ye, S. Xu and T. Cao: HVNet: Hybrid Voxel Network for LiDAR Based 3D Object Detection. CVPR 2020.
104 GD-MAE 88.82 % 94.22 % 83.54 % 0.07 s 1 core @ 2.5 Ghz (Python + C/C++)
H. Yang, T. He, J. Liu, H. Chen, B. Wu, B. Lin, X. He and W. Ouyang: GD-MAE: Generative Decoder for MAE Pre- training on LiDAR Point Clouds. CVPR 2023.
105 IFOD 88.74 % 92.50 % 86.00 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
106 SPG
This method makes use of Velodyne laser scans.
code 88.70 % 94.33 % 85.98 % 0.09 s 1 core @ 2.5 Ghz (Python + C/C++)
Q. Xu, Y. Zhou, W. Wang, C. Qi and D. Anguelov: SPG: Unsupervised Domain Adaptation for 3D Object Detection via Semantic Point Generation. Proceedings of the IEEE conference on computer vision and pattern recognition (ICCV) 2021.
107 DSB-fusion 88.70 % 92.86 % 86.03 % 0.11 s 1 core @ 2.5 Ghz (Python)
108 SIENet code 88.65 % 92.38 % 86.03 % 0.08 s 1 core @ 2.5 Ghz (Python)
Z. Li, Y. Yao, Z. Quan, W. Yang and J. Xie: SIENet: Spatial Information Enhancement Network for 3D Object Detection from Point Cloud. 2021.
109 P2V-RCNN 88.63 % 92.72 % 86.14 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
J. Li, S. Luo, Z. Zhu, H. Dai, A. Krylov, Y. Ding and L. Shao: P2V-RCNN: Point to Voxel Feature Learning for 3D Object Detection from Point Clouds. IEEE Access 2021.
110 FromVoxelToPoint code 88.61 % 92.23 % 86.11 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
J. Li, H. Dai, L. Shao and Y. Ding: From Voxel to Point: IoU-guided 3D Object Detection for Point Cloud with Voxel-to- Point Decoder. MM '21: The 29th ACM International Conference on Multimedia (ACM MM) 2021.
111 HC-MVMM 88.61 % 91.99 % 84.34 % 0.06 s 1 core @ 2.5 Ghz (Python)
112 RangeIoUDet
This method makes use of Velodyne laser scans.
88.59 % 92.28 % 85.83 % 0.02 s GPU @ 2.5 Ghz (Python + C/C++)
Z. Liang, Z. Zhang, M. Zhang, X. Zhao and S. Pu: RangeIoUDet: Range Image Based Real-Time 3D Object Detector Optimized by Intersection Over Union. CVPR 2021.
113 EPNet code 88.47 % 94.22 % 83.69 % 0.1 s 1 core @ 2.5 Ghz (Python + C/C++)
T. Huang, Z. Liu, X. Chen and X. Bai: EPNet: Enhancing Point Features with Image Semantics for 3D Object Detection. ECCV 2020.
114 CenterNet3D 88.46 % 91.80 % 83.62 % 0.04 s GPU @ 1.5 Ghz (Python)
G. Wang, B. Tian, Y. Ai, T. Xu, L. Chen and D. Cao: CenterNet3D:An Anchor free Object Detector for Autonomous Driving. 2020.
115 FARP-Net code 88.45 % 91.20 % 86.01 % 0.06 s GPU @ 2.5 Ghz (Python + C/C++)
T. Xie, L. Wang, K. Wang, R. Li, X. Zhang, H. Zhang, L. Yang, H. Liu and J. Li: FARP-Net: Local-Global Feature Aggregation and Relation-Aware Proposals for 3D Object Detection. IEEE Transactions on Multimedia 2023.
116 RangeRCNN
This method makes use of Velodyne laser scans.
88.40 % 92.15 % 85.74 % 0.06 s GPU @ 2.5 Ghz (Python + C/C++)
Z. Liang, M. Zhang, Z. Zhang, X. Zhao and S. Pu: RangeRCNN: Towards Fast and Accurate 3D Object Detection with Range Image Representation. arXiv preprint arXiv:2009.00206 2020.
117 Patches
This method makes use of Velodyne laser scans.
88.39 % 92.72 % 83.19 % 0.15 s GPU @ 2.0 Ghz
J. Lehner, A. Mitterecker, T. Adler, M. Hofmarcher, B. Nessler and S. Hochreiter: Patch Refinement: Localized 3D Object Detection. arXiv preprint arXiv:1910.04093 2019.
118 3D IoU-Net 88.38 % 94.76 % 81.93 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
J. Li, S. Luo, Z. Zhu, H. Dai, S. Krylov, Y. Ding and L. Shao: 3D IoU-Net: IoU Guided 3D Object Detector for Point Clouds. arXiv preprint arXiv:2004.04962 2020.
119 StructuralIF 88.38 % 91.78 % 85.67 % 0.02 s 8 cores @ 2.5 Ghz (Python)
J. Pei An: Deep structural information fusion for 3D object detection on LiDAR-camera system. Accepted in CVIU 2021.
120 PASS-PV-RCNN-Plus 88.37 % 92.17 % 85.75 % 1 s 1 core @ 2.5 Ghz (Python)
Anonymous: Leveraging Anchor-based LiDAR 3D Object Detection via Point Assisted Sample Selection. will submit to computer vision conference/journal 2024.
121 CLOCs_SecCas 88.23 % 91.16 % 82.63 % 0.1 s 1 core @ 2.5 Ghz (Python)
S. Pang, D. Morris and H. Radha: CLOCs: Camera-LiDAR Object Candidates Fusion for 3D Object Detection. 2020 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2020.
122 UberATG-MMF
This method makes use of Velodyne laser scans.
88.21 % 93.67 % 81.99 % 0.08 s GPU @ 2.5 Ghz (Python)
M. Liang*, B. Yang*, Y. Chen, R. Hu and R. Urtasun: Multi-Task Multi-Sensor Fusion for 3D Object Detection. CVPR 2019.
123 Patches - EMP
This method makes use of Velodyne laser scans.
88.17 % 94.49 % 84.75 % 0.5 s GPU @ 2.5 Ghz (Python)
J. Lehner, A. Mitterecker, T. Adler, M. Hofmarcher, B. Nessler and S. Hochreiter: Patch Refinement: Localized 3D Object Detection. arXiv preprint arXiv:1910.04093 2019.
124 SRDL 88.17 % 92.01 % 85.43 % 0.05 s 1 core @ 2.5 Ghz (Python + C/C++)
ERROR: Wrong syntax in BIBTEX file.
125 LinkNet3D 88.16 % 91.71 % 84.85 % 0.04 s GPU @ 2.5 Ghz (Python)
T. Prasanth, R. Padhy, B. Sivaselvan and S. Bakshi: LinkNet3D: An efficient end-to-end network for 3D object detection. Computers and Electrical Engineering 2026.
126 PointPainting
This method makes use of Velodyne laser scans.
88.11 % 92.45 % 83.36 % 0.4 s GPU @ 2.5 Ghz (Python + C/C++)
S. Vora, A. Lang, B. Helou and O. Beijbom: PointPainting: Sequential Fusion for 3D Object Detection. CVPR 2020.
127 SERCNN
This method makes use of Velodyne laser scans.
88.10 % 94.11 % 83.43 % 0.1 s 1 core @ 2.5 Ghz (Python)
D. Zhou, J. Fang, X. Song, L. Liu, J. Yin, Y. Dai, H. Li and R. Yang: Joint 3D Instance Segmentation and Object Detection for Autonomous Driving. Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition 2020.
128 Associate-3Ddet code 88.09 % 91.40 % 82.96 % 0.05 s 1 core @ 2.5 Ghz (Python + C/C++)
L. Du, X. Ye, X. Tan, J. Feng, Z. Xu, E. Ding and S. Wen: Associate-3Ddet: Perceptual-to-Conceptual Association for 3D Point Cloud Object Detection. The IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR) 2020.
129 HotSpotNet 88.09 % 94.06 % 83.24 % 0.04 s 1 core @ 2.5 Ghz (Python + C/C++)
Q. Chen, L. Sun, Z. Wang, K. Jia and A. Yuille: object as hotspots. Proceedings of the European Conference on Computer Vision (ECCV) 2020.
130 Faraway-Frustum
This method makes use of Velodyne laser scans.
code 88.08 % 91.90 % 85.35 % 0.1 s GPU @ 2.5 Ghz (Python)
H. Zhang, D. Yang, E. Yurtsever, K. Redmill and U. Ozguner: Faraway-frustum: Dealing with lidar sparsity for 3D object detection using fusion. 2021 IEEE International Intelligent Transportation Systems Conference (ITSC) 2021.
131 UberATG-HDNET
This method makes use of Velodyne laser scans.
87.98 % 93.13 % 81.23 % 0.05 s GPU @ 2.5 Ghz (Python)
B. Yang, M. Liang and R. Urtasun: HDNET: Exploiting HD Maps for 3D Object Detection. 2nd Conference on Robot Learning (CoRL) 2018.
132 fshe_voxeln_1 87.87 % 91.34 % 84.82 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
133 Fade 3D code 87.85 % 93.53 % 82.75 % 0.01 s 1 core @ 2.5 Ghz (C/C++)
W. Ye, Q. Xia, H. Wu, Z. Dong, R. Zhong, C. Wang and C. Wen: Fade3D: Fast and Deployable 3D Object Detection for Autonomous Driving. IEEE Transactions on Intelligent Transportation Systems 2025.
134 Fast Point R-CNN
This method makes use of Velodyne laser scans.
87.84 % 90.87 % 80.52 % 0.06 s GPU @ 2.5 Ghz (Python + C/C++)
Y. Chen, S. Liu, X. Shen and J. Jia: Fast Point R-CNN. Proceedings of the IEEE international conference on computer vision (ICCV) 2019.
135 MMLab-PartA^2
This method makes use of Velodyne laser scans.
code 87.79 % 91.70 % 84.61 % 0.08 s GPU @ 2.5 Ghz (Python + C/C++)
S. Shi, Z. Wang, J. Shi, X. Wang and H. Li: From Points to Parts: 3D Object Detection from Point Cloud with Part-aware and Part-aggregation Network. IEEE Transactions on Pattern Analysis and Machine Intelligence 2020.
136 SIF 87.76 % 91.44 % 85.15 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
P. An: SIF. Submitted to CVIU 2021.
137 MVAF-Net code 87.73 % 91.95 % 85.00 % 0.06 s 1 core @ 2.5 Ghz (Python + C/C++)
G. Wang, B. Tian, Y. Zhang, L. Chen, D. Cao and J. Wu: Multi-View Adaptive Fusion Network for 3D Object Detection. arXiv preprint arXiv:2011.00652 2020.
138 MSFASA-3DNet 87.70 % 91.35 % 84.38 % 0.03 s GPU @ 2.5 Ghz (Python)
T. Prasanth, R. Padhy and B. Sivaselvan: MSFASA-3DNet: Multi-Scale Feature Aggregation and Spatial Attention for 3D Object Detection. IEEE Transactions on Artificial Intelligence 2026.
139 DVFENet 87.68 % 90.93 % 84.60 % 0.05 s 1 core @ 2.5 Ghz (Python + C/C++)
Y. He, G. Xia, Y. Luo, L. Su, Z. Zhang, W. Li and P. Wang: DVFENet: Dual-branch Voxel Feature Extraction Network for 3D Object Detection. Neurocomputing 2021.
140 S-AT GCN 87.68 % 90.85 % 84.20 % 0.02 s GPU @ 2.0 Ghz (Python)
L. Wang, C. Wang, X. Zhang, T. Lan and J. Li: S-AT GCN: Spatial-Attention Graph Convolution Network based Feature Enhancement for 3D Object Detection. CoRR 2021.
141 RangeDet (Official) code 87.67 % 90.93 % 82.92 % 0.02 s 1 core @ 2.5 Ghz (C/C++)
L. Fan, X. Xiong, F. Wang, N. Wang and Z. Zhang: RangeDet: In Defense of Range View for LiDAR-Based 3D Object Detection. Proceedings of the IEEE/CVF International Conference on Computer Vision (ICCV) 2021.
142 DynaMo3D 87.66 % 91.11 % 84.43 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
143 MODet
This method makes use of Velodyne laser scans.
87.56 % 90.80 % 82.69 % 0.05 s GTX1080Ti
Y. Zhang, Z. Xiang, C. Qiao and S. Chen: Accurate and Real-Time Object Detection Based on Bird's Eye View on 3D Point Clouds. 2019 International Conference on 3D Vision (3DV) 2019.
144 AB3DMOT
This method makes use of Velodyne laser scans.
This is an online method (no batch processing).
code 87.53 % 91.99 % 81.03 % 0.0047s 1 core @ 2.5 Ghz (Python)
X. Weng and K. Kitani: A Baseline for 3D Multi-Object Tracking. arXiv:1907.03961 2019.
145 DSFNet 87.52 % 90.95 % 82.11 % 0.03 s GPU @ 2.5 Ghz (Python)
T. Prasanth, R. Padhy and B. Sivaselvan: LiDAR Sensor-Based Dual-Scale Fusion Approach for Bird’s-Eye View Sensing in Autonomous Vehicles. IEEE Sensors Letters 2025.
146 SeSame-point code 87.49 % 90.84 % 83.77 % N/A s TITAN RTX @ 1.35 Ghz (Python)
H. O, C. Yang and K. Huh: SeSame: Simple, Easy 3D Object Detection with Point-Wise Semantics. Proceedings of the Asian Conference on Computer Vision (ACCV) 2024.
147 PointRGCN 87.49 % 91.63 % 80.73 % 0.26 s GPU @ V100 (Python)
J. Zarzar, S. Giancola and B. Ghanem: PointRGCN: Graph Convolution Networks for 3D Vehicles Detection Refinement. ArXiv 2019.
148 MGAF-3DSSD code 87.47 % 92.70 % 82.19 % 0.1 s 1 core @ 2.5 Ghz (Python)
J. Li, H. Dai, L. Shao and Y. Ding: Anchor-free 3D Single Stage Detector with Mask-Guided Attention for Point Cloud. MM '21: The 29th ACM International Conference on Multimedia (ACM MM) 2021.
149 PC-CNN-V2
This method makes use of Velodyne laser scans.
87.40 % 91.19 % 79.35 % 0.5 s GPU @ 2.5 Ghz (Matlab + C/C++)
X. Du, M. Ang, S. Karaman and D. Rus: A General Pipeline for 3D Detection of Vehicles. 2018 IEEE International Conference on Robotics and Automation (ICRA) 2018.
150 MMLab-PointRCNN
This method makes use of Velodyne laser scans.
code 87.39 % 92.13 % 82.72 % 0.1 s GPU @ 2.5 Ghz (Python + C/C++)
S. Shi, X. Wang and H. Li: Pointrcnn: 3d object proposal generation and detection from point cloud. Proceedings of the IEEE Conference on Computer Vision and Pattern Recognition 2019.
151 Sem-Aug
This method makes use of Velodyne laser scans.
87.37 % 93.35 % 82.43 % 0.1 s GPU @ 2.5 Ghz (Python)
L. Zhao, M. Wang and Y. Yue: Sem-Aug: Improving Camera-LiDAR Feature Fusion With Semantic Augmentation for 3D Vehicle Detection. IEEE Robotics and Automation Letters 2022.
152 VPFnet 87.36 % 90.31 % 82.63 % 0.02 s 1 core @ 2.5 Ghz (C/C++)
153 MAFF-Net(DAF-Pillar) 87.34 % 90.79 % 77.66 % 0.04 s 1 core @ 2.5 Ghz (Python + C/C++)
Z. Zhang, Z. Liang, M. Zhang, X. Zhao, Y. Ming, T. Wenming and S. Pu: MAFF-Net: Filter False Positive for 3D Vehicle Detection with Multi-modal Adaptive Feature Fusion. arXiv preprint arXiv:2009.10945 2020.
154 fsh_l_1_4 87.30 % 89.50 % 84.61 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
155 Harmonic PointPillar code 87.28 % 90.89 % 82.54 % 0.01 s 1 core @ 2.5 Ghz (Python)
H. Zhang, J. Mekala, Z. Nain, J. Park and H. Jung: 3D Harmonic Loss: Towards Task-consistent and Time-friendly 3D Object Detection for V2X Orchestration. will submit to IEEE Transactions on Vehicular Technology 2022.
156 PASS-PointPillar 87.23 % 91.07 % 81.98 % 1 s 1 core @ 2.5 Ghz (C/C++)
Anonymous: Leveraging Anchor-based LiDAR 3D Object Detection via Point Assisted Sample Selection. will submit to computer vision conference/journal 2024.
157 saf_u 87.22 % 89.72 % 84.27 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
158 HRI-VoxelFPN 87.21 % 92.75 % 79.82 % 0.02 s GPU @ 2.5 Ghz (Python + C/C++)
H. Kuang, B. Wang, J. An, M. Zhang and Z. Zhang: Voxel-FPN:multi-scale voxel feature aggregation in 3D object detection from point clouds. sensors 2020.
159 PCNet3D++ 87.17 % 90.13 % 83.10 % 0.05 s GPU @ 2.5 Ghz (Python)
T. Prasanth, R. Padhy and B. Sivaselvan: PCNet3D++: A pillar-based cascaded 3D object detection model with an enhanced 2D backbone. Image and Vision Computing 2025.
160 epBRM
This method makes use of Velodyne laser scans.
code 87.13 % 90.70 % 81.92 % 0.1 s GPU @ >3.5 Ghz (Python + C/C++)
K. Shin: Improving a Quality of 3D Object Detection by Spatial Transformation Mechanism. arXiv preprint arXiv:1910.04853 2019.
161 M3DNet 86.97 % 90.27 % 81.95 % 0.5 s 1 core @ 2.5 Ghz (C/C++)
T. Prasanth, R. Padhy and B. Sivaselvan: M3DNet: Minimalist 3D Detection Backbone for Efficient and Accurate 3D Object Detection. Proceedings of the 18th International Conference on Agents and Artificial Intelligence (ICAART) 2026.
162 SARPNET 86.92 % 92.21 % 81.68 % 0.05 s 1 core @ 2.5 Ghz (Python + C/C++)
Y. Ye, H. Chen, C. Zhang, X. Hao and Z. Zhang: SARPNET: Shape Attention Regional Proposal Network for LiDAR-based 3D Object Detection. Neurocomputing 2019.
163 SeSame-pillar code 86.88 % 90.61 % 81.93 % N/A s TITAN RTX @ 1.35 Ghz (Python)
H. O, C. Yang and K. Huh: SeSame: Simple, Easy 3D Object Detection with Point-Wise Semantics. Proceedings of the Asian Conference on Computer Vision (ACCV) 2024.
164 ARPNET 86.81 % 90.06 % 79.41 % 0.08 s GPU @ 2.5 Ghz (Python + C/C++)
Y. Ye, C. Zhang and X. Hao: ARPNET: attention region proposal network for 3D object detection. Science China Information Sciences 2019.
165 C-GCN 86.78 % 91.11 % 80.09 % 0.147 s GPU @ V100 (Python)
J. Zarzar, S. Giancola and B. Ghanem: PointRGCN: Graph Convolution Networks for 3D Vehicles Detection Refinement. ArXiv 2019.
166 PointPillars
This method makes use of Velodyne laser scans.
code 86.56 % 90.07 % 82.81 % 16 ms 1080ti GPU and Intel i7 CPU
A. Lang, S. Vora, H. Caesar, L. Zhou, J. Yang and O. Beijbom: PointPillars: Fast Encoders for Object Detection from Point Clouds. CVPR 2019.
167 TANet code 86.54 % 91.58 % 81.19 % 0.035s GPU @ 2.5 Ghz (Python + C/C++)
Z. Liu, X. Zhao, T. Huang, R. Hu, Y. Zhou and X. Bai: TANet: Robust 3D Object Detection from Point Clouds with Triple Attention. AAAI 2020.
168 PCNet3D 86.54 % 90.09 % 81.43 % 0.05 s GPU @ 2.5 Ghz (Python)
T. Prasanth, R. Padhy and B. Sivaselvan: PCNet3D: A Pillar Based Cascaded 3D Object Detection Model Using LiDAR Point Cloud. International Conference on Computer Vision and Image Processing 2024.
169 fsh_saf_1 86.48 % 89.67 % 83.73 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
170 SCNet
This method makes use of Velodyne laser scans.
86.48 % 90.07 % 81.30 % 0.04 s GPU @ 3.0 Ghz (Python)
Z. Wang, H. Fu, L. Wang, L. Xiao and B. Dai: SCNet: Subdivision Coding Network for Object Detection Based on 3D Point Cloud. IEEE Access 2019.
171 SegVoxelNet 86.37 % 91.62 % 83.04 % 0.04 s 1 core @ 2.5 Ghz (Python)
H. Yi, S. Shi, M. Ding, J. Sun, K. Xu, H. Zhou, Z. Wang, S. Li and G. Wang: SegVoxelNet: Exploring Semantic Context and Depth-aware Features for 3D Vehicle Detection from Point Cloud. ICRA 2020.
172 TriPlane-Lite 86.27 % 90.75 % 81.21 % 0.02 s 1 core @ 2.5 Ghz (C/C++)
Anonymous: Under review. Under review 2026.
173 3D IoU Loss
This method makes use of Velodyne laser scans.
86.22 % 91.36 % 81.20 % 0.08 s GPU @ 2.5 Ghz (Python + C/C++)
D. Zhou, J. Fang, X. Song, C. Guan, J. Yin, Y. Dai and R. Yang: IoU Loss for 2D/3D Object Detection. International Conference on 3D Vision (3DV) 2019.
174 SeSame-pillar w/scor code 86.11 % 90.43 % 81.38 % N/A s 1 core @ 2.5 Ghz (C/C++)
H. O, C. Yang and K. Huh: SeSame: Simple, Easy 3D Object Detection with Point-Wise Semantics. Proceedings of the Asian Conference on Computer Vision (ACCV) 2024.
175 R-GCN 86.05 % 91.91 % 81.05 % 0.16 s GPU @ 2.5 Ghz (Python)
J. Zarzar, S. Giancola and B. Ghanem: PointRGCN: Graph Convolution Networks for 3D Vehicles Detection Refinement. ArXiv 2019.
176 UberATG-PIXOR++
This method makes use of Velodyne laser scans.
86.01 % 93.28 % 80.11 % 0.035 s GPU @ 2.5 Ghz (Python)
B. Yang, M. Liang and R. Urtasun: HDNET: Exploiting HD Maps for 3D Object Detection. 2nd Conference on Robot Learning (CoRL) 2018.
177 HINTED code 86.01 % 90.61 % 79.29 % 0.04 s 1 core @ 2.5 Ghz (C/C++)
Q. Xia, W. Ye, H. Wu, S. Zhao, L. Xing, X. Huang, J. Deng, X. Li, C. Wen and C. Wang: HINTED: Hard Instance Enhanced Detector with Mixed-Density Feature Fusion for Sparsely- Supervised 3D Object Detection. Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition 2024.
178 PL++: PV-RCNN++
This method uses stereo information.
This method makes use of Velodyne laser scans.
85.89 % 91.76 % 81.29 % 0.342 s RTX 4060Ti (Python)
X. Gong, X. Huang, S. Chen and B. Zhang: Enhancing 3D Detection Accuracy in Autonomous Driving through Pseudo-LiDAR Augmentation and Downsampling. 2024 International Conference on Image Processing, Computer Vision and Machine Learning (ICICML) 2024.
179 BASE
This method uses stereo information.
This method makes use of Velodyne laser scans.
85.88 % 90.54 % 81.10 % N/A s GPU @ 2.5 Ghz (Python)
180 Sem-Aug-PointRCNN++ 85.88 % 91.68 % 83.37 % 0.1 s 8 cores @ 3.0 Ghz (Python)
L. Zhao, M. Wang and Y. Yue: Sem-Aug: Improving Camera-LiDAR Feature Fusion With Semantic Augmentation for 3D Vehicle Detection. IEEE Robotics and Automation Letters 2022.
181 DASS 85.85 % 91.74 % 80.97 % 0.09 s 1 core @ 2.0 Ghz (Python)
O. Unal, L. Van Gool and D. Dai: Improving Point Cloud Semantic Segmentation by Learning 3D Object Detection. Proceedings of the IEEE/CVF Winter Conference on Applications of Computer Vision (WACV) 2021.
182 F-ConvNet
This method makes use of Velodyne laser scans.
code 85.84 % 91.51 % 76.11 % 0.47 s GPU @ 2.5 Ghz (Python + C/C++)
Z. Wang and K. Jia: Frustum ConvNet: Sliding Frustums to Aggregate Local Point-Wise Features for Amodal 3D Object Detection. IROS 2019.
183 PI-RCNN 85.81 % 91.44 % 81.00 % 0.1 s 1 core @ 2.5 Ghz (Python)
L. Xie, C. Xiang, Z. Yu, G. Xu, Z. Yang, D. Cai and X. He: PI-RCNN: An Efficient Multi-sensor 3D Object Detector with Point-based Attentive Cont-conv Fusion Module. AAAI 2020 : The Thirty-Fourth AAAI Conference on Artificial Intelligence 2020.
184 PointRGBNet 85.73 % 91.39 % 80.68 % 0.08 s 4 cores @ 2.5 Ghz (Python + C/C++)
P. Xie Desheng: Real-time Detection of 3D Objects Based on Multi-Sensor Information Fusion. Automotive Engineering 2022.
185 SeSame-voxel code 85.62 % 89.86 % 80.95 % N/A s TITAN RTX @ 1.35 Ghz (Python)
H. O, C. Yang and K. Huh: SeSame: Simple, Easy 3D Object Detection with Point-Wise Semantics. Proceedings of the Asian Conference on Computer Vision (ACCV) 2024.
186 UberATG-ContFuse
This method makes use of Velodyne laser scans.
85.35 % 94.07 % 75.88 % 0.06 s GPU @ 2.5 Ghz (Python)
M. Liang, B. Yang, S. Wang and R. Urtasun: Deep Continuous Fusion for Multi-Sensor 3D Object Detection. ECCV 2018.
187 PFF3D
This method makes use of Velodyne laser scans.
code 85.08 % 89.61 % 80.42 % 0.05 s GPU @ 3.0 Ghz (Python + C/C++)
L. Wen and K. Jo: Fast and Accurate 3D Object Detection for Lidar-Camera-Based Autonomous Vehicles Using One Shared Voxel-Based Backbone. IEEE Access 2021.
188 AVOD
This method makes use of Velodyne laser scans.
code 84.95 % 89.75 % 78.32 % 0.08 s Titan X (pascal)
J. Ku, M. Mozifian, J. Lee, A. Harakeh and S. Waslander: Joint 3D Proposal Generation and Object Detection from View Aggregation. IROS 2018.
189 WS3D
This method makes use of Velodyne laser scans.
84.93 % 90.96 % 77.96 % 0.1 s GPU @ 2.5 Ghz (Python)
Q. Meng, W. Wang, T. Zhou, J. Shen, L. Van Gool and D. Dai: Weakly Supervised 3D Object Detection from Lidar Point Cloud. 2020.
190 AVOD-FPN
This method makes use of Velodyne laser scans.
code 84.82 % 90.99 % 79.62 % 0.1 s Titan X (Pascal)
J. Ku, M. Mozifian, J. Lee, A. Harakeh and S. Waslander: Joint 3D Proposal Generation and Object Detection from View Aggregation. IROS 2018.
191 F-PointNet
This method makes use of Velodyne laser scans.
code 84.67 % 91.17 % 74.77 % 0.17 s GPU @ 3.0 Ghz (Python)
C. Qi, W. Liu, C. Wu, H. Su and L. Guibas: Frustum PointNets for 3D Object Detection from RGB-D Data. arXiv preprint arXiv:1711.08488 2017.
192 mmFUSION code 84.60 % 90.35 % 79.82 % 1s 1 core @ 2.5 Ghz (Python)
J. Ahmad and A. Del Bue: mmFUSION: Multimodal Fusion for 3D Objects Detection. arXiv preprint arXiv:2311.04058 2023.
193 AFCAP 84.11 % 87.87 % 80.19 % 0.1 s 1 core @ 2.5 Ghz (Python)
194 3DBN
This method makes use of Velodyne laser scans.
83.94 % 89.66 % 76.50 % 0.13s 1080Ti (Python+C/C++)
X. Li, J. Guivant, N. Kwok and Y. Xu: 3D Backbone Network for 3D Object Detection. CoRR 2019.
195 M-VPFnet 83.39 % 87.09 % 78.65 % 0.05 s 1 core @ 2.5 Ghz (Python)
196 EOTL code 83.14 % 89.10 % 71.41 % TBD s 1 core @ 2.5 Ghz (Python + C/C++)
R. Yang, Z. Yan, T. Yang, Y. Wang and Y. Ruichek: Efficient Online Transfer Learning for Road Participants Detection in Autonomous Driving. IEEE Sensors Journal 2023.
197 MLOD
This method makes use of Velodyne laser scans.
code 82.68 % 90.25 % 77.97 % 0.12 s GPU @ 1.5 Ghz (Python)
J. Deng and K. Czarnecki: MLOD: A multi-view 3D object detection based on robust feature fusion method. arXiv preprint arXiv:1909.04163 2019.
198 BirdNet+
This method makes use of Velodyne laser scans.
code 81.85 % 87.43 % 75.36 % 0.11 s Titan Xp (PyTorch)
A. Barrera, J. Beltrán, C. Guindel, J. Iglesias and F. García: BirdNet+: Two-Stage 3D Object Detection in LiDAR through a Sparsity-Invariant Bird’s Eye View. IEEE Access 2021.
199 DMF
This method uses stereo information.
80.29 % 84.64 % 76.05 % 0.2 s 1 core @ 2.5 Ghz (Python + C/C++)
X. J. Chen and W. Xu: Disparity-Based Multiscale Fusion Network for Transportation Detection. IEEE Transactions on Intelligent Transportation Systems 2022.
200 UberATG-PIXOR
This method makes use of Velodyne laser scans.
80.01 % 83.97 % 74.31 % 0.035 s TITAN Xp (Python)
B. Yang, W. Luo and R. Urtasun: PIXOR: Real-time 3D Object Detection from Point Clouds. CVPR 2018.
201 MV3D (LIDAR)
This method makes use of Velodyne laser scans.
78.98 % 86.49 % 72.23 % 0.24 s GPU @ 2.5 Ghz (Python + C/C++)
X. Chen, H. Ma, J. Wan, B. Li and T. Xia: Multi-View 3D Object Detection Network for Autonomous Driving. CVPR 2017.
202 DSGN++
This method uses stereo information.
code 78.94 % 88.55 % 69.74 % 0.2 s GeForce RTX 2080Ti
Y. Chen, S. Huang, S. Liu, B. Yu and J. Jia: DSGN++: Exploiting Visual-Spatial Relation for Stereo-Based 3D Detectors. IEEE Transactions on Pattern Analysis and Machine Intelligence 2022.
203 MV3D
This method makes use of Velodyne laser scans.
78.93 % 86.62 % 69.80 % 0.36 s GPU @ 2.5 Ghz (Python + C/C++)
X. Chen, H. Ma, J. Wan, B. Li and T. Xia: Multi-View 3D Object Detection Network for Autonomous Driving. CVPR 2017.
204 StereoDistill 78.59 % 89.03 % 69.34 % 0.4 s 1 core @ 2.5 Ghz (Python)
Z. Liu, X. Ye, X. Tan, D. Errui, Y. Zhou and X. Bai: StereoDistill: Pick the Cream from LiDAR for Distilling Stereo-based 3D Object Detection. Proceedings of the AAAI Conference on Artificial Intelligence 2023.
205 MMLAB LIGA-Stereo
This method uses stereo information.
code 76.78 % 88.15 % 67.40 % 0.4 s 1 core @ 2.5 Ghz (Python + C/C++)
X. Guo, S. Shi, X. Wang and H. Li: LIGA-Stereo: Learning LiDAR Geometry Aware Representations for Stereo-based 3D Detector. Proceedings of the IEEE/CVF International Conference on Computer Vision (ICCV) 2021.
206 RCD 75.83 % 82.26 % 69.61 % 0.1 s GPU @ 2.5 Ghz (Python)
A. Bewley, P. Sun, T. Mensink, D. Anguelov and C. Sminchisescu: Range Conditioned Dilated Convolutions for Scale Invariant 3D Object Detection. Conference on Robot Learning (CoRL) 2020.
207 LaserNet 74.52 % 79.19 % 68.45 % 12 ms GPU @ 2.5 Ghz (C/C++)
G. Meyer, A. Laddha, E. Kee, C. Vallespi-Gonzalez and C. Wellington: LaserNet: An Efficient Probabilistic 3D Object Detector for Autonomous Driving. Proceedings of the IEEE Conference on Computer Vision and Pattern Recognition (CVPR) 2019.
208 PL++ (SDN+GDC)
This method uses stereo information.
This method makes use of Velodyne laser scans.
code 73.80 % 84.61 % 65.59 % 0.6 s GPU @ 2.5 Ghz (C/C++)
Y. You, Y. Wang, W. Chao, D. Garg, G. Pleiss, B. Hariharan, M. Campbell and K. Weinberger: Pseudo-LiDAR++: Accurate Depth for 3D Object Detection in Autonomous Driving. International Conference on Learning Representations 2020.
209 SNVC
This method uses stereo information.
code 73.61 % 86.88 % 64.49 % 1 s GPU @ 1.0 Ghz (Python)
S. Li, Z. Liu, Z. Shen and K. Cheng: Stereo Neural Vernier Caliper. Proceedings of the AAAI Conference on Artificial Intelligence 2022.
210 A3DODWTDA
This method makes use of Velodyne laser scans.
code 73.26 % 79.58 % 62.77 % 0.08 s GPU @ 3.0 Ghz (Python)
F. Gustafsson and E. Linder-Norén: Automotive 3D Object Detection Without Target Domain Annotations. 2018.
211 Complexer-YOLO
This method makes use of Velodyne laser scans.
68.96 % 77.24 % 64.95 % 0.06 s GPU @ 3.5 Ghz (C/C++)
M. Simon, K. Amende, A. Kraus, J. Honer, T. Samann, H. Kaulbersch, S. Milz and H. Michael Gross: Complexer-YOLO: Real-Time 3D Object Detection and Tracking on Semantic Point Clouds. The IEEE Conference on Computer Vision and Pattern Recognition (CVPR) Workshops 2019.
212 TopNet-Retina
This method makes use of Velodyne laser scans.
68.16 % 80.16 % 63.43 % 52ms GeForce 1080Ti (tensorflow-gpu, v1.12)
S. Wirges, T. Fischer, C. Stiller and J. Frias: Object Detection and Classification in Occupancy Grid Maps Using Deep Convolutional Networks. 2018 21st International Conference on Intelligent Transportation Systems (ITSC) 2018.
213 SeSame-point w/score code 67.18 % 83.44 % 57.68 % N/A s 1 core @ 1.5 Ghz (Python)
H. O, C. Yang and K. Huh: SeSame: Simple, Easy 3D Object Detection with Point-Wise Semantics. Proceedings of the Asian Conference on Computer Vision (ACCV) 2024.
214 MSVN
This method uses stereo information.
67.17 % 84.63 % 59.88 % 0.15 s 1 core @ 2.5 Ghz (Python)
215 CG-Stereo
This method uses stereo information.
66.44 % 85.29 % 58.95 % 0.57 s GeForce RTX 2080 Ti
C. Li, J. Ku and S. Waslander: Confidence Guided Stereo 3D Object Detection with Split Depth Estimation. IROS 2020.
216 PLUME
This method uses stereo information.
66.27 % 82.97 % 56.70 % 0.15 s GPU @ 2.5 Ghz (Python)
Y. Wang, B. Yang, R. Hu, M. Liang and R. Urtasun: PLUME: Efficient 3D Object Detection from Stereo Images. IROS 2021.
217 CDN
This method uses stereo information.
code 66.24 % 83.32 % 57.65 % 0.6 s GPU @ 2.5 Ghz (Python)
D. Garg, Y. Wang, B. Hariharan, M. Campbell, K. Weinberger and W. Chao: Wasserstein Distances for Stereo Disparity Estimation. Advances in Neural Information Processing Systems (NeurIPS) 2020.
218 DSGN
This method uses stereo information.
code 65.05 % 82.90 % 56.60 % 0.67 s NVIDIA Tesla V100
Y. Chen, S. Liu, X. Shen and J. Jia: DSGN: Deep Stereo Geometry Network for 3D Object Detection. CVPR 2020.
219 CPD(unsupervised) code 64.77 % 81.68 % 61.60 % 0.1 s GPU @ >3.5 Ghz (Python + C/C++)
H. Wu, S. Zhao, X. Huang, C. Wen, X. Li and C. Wang: Commonsense Prototype for Outdoor Unsupervised 3D Object Detection. CVPR 2024.
220 TopNet-DecayRate
This method makes use of Velodyne laser scans.
64.60 % 79.74 % 58.04 % 92 ms NVIDIA GeForce 1080 Ti (tensorflow-gpu)
S. Wirges, T. Fischer, C. Stiller and J. Frias: Object Detection and Classification in Occupancy Grid Maps Using Deep Convolutional Networks. 2018 21st International Conference on Intelligent Transportation Systems (ITSC) 2018.
221 SeSame-voxel w/score code 63.36 % 71.98 % 57.52 % N/A s GPU @ 1.5 Ghz (Python)
H. O, C. Yang and K. Huh: SeSame: Simple, Easy 3D Object Detection with Point-Wise Semantics. Proceedings of the Asian Conference on Computer Vision (ACCV) 2024.
222 BirdNet+ (legacy)
This method makes use of Velodyne laser scans.
code 63.33 % 84.80 % 61.23 % 0.1 s Titan Xp (PyTorch)
A. Barrera, C. Guindel, J. Beltrán and F. García: BirdNet+: End-to-End 3D Object Detection in LiDAR Bird’s Eye View. 2020 IEEE 23rd International Conference on Intelligent Transportation Systems (ITSC) 2020.
223 3D FCN
This method makes use of Velodyne laser scans.
61.67 % 70.62 % 55.61 % >5 s 1 core @ 2.5 Ghz (C/C++)
B. Li: 3D Fully Convolutional Network for Vehicle Detection in Point Cloud. IROS 2017.
224 CDN-PL++
This method uses stereo information.
61.04 % 81.27 % 52.84 % 0.4 s GPU @ 2.5 Ghz (C/C++)
D. Garg, Y. Wang, B. Hariharan, M. Campbell, K. Weinberger and W. Chao: Wasserstein Distances for Stereo Disparity Estimation. Advances in Neural Information Processing Systems 2020.
225 BirdNet
This method makes use of Velodyne laser scans.
59.83 % 84.17 % 57.35 % 0.11 s Titan Xp (Caffe)
J. Beltrán, C. Guindel, F. Moreno, D. Cruzado, F. García and A. Escalera: BirdNet: A 3D Object Detection Framework from LiDAR Information. 2018 21st International Conference on Intelligent Transportation Systems (ITSC) 2018.
226 TopNet-UncEst
This method makes use of Velodyne laser scans.
59.67 % 72.05 % 51.67 % 0.09 s NVIDIA GeForce 1080 Ti (tensorflow-gpu)
S. Wirges, M. Braun, M. Lauer and C. Stiller: Capturing Object Detection Uncertainty in Multi-Layer Grid Maps. 2019.
227 RT3D-GMP
This method uses stereo information.
59.00 % 69.14 % 45.49 % 0.06 s GPU @ 2.5 Ghz (Python + C/C++)
H. Königshof and C. Stiller: Learning-Based Shape Estimation with Grid Map Patches for Realtime 3D Object Detection for Automated Driving. 2020 IEEE 23rd International Conference on Intelligent Transportation Systems (ITSC) 2020.
228 Disp R-CNN (velo)
This method uses stereo information.
code 58.62 % 79.76 % 47.73 % 0.387 s GPU @ 2.5 Ghz (Python + C/C++)
J. Sun, L. Chen, Y. Xie, S. Zhang, Q. Jiang, X. Zhou and H. Bao: Disp R-CNN: Stereo 3D Object Detection via Shape Prior Guided Instance Disparity Estimation. CVPR 2020.
229 ESGN
This method uses stereo information.
58.12 % 78.10 % 49.28 % 0.06 s GPU @ 2.5 Ghz (Python + C/C++)
A. Gao, Y. Pang, J. Nie, Z. Shao, J. Cao, Y. Guo and X. Li: ESGN: Efficient Stereo Geometry Network for Fast 3D Object Detection. IEEE Transactions on Circuits and Systems for Video Technology 2022.
230 Pseudo-LiDAR++
This method uses stereo information.
code 58.01 % 78.31 % 51.25 % 0.4 s GPU @ 2.5 Ghz (Python)
Y. You, Y. Wang, W. Chao, D. Garg, G. Pleiss, B. Hariharan, M. Campbell and K. Weinberger: Pseudo-LiDAR++: Accurate Depth for 3D Object Detection in Autonomous Driving. International Conference on Learning Representations 2020.
231 Disp R-CNN
This method uses stereo information.
code 57.98 % 79.61 % 47.09 % 0.387 s GPU @ 2.5 Ghz (Python + C/C++)
J. Sun, L. Chen, Y. Xie, S. Zhang, Q. Jiang, X. Zhou and H. Bao: Disp R-CNN: Stereo 3D Object Detection via Shape Prior Guided Instance Disparity Estimation. CVPR 2020.
232 SG3D 57.65 % 81.73 % 51.21 % 0.07 s 1 core @ 2.5 Ghz (C/C++)
233 EfficientStereo-3D 55.17 % 78.00 % 46.51 % 0.06 s 1 core @ 2.5 Ghz (Python)
234 ZoomNet
This method uses stereo information.
code 54.91 % 72.94 % 44.14 % 0.3 s 1 core @ 2.5 Ghz (C/C++)
L. Z. Xu: ZoomNet: Part-Aware Adaptive Zooming Neural Network for 3D Object Detection. Proceedings of the AAAI Conference on Artificial Intelligence 2020.
235 EpiStereo 54.71 % 74.04 % 46.58 % 1 s 1 core @ 2.5 Ghz (C/C++)
236 StereoDETR
This method uses stereo information.
code 54.53 % 72.77 % 46.41 % 0.02 s GPU @ 2.5 Ghz (Python)
S. Mu, Z. Gu, Z. Ai, A. Liu, Y. Gao and S. Xu: StereoDETR: Stereo-Based Transformer for 3D Object Detection. IEEE Transactions on Circuits and Systems for Video Technology 2026.
237 VoxelJones code 53.96 % 66.21 % 47.66 % .18 s 1 core @ 2.5 Ghz (Python + C/C++)
M. Motro and J. Ghosh: Vehicular Multi-object Tracking with Persistent Detector Failures. arXiv preprint arXiv:1907.11306 2019.
238 DDStereo code 53.59 % 73.59 % 45.01 % 0.024 s GPU @ 2.5 Ghz (Python)
S. Mu, Z. Gu, Z. Ai, Y. Gao and S. Xu: DDStereo: Efficient Dual Decoder Transformers for Stereo 3D Road Anomaly Detection. European Conference on Computer Vision 2026.
239 TopNet-HighRes
This method makes use of Velodyne laser scans.
53.05 % 67.84 % 46.99 % 101ms NVIDIA GeForce 1080 Ti (tensorflow-gpu)
S. Wirges, T. Fischer, C. Stiller and J. Frias: Object Detection and Classification in Occupancy Grid Maps Using Deep Convolutional Networks. 2018 21st International Conference on Intelligent Transportation Systems (ITSC) 2018.
240 OC Stereo
This method uses stereo information.
code 51.47 % 68.89 % 42.97 % 0.35 s 1 core @ 2.5 Ghz (Python + C/C++)
A. Pon, J. Ku, C. Li and S. Waslander: Object-Centric Stereo Matching for 3D Object Detection. ICRA 2020.
241 YOLOStereo3D
This method uses stereo information.
code 50.28 % 76.10 % 36.86 % 0.1 s GPU 1080Ti
Y. Liu, L. Wang and M. Liu: YOLOStereo3D: A Step Back to 2D for Efficient Stereo 3D Detection. 2021 International Conference on Robotics and Automation (ICRA) 2021.
242 RT3DStereo
This method uses stereo information.
46.82 % 58.81 % 38.38 % 0.08 s GPU @ 2.5 Ghz (C/C++)
H. Königshof, N. Salscheider and C. Stiller: Realtime 3D Object Detection for Automated Driving Using Stereo Vision and Semantic Information. Proc. IEEE Intl. Conf. Intelligent Transportation Systems 2019.
243 Pseudo-Lidar
This method uses stereo information.
code 45.00 % 67.30 % 38.40 % 0.4 s GPU @ 2.5 Ghz (Python + C/C++)
Y. Wang, W. Chao, D. Garg, B. Hariharan, M. Campbell and K. Weinberger: Pseudo-LiDAR From Visual Depth Estimation: Bridging the Gap in 3D Object Detection for Autonomous Driving. The IEEE Conference on Computer Vision and Pattern Recognition (CVPR) 2019.
244 RT3D
This method makes use of Velodyne laser scans.
44.00 % 56.44 % 42.34 % 0.09 s GPU @ 1.8Ghz
Y. Zeng, Y. Hu, S. Liu, J. Ye, Y. Han, X. Li and N. Sun: RT3D: Real-Time 3-D Vehicle Detection in LiDAR Point Cloud for Autonomous Driving. IEEE Robotics and Automation Letters 2018.
245 Stereo CenterNet
This method uses stereo information.
42.12 % 62.97 % 35.37 % 0.04 s GPU @ 2.5 Ghz (Python)
Y. Shi, Y. Guo, Z. Mi and X. Li: Stereo CenterNet-based 3D object detection for autonomous driving. Neurocomputing 2022.
246 Stereo R-CNN
This method uses stereo information.
code 41.31 % 61.92 % 33.42 % 0.3 s GPU @ 2.5 Ghz (Python)
P. Li, X. Chen and S. Shen: Stereo R-CNN based 3D Object Detection for Autonomous Driving. CVPR 2019.
247 DA3D+KM3D+v2-99 code 34.88 % 44.27 % 30.29 % 0.120s GPU @ 2.5 Ghz (Python)
Y. Jia, J. Wang, H. Pan and W. Sun: Enhancing Monocular 3-D Object Detection Through Data Augmentation Strategies. IEEE Transactions on Instrumentation and Measurement 2024.
248 CIE + DM3D 33.13 % 46.17 % 28.80 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
Ananimities: Consistency of Implicit and Explicit Features Matters for Monocular 3D Object Detection. arXiv preprint arXiv:2207.07933 2022.
249 StereoFENet
This method uses stereo information.
32.96 % 49.29 % 25.90 % 0.15 s 1 core @ 3.5 Ghz (Python)
W. Bao, B. Xu and Z. Chen: MonoFENet: Monocular 3D Object Detection with Feature Enhancement Networks. IEEE Transactions on Image Processing 2019.
250 MonoPro 30.61 % 42.61 % 27.38 % 0.01 s 1 core @ 2.5 Ghz (Python)
251 MonoDTF code 28.92 % 42.67 % 25.89 % 0.1 s 1 core @ 2.5 Ghz (Python)
Q. Zhang, C. Lin, Z. Shen, L. Nie and Y. Zhao: Revisiting Monocular 3D Object Detection with Depth Thickness Field. IEEE Transactions on Circuits and Systems for Video Technology 2026.
252 Mobile Stereo R-CNN
This method uses stereo information.
28.78 % 44.51 % 22.30 % 1.8 s NVIDIA Jetson TX2
M. Hussein, M. Khalil and B. Abdullah: 3D Object Detection using Mobile Stereo R- CNN on Nvidia Jetson TX2. International Conference on Advanced Engineering, Technology and Applications (ICAETA) 2021.
253 DA3D+KM3D code 28.71 % 39.50 % 25.20 % 0.02 s GPU @ 2.5 Ghz (Python)
Y. Jia, J. Wang, H. Pan and W. Sun: Enhancing Monocular 3-D Object Detection Through Data Augmentation Strategies. IEEE Transactions on Instrumentation and Measurement 2024.
254 MonoCtrl_MonoLSS 28.57 % 37.97 % 25.81 % 0.04 s 1 core @ 2.5 Ghz (Python)
255 CIE 28.50 % 41.41 % 23.88 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
Anonymities: Consistency of Implicit and Explicit Features Matters for Monocular 3D Object Detection. arXiv preprint arXiv:2207.07933 2022.
256 MonoMIP 27.85 % 37.80 % 24.81 % 0.01 s 1 core @ 2.5 Ghz (C/C++)
257 MonoD2OM code 26.92 % 37.63 % 23.82 % 0.04 s GPU @ 2.5 Ghz (Python)
258 DA3D code 26.92 % 36.83 % 23.41 % 0.03 s 1 core @ 2.5 Ghz (Python)
Y. Jia, J. Wang, H. Pan and W. Sun: Enhancing Monocular 3-D Object Detection Through Data Augmentation Strategies. IEEE Transactions on Instrumentation and Measurement 2024.
259 MonoPCS 26.91 % 38.72 % 23.78 % 0.04 s 1 core @ 2.5 Ghz (C/C++)
260 MonoDF code 26.86 % 37.17 % 23.43 % 1 s 1 core @ 2.5 Ghz (C/C++)
261 MonoLiG code 26.83 % 35.73 % 24.24 % 0.03 s 1 core @ 2.5 Ghz (C/C++)
A. Hekimoglu, M. Schmidt and A. Ramiro: Monocular 3D Object Detection with LiDAR Guided Semi Supervised Active Learning. 2023.
262 RARE 26.73 % 38.46 % 23.46 % 0.03 s 1 core @ 2.5 Ghz (Python)
263 MonoIA code 26.59 % 37.55 % 23.26 % 0.01 s 1 core @ 2.5 Ghz (C/C++)
264 LeAD-M3D code 26.58 % 38.36 % 23.74 % 0.0079 s 1 core @ 2.5 Ghz (Python)
J. Meier, J. Michel, O. Dhaouadi, Y. Yang, C. Reich, Z. Bauer, S. Roth, M. Pollefeys, J. Kaiser and D. Cremers: LeAD-M3D: Leveraging Asymmetric Distillation for Real-Time Monocular 3D Detection. European Conference on Computer Vision (ECCV) 2026.
265 MonoCD-E code 26.57 % 36.58 % 23.36 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
266 MonoCtrl_MonoLSS(re) 26.29 % 37.58 % 23.93 % 0.04 s 1 core @ 2.5 Ghz (Python)
267 MonoCtrl_MonoDistill 26.14 % 36.93 % 21.77 % 0.06 s 1 core @ 2.5 Ghz (Python)
268 MonOri code 26.00 % 37.86 % 23.10 % 0.03 s 4 cores @ 2.5 Ghz (Python)
H. Yao, P. Han, J. Chen, Z. Wang, Y. Qiu, X. Wang, Y. wang, X. Chai, C. Cao and W. Jin: MonOri: Orientation-Guided PnP for Monocular 3-D Object Detection. IEEE Transactions on Neural Networks and Learning Systems 2025.
269 CoDMono 25.97 % 37.29 % 23.20 % 0.02 s 1 core @ 2.5 Ghz (C/C++)
270 MonoLSS 25.95 % 34.89 % 22.59 % 0.04 s 1 core @ 2.5 Ghz (Python)
Z. Li, J. Jia and Y. Shi: MonoLSS: Learnable Sample Selection For Monocular 3D Detection. International Conference on 3D Vision 2024.
271 MonoHID 25.92 % 35.88 % 22.64 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
272 CMKD code 25.82 % 38.98 % 22.80 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
Y. Hong, H. Dai and Y. Ding: Cross-Modality Knowledge Distillation Network for Monocular 3D Object Detection. ECCV 2022.
273 MonoCoP code 25.75 % 36.77 % 22.62 % 0.01 s 1 core @ 2.5 Ghz (C/C++)
Z. Zhang, A. Kumar, G. Ganesan and X. Liu: Unleashing the Power of Chain-of- Prediction for Monocular 3D Object Detection. Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition 2026.
274 MonoCtrl_MonoDistill 25.58 % 30.36 % 23.60 % 0.06 s 1 core @ 2.5 Ghz (Python)
275 MonoCtrl_MonoDistill 25.45 % 35.99 % 22.65 % 0.06 s 1 core @ 2.5 Ghz (Python)
276 IDEAL-M3D 25.44 % 35.33 % 22.25 % 0.04 s 1 core @ 2.5 Ghz (Python)
J. Meier, F. Günther, R. Marin, O. Dhaouadi, J. Kaiser and D. Cremers: IDEAL-M3D: Instance Diversity- Enriched Active Learning for Monocular 3D Detection. Proceedings of the IEEE/CVF Winter Conference on Applications of Computer Vision (WACV) 2026.
277 AMNet+DDAD15M code 25.40 % 34.68 % 22.85 % 0.03 s 1 core @ 2.5 Ghz (C/C++)
H. Pan, Y. Jia, J. Wang and W. Sun: MonoAMNet: Three-Stage Real-Time Monocular 3D Object Detection With Adaptive Methods. IEEE Transactions on Intelligent Transportation Systems 2025.
278 MonoHPE 25.27 % 36.51 % 22.77 % 0.04 s 1 core @ 2.5 Ghz (Python)
279 BEVHeight++ code 24.90 % 37.51 % 20.93 % 0.04 s 1 core @ 2.5 Ghz (C/C++)
L. Yang, T. Tang, J. Li, P. Chen, K. Yuan, L. Wang, Y. Huang, X. Zhang and K. Yu: Bevheight++: Toward robust visual centric 3d object detection. arXiv preprint arXiv:2309.16179 2023.
280 MonoCtrl_MonoCD 24.85 % 33.96 % 21.66 % 0.06 s 1 core @ 2.5 Ghz (Python)
281 AMNet code 24.84 % 34.71 % 22.14 % 0.03 s GPU @ 1.0 Ghz (Python)
H. Pan, Y. Jia, J. Wang and W. Sun: MonoAMNet: Three-Stage Real-Time Monocular 3D Object Detection With Adaptive Methods. IEEE Transactions on Intelligent Transportation Systems 2025.
282 PS-SVDM 24.82 % 38.18 % 20.89 % 1 s 1 core @ 2.5 Ghz (Python)
Y. Shi: SVDM: Single-View Diffusion Model for Pseudo-Stereo 3D Object Detection. arXiv preprint arXiv:2307.02270 2023.
283 LPCG-Monoflex code 24.81 % 35.96 % 21.86 % 0.03 s 1 core @ 2.5 Ghz (C/C++)
L. Peng, F. Liu, Z. Yu, S. Yan, D. Deng, Z. Yang, H. Liu and D. Cai: Lidar Point Cloud Guided Monocular 3D Object Detection. ECCV 2022.
284 MonoDGC code 24.71 % 35.18 % 22.38 % 0.03 s 1 core @ 2.5 Ghz (C/C++)
C. Guo, L. Guo, W. Lin, Y. Ma, K. Ren and Q. Chen: MonoDGC: Image-Plane Dynamic Graph Cross-Former for Monocular 3D Object Detection. 2026.
285 MonoLSS(retrained) 24.68 % 33.57 % 21.55 % 0.02 s 1 core @ 2.5 Ghz (Python)
286 Monodgc-3classes code 24.57 % 35.75 % 21.26 % 0.03 s 1 core @ 2.5 Ghz (C/C++)
C. Guo, L. Guo, W. Lin, Y. Ma, K. Ren and Q. Chen: MonoDGC: Image-Plane Dynamic Graph Cross-Former for Monocular 3D Object Detection. 2026.
287 NeurOCS 24.49 % 37.27 % 20.89 % 0.1 s GPU @ 2.5 Ghz (Python)
Z. Min, B. Zhuang, S. Schulter, B. Liu, E. Dunn and M. Chandraker: NeurOCS: Neural NOCS Supervision for Monocular 3D Object Localization. CVPR 2023.
288 MF 24.47 % 35.16 % 21.25 % 0.02 s 1 core @ 2.5 Ghz (C/C++)
289 Mix-Teaching code 24.23 % 35.74 % 20.80 % 30 s 1 core @ 2.5 Ghz (C/C++)
L. Yang, X. Zhang, L. Wang, M. Zhu, C. Zhang and J. Li: Mix-Teaching: A Simple, Unified and Effective Semi-Supervised Learning Framework for Monocular 3D Object Detection. ArXiv 2022.
290 MonoSKD code 24.08 % 37.12 % 20.37 % 0.04 s 1 core @ 2.5 Ghz (Python)
S. Wang and J. Zheng: MonoSKD: General Distillation Framework for Monocular 3D Object Detection via Spearman Correlation Coefficient. ECAI 2023.
291 MonoSample (DID-M3D) code 23.94 % 37.64 % 20.46 % 0.2 s 1 core @ 2.5 Ghz (C/C++)
J. Qiao, B. Liu, J. Yang, B. Wang, S. Xiu, X. Du and X. Nie: MonoSample: Synthetic 3D Data Augmentation Method in Monocular 3D Object Detection. IEEE Robotics and Automation Letters 2024.
292 MonoGMM 23.80 % 33.64 % 21.47 % 35ms 1 core @ 2.5 Ghz (C/C++)
293 PS-fld code 23.76 % 32.64 % 20.64 % 0.25 s 1 core @ 2.5 Ghz (C/C++)
Y. Chen, H. Dai and Y. Ding: Pseudo-Stereo for Monocular 3D Object Detection in Autonomous Driving. Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR) 2022.
294 ADD code 23.58 % 35.20 % 20.08 % 0.1 s 1 core @ 2.5 Ghz (Python)
Z. Wu, Y. Wu, J. Pu, X. Li and X. Wang: Attention-based Depth Distillation with 3D-Aware Positional Encoding for Monocular 3D Object Detection. AAAI2023 .
295 MonoNeRD code 23.46 % 31.13 % 20.97 % na s 1 core @ 2.5 Ghz (Python)
J. Xu, L. Peng, H. Cheng, H. Li, W. Qian, K. Li, W. Wang and D. Cai: MonoNeRD: NeRF-like Representations for Monocular 3D Object Detection. ICCV 2023.
296 MonoDDE 23.46 % 33.58 % 20.37 % 0.04 s 1 core @ 2.5 Ghz (Python)
Z. Li, Z. Qu, Y. Zhou, J. Liu, H. Wang and L. Jiang: Diversity Matters: Fully Exploiting Depth Clues for Reliable Monocular 3D Object Detection. CVPR 2022.
297 DD3D code 23.41 % 32.35 % 20.42 % n/a s 1 core @ 2.5 Ghz (C/C++)
D. Park, R. Ambrus, V. Guizilini, J. Li and A. Gaidon: Is Pseudo-Lidar needed for Monocular 3D Object detection?. IEEE/CVF International Conference on Computer Vision (ICCV) .
298 MonoUNI code 23.05 % 33.28 % 19.39 % 0.04 s 1 core @ 2.5 Ghz (Python)
J. Jia, Z. Li and Y. Shi: MonoUNI: A Unified Vehicle and Infrastructure-side Monocular 3D Object Detection Network with Sufficient Depth Clues. Thirty-seventh Conference on Neural Information Processing Systems 2023.
299 MonoCD code 22.81 % 33.41 % 19.57 % n/a s 1 core @ 2.5 Ghz (Python)
L. Yan, P. Yan, S. Xiong, X. Xiang and Y. Tan: MonoCD: Monocular 3D Object Detection with Complementary Depths. CVPR 2024.
300 MonoFRD 22.77 % 29.65 % 20.41 % 0.01 s 1 core @ 2.5 Ghz (C/C++)
Z. Gong, Y. Zhao, F. Zhang, G. Gui, B. Chen, L. Yu, H. Wang, C. Yang and W. Gui: Color intuitive feature guided depth-height fusion and volume rendering for monocular 3D object detection. IEEE Transactions on Intelligent Vehicles(Major Revison) 2024.
301 DID-M3D code 22.76 % 32.95 % 19.83 % 0.04 s 1 core @ 2.5 Ghz (Python)
L. Peng, X. Wu, Z. Yang, H. Liu and D. Cai: DID-M3D: Decoupling Instance Depth for Monocular 3D Object Detection. ECCV 2022.
302 OPA-3D code 22.53 % 33.54 % 19.22 % 0.04 s 1 core @ 3.5 Ghz (Python)
Y. Su, Y. Di, G. Zhai, F. Manhardt, J. Rambach, B. Busam, D. Stricker and F. Tombari: OPA-3D: Occlusion-Aware Pixel-Wise Aggregation for Monocular 3D Object Detection. IEEE Robotics and Automation Letters 2023.
303 DCD code 21.50 % 32.55 % 18.25 % 0.03 s 1 core @ 2.5 Ghz (C/C++)
Y. Li, Y. Chen, J. He and Z. Zhang: Densely Constrained Depth Estimator for Monocular 3D Object Detection. European Conference on Computer Vision 2022.
304 MonoDETR code 21.45 % 32.20 % 18.68 % 0.04 s 1 core @ 2.5 Ghz (Python)
R. Zhang, H. Qiu, T. Wang, X. Xu, Z. Guo, Y. Qiao, P. Gao and H. Li: MonoDETR: Depth-aware Transformer for Monocular 3D Object Detection. arXiv preprint arXiv:2203.13310 2022.
305 SGM3D code 21.37 % 31.49 % 18.43 % 0.03 s 1 core @ 2.5 Ghz (C/C++)
Z. Zhou, L. Du, X. Ye, Z. Zou, X. Tan, L. Zhang, X. Xue and J. Feng: SGM3D: Stereo Guided Monocular 3D Object Detection. RA-L 2022.
306 Cube R-CNN code 21.20 % 31.70 % 18.43 % 0.05 s GPU @ 2.5 Ghz (Python)
G. Brazil, A. Kumar, J. Straub, N. Ravi, J. Johnson and G. Gkioxari: Omni3D: A Large Benchmark and Model for 3D Object Detection in the Wild. CVPR 2023.
307 GUPNet code 21.19 % 30.29 % 18.20 % NA s 1 core @ 2.5 Ghz (Python + C/C++)
Y. Lu, X. Ma, L. Yang, T. Zhang, Y. Liu, Q. Chu, J. Yan and W. Ouyang: Geometry Uncertainty Projection Network for Monocular 3D Object Detection. arXiv preprint arXiv:2107.13774 2021.
308 HomoLoss(monoflex) code 20.68 % 29.60 % 17.81 % 0.04 s 1 core @ 2.5 Ghz (Python)
J. Gu, B. Wu, L. Fan, J. Huang, S. Cao, Z. Xiang and X. Hua: Homography Loss for Monocular 3D Object Detection. Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR) 2022.
309 DEVIANT code 20.44 % 29.65 % 17.43 % 0.04 s 1 GPU (Python)
A. Kumar, G. Brazil, E. Corona, A. Parchami and X. Liu: DEVIANT: Depth EquiVarIAnt NeTwork for Monocular 3D Object Detection. European Conference on Computer Vision (ECCV) 2022.
310 MonoDTR 20.38 % 28.59 % 17.14 % 0.04 s 1 core @ 2.5 Ghz (C/C++)
K. Huang, T. Wu, H. Su and W. Hsu: MonoDTR: Monocular 3D Object Detection with Depth-Aware Transformer. CVPR 2022.
311 MDSNet 20.14 % 32.81 % 15.77 % 0.05 s 1 core @ 2.5 Ghz (Python)
Z. Xie, Y. Song, J. Wu, Z. Li, C. Song and Z. Xu: MDS-Net: Multi-Scale Depth Stratification 3D Object Detection from Monocular Images. Sensors 2022.
312 AutoShape code 20.08 % 30.66 % 15.95 % 0.04 s 1 core @ 2.5 Ghz (C/C++)
Z. Liu, D. Zhou, F. Lu, J. Fang and L. Zhang: AutoShape: Real-Time Shape-Aware Monocular 3D Object Detection. Proceedings of the IEEE/CVF International Conference on Computer Vision 2021.
313 MonoCD+DGWA 20.06 % 27.81 % 14.60 % 0.05 s 1 core @ 2.5 Ghz (Python)
314 MonoFlex 19.75 % 28.23 % 16.89 % 0.03 s GPU @ 2.5 Ghz (Python)
Y. Zhang, J. Lu and J. Zhou: Objects are Different: Flexible Monocular 3D Object Detection. CVPR 2021.
315 MonoEF 19.70 % 29.03 % 17.26 % 0.03 s 1 core @ 2.5 Ghz (Python)
Y. Zhou, Y. He, H. Zhu, C. Wang, H. Li and Q. Jiang: Monocular 3D Object Detection: An Extrinsic Parameter Free Approach. Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR) 2021.
316 MonOAPC 19.67 % 28.91 % 16.99 % 0035 s 1 core @ 2.5 Ghz (Python)
H. Yao, J. Chen, Z. Wang, X. Wang, P. Han, X. Chai and Y. Qiu: Occlusion-Aware Plane-Constraints for Monocular 3D Object Detection. IEEE Transactions on Intelligent Transportation Systems 2023.
317 MonoDSSMs-M 19.59 % 28.29 % 16.34 % 0.02 s 1 core @ 2.5 Ghz (Python + C/C++)
K. Vu, T. Tran and D. Nguyen: MonoDSSMs: Efficient Monocular 3D Object Detection with Depth-Aware State Space Models. Proceedings of the Asian Conference on Computer Vision (ACCV) 2024.
318 MonoDSSMs-A 19.54 % 28.84 % 16.30 % 0.02 s 1 core @ 2.5 Ghz (C/C++)
K. Vu, T. Tran and D. Nguyen: MonoDSSMs: Efficient Monocular 3D Object Detection with Depth-Aware State Space Models. Proceedings of the Asian Conference on Computer Vision (ACCV) 2024.
319 HomoLoss(imvoxelnet) code 19.25 % 29.18 % 16.21 % 0.20 s 1 core @ 2.5 Ghz (Python)
J. Gu, B. Wu, L. Fan, J. Huang, S. Cao, Z. Xiang and X. Hua: Homogrpahy Loss for Monocular 3D Object Detection. Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR) 2022.
320 DFR-Net 19.17 % 28.17 % 14.84 % 0.18 s 1080 Ti (Pytorch)
Z. Zou, X. Ye, L. Du, X. Cheng, X. Tan, L. Zhang, J. Feng, X. Xue and E. Ding: The devil is in the task: Exploiting reciprocal appearance-localization features for monocular 3d object detection . ICCV 2021.
321 PS-SVDM 19.07 % 28.52 % 16.30 % 1 s 1 core @ 2.5 Ghz (Python)
Y. Shi: SVDM: Single-View Diffusion Model for Pseudo-Stereo 3D Object Detection. arXiv preprint arXiv:2307.02270 2023.
322 DLE code 19.05 % 31.09 % 14.13 % 0.06 s NVIDIA Tesla V100
C. Liu, S. Gu, L. Gool and R. Timofte: Deep Line Encoding for Monocular 3D Object Detection and Depth Prediction. Proceedings of the British Machine Vision Conference (BMVC) 2021.
323 PCT code 19.03 % 29.65 % 15.92 % 0.045 s 1 core @ 2.5 Ghz (C/C++)
L. Wang, L. Zhang, Y. Zhu, Z. Zhang, T. He, M. Li and X. Xue: Progressive Coordinate Transforms for Monocular 3D Object Detection. NeurIPS 2021.
324 CaDDN code 18.91 % 27.94 % 17.19 % 0.63 s GPU @ 2.5 Ghz (Python)
C. Reading, A. Harakeh, J. Chae and S. Waslander: Categorical Depth Distribution Network for Monocular 3D Object Detection. CVPR 2021.
325 monodle code 18.89 % 24.79 % 16.00 % 0.04 s GPU @ 2.5 Ghz (Python)
X. Ma, Y. Zhang, D. Xu, D. Zhou, S. Yi, H. Li and W. Ouyang: Delving into Localization Errors for Monocular 3D Object Detection. CVPR 2021 .
326 Neighbor-Vote 18.65 % 27.39 % 16.54 % 0.1 s GPU @ 2.5 Ghz (Python)
X. Chu, J. Deng, Y. Li, Z. Yuan, Y. Zhang, J. Ji and Y. Zhang: Neighbor-Vote: Improving Monocular 3D Object Detection through Neighbor Distance Voting. ACM MM 2021.
327 MonoRCNN++ code 18.62 % 27.20 % 15.69 % 0.07 s GPU @ 2.5 Ghz (Python)
X. Shi, Z. Chen and T. Kim: Multivariate Probabilistic Monocular 3D Object Detection. WACV 2023.
328 FA-MonoCD 18.41 % 25.90 % 14.36 % 0.15 s GPU @ 2.5 Ghz (Python)
329 GrooMeD-NMS code 18.27 % 26.19 % 14.05 % 0.12 s 1 core @ 2.5 Ghz (Python)
A. Kumar, G. Brazil and X. Liu: GrooMeD-NMS: Grouped Mathematically Differentiable NMS for Monocular 3D Object Detection. CVPR 2021.
330 MonoRCNN code 18.11 % 25.48 % 14.10 % 0.07 s GPU @ 2.5 Ghz (Python)
X. Shi, Q. Ye, X. Chen, C. Chen, Z. Chen and T. Kim: Geometry-based Distance Decomposition for Monocular 3D Object Detection. ICCV 2021.
331 Ground-Aware code 17.98 % 29.81 % 13.08 % 0.05 s 1 core @ 2.5 Ghz (C/C++)
Y. Liu, Y. Yuan and M. Liu: Ground-aware Monocular 3D Object Detection for Autonomous Driving. IEEE Robotics and Automation Letters 2021.
332 Aug3D-RPN 17.89 % 26.00 % 14.18 % 0.08 s 1 core @ 2.5 Ghz (C/C++)
C. He, J. Huang, X. Hua and L. Zhang: Aug3D-RPN: Improving Monocular 3D Object Detection by Synthetic Images with Virtual Depth. 2021.
333 DDMP-3D 17.89 % 28.08 % 13.44 % 0.18 s 1 core @ 2.5 Ghz (Python)
L. Wang, L. Du, X. Ye, Y. Fu, G. Guo, X. Xue, J. Feng and L. Zhang: Depth-conditioned Dynamic Message Propagation for Monocular 3D Object Detection. CVPR 2020.
334 IAFA 17.88 % 25.88 % 15.35 % 0.04 s 1 core @ 2.5 Ghz (C/C++)
D. Zhou, X. Song, Y. Dai, J. Yin, F. Lu, M. Liao, J. Fang and L. Zhang: IAFA: Instance-Aware Feature Aggregation for 3D Object Detection from a Single Image. Proceedings of the Asian Conference on Computer Vision 2020.
335 FMF-occlusion-net 17.60 % 27.39 % 13.25 % 0.16 s 1 core @ 2.5 Ghz (Python + C/C++)
H. Liu, H. Liu, Y. Wang, F. Sun and W. Huang: Fine-grained Multi-level Fusion for Anti- occlusion Monocular 3D Object Detection. IEEE Transactions on Image Processing 2022.
336 RefinedMPL 17.60 % 28.08 % 13.95 % 0.15 s GPU @ 2.5 Ghz (Python + C/C++)
J. Vianney, S. Aich and B. Liu: RefinedMPL: Refined Monocular PseudoLiDAR for 3D Object Detection in Autonomous Driving. arXiv preprint arXiv:1911.09712 2019.
337 Kinematic3D code 17.52 % 26.69 % 13.10 % 0.12 s 1 core @ 1.5 Ghz (C/C++)
G. Brazil, G. Pons-Moll, X. Liu and B. Schiele: Kinematic 3D Object Detection in Monocular Video. ECCV 2020 .
338 MonoRUn code 17.34 % 27.94 % 15.24 % 0.07 s GPU @ 2.5 Ghz (Python + C/C++)
H. Chen, Y. Huang, W. Tian, Z. Gao and L. Xiong: MonoRUn: Monocular 3D Object Detection by Reconstruction and Uncertainty Propagation. IEEE Conference on Computer Vision and Pattern Recognition (CVPR) 2021.
339 AM3D 17.32 % 25.03 % 14.91 % 0.4 s GPU @ 2.5 Ghz (Python + C/C++)
X. Ma, Z. Wang, H. Li, P. Zhang, W. Ouyang and X. Fan: Accurate Monocular Object Detection via Color- Embedded 3D Reconstruction for Autonomous Driving. Proceedings of the IEEE international Conference on Computer Vision (ICCV) 2019.
340 YoloMono3D code 17.15 % 26.79 % 12.56 % 0.05 s GPU @ 2.5 Ghz (Python)
Y. Liu, L. Wang and L. Ming: YOLOStereo3D: A Step Back to 2D for Efficient Stereo 3D Detection. 2021 International Conference on Robotics and Automation (ICRA) 2021.
341 CMAN 17.04 % 25.89 % 12.88 % 0.15 s 1 core @ 2.5 Ghz (Python)
C. Yuanzhouhan Cao: CMAN: Leaning Global Structure Correlation for Monocular 3D Object Detection. IEEE Trans. Intell. Transport. Syst. 2022.
342 GAC3D 16.93 % 25.80 % 12.50 % 0.25 s 1 core @ 2.5 Ghz (Python)
M. Bui, D. Ngo, H. Pham and D. Nguyen: GAC3D: improving monocular 3D object detection with ground-guide model and adaptive convolution. 2021.
343 PatchNet code 16.86 % 22.97 % 14.97 % 0.4 s 1 core @ 2.5 Ghz (C/C++)
X. Ma, S. Liu, Z. Xia, H. Zhang, X. Zeng and W. Ouyang: Rethinking Pseudo-LiDAR Representation. Proceedings of the European Conference on Computer Vision (ECCV) 2020.
344 PGD-FCOS3D code 16.51 % 26.89 % 13.49 % 0.03 s 1 core @ 2.5 Ghz (C/C++)
T. Wang, X. Zhu, J. Pang and D. Lin: Probabilistic and Geometric Depth: Detecting Objects in Perspective. Conference on Robot Learning (CoRL) 2021.
345 ImVoxelNet code 16.37 % 25.19 % 13.58 % 0.2 s GPU @ 2.5 Ghz (Python)
D. Rukhovich, A. Vorontsova and A. Konushin: ImVoxelNet: Image to Voxels Projection for Monocular and Multi-View General-Purpose 3D Object Detection. arXiv preprint arXiv:2106.01178 2021.
346 KM3D code 16.20 % 23.44 % 14.47 % 0.03 s 1 core @ 2.5 Ghz (Python)
P. Li: Monocular 3D Detection with Geometric Constraints Embedding and Semi-supervised Training. 2020.
347 D4LCN code 16.02 % 22.51 % 12.55 % 0.2 s GPU @ 2.5 Ghz (Python + C/C++)
M. Ding, Y. Huo, H. Yi, Z. Wang, J. Shi, Z. Lu and P. Luo: Learning Depth-Guided Convolutions for Monocular 3D Object Detection. CVPR 2020.
348 MonoCD code 15.60 % 22.65 % 12.76 % 0.04 s GPU @ 2.5 Ghz (Python)
L. Yan, P. Yan, S. Xiong, X. Xiang and Y. Tan: MonoCD: Monocular 3D Object Detection with Complementary Depths. CVPR 2024.
349 MonoPair 14.83 % 19.28 % 12.89 % 0.06 s GPU @ 2.5 Ghz (Python + C/C++)
Y. Chen, L. Tai, K. Sun and M. Li: MonoPair: Monocular 3D Object Detection Using Pairwise Spatial Relationships. The IEEE Conference on Computer Vision and Pattern Recognition (CVPR) 2020.
350 Decoupled-3D 14.82 % 23.16 % 11.25 % 0.08 s GPU @ 2.5 Ghz (C/C++)
Y. Cai, B. Li, Z. Jiao, H. Li, X. Zeng and X. Wang: Monocular 3D Object Detection with Decoupled Structured Polygon Estimation and Height-Guided Depth Estimation. AAAI 2020.
351 QD-3DT
This is an online method (no batch processing).
code 14.71 % 20.16 % 12.76 % 0.03 s GPU @ 2.5 Ghz (Python)
H. Hu, Y. Yang, T. Fischer, F. Yu, T. Darrell and M. Sun: Monocular Quasi-Dense 3D Object Tracking. ArXiv:2103.07351 2021.
352 SMOKE code 14.49 % 20.83 % 12.75 % 0.03 s GPU @ 2.5 Ghz (Python)
Z. Liu, Z. Wu and R. Tóth: SMOKE: Single-Stage Monocular 3D Object Detection via Keypoint Estimation. 2020.
353 RTM3D code 14.20 % 19.17 % 11.99 % 0.05 s GPU @ 1.0 Ghz (Python)
P. Li, H. Zhao, P. Liu and F. Cao: RTM3D: Real-time Monocular 3D Detection from Object Keypoints for Autonomous Driving. 2020.
354 Mono3D_PLiDAR code 13.92 % 21.27 % 11.25 % 0.1 s NVIDIA GeForce 1080 (pytorch)
X. Weng and K. Kitani: Monocular 3D Object Detection with Pseudo-LiDAR Point Cloud. arXiv:1903.09847 2019.
355 M3D-RPN code 13.67 % 21.02 % 10.23 % 0.16 s GPU @ 1.5 Ghz (Python)
G. Brazil and X. Liu: M3D-RPN: Monocular 3D Region Proposal Network for Object Detection . ICCV 2019 .
356 CSoR
This method makes use of Velodyne laser scans.
13.07 % 18.67 % 10.34 % 3.5 s 4 cores @ >3.5 Ghz (Python + C/C++)
L. Plotkin: PyDriver: Entwicklung eines Frameworks für räumliche Detektion und Klassifikation von Objekten in Fahrzeugumgebung. 2015.
357 MonoPSR code 12.58 % 18.33 % 9.91 % 0.2 s GPU @ 3.5 Ghz (Python)
J. Ku*, A. Pon* and S. Waslander: Monocular 3D Object Detection Leveraging Accurate Proposals and Shape Reconstruction. CVPR 2019.
358 Plane-Constraints code 12.06 % 17.31 % 10.05 % 0.05 s 4 cores @ 3.0 Ghz (Python)
H. Yao, J. Chen, Z. Wang, X. Wang, X. Chai, Y. Qiu and P. Han: Vertex points are not enough: Monocular 3D object detection via intra-and inter-plane constraints. Neural Networks 2023.
359 MonoCInIS 11.64 % 22.28 % 9.95 % 0,13 s GPU @ 2.5 Ghz (C/C++)
J. Heylen, M. De Wolf, B. Dawagne, M. Proesmans, L. Van Gool, W. Abbeloos, H. Abdelkawy and D. Reino: MonoCInIS: Camera Independent Monocular 3D Object Detection using Instance Segmentation. Proceedings of the IEEE/CVF International Conference on Computer Vision 2021.
360 SS3D 11.52 % 16.33 % 9.93 % 48 ms Tesla V100 (Python)
E. Jörgensen, C. Zach and F. Kahl: Monocular 3D Object Detection and Box Fitting Trained End-to-End Using Intersection-over-Union Loss. CoRR 2019.
361 MonoGRNet code 11.17 % 18.19 % 8.73 % 0.04s NVIDIA P40
Z. Qin, J. Wang and Y. Lu: MonoGRNet: A Geometric Reasoning Network for 3D Object Localization. The Thirty-Third AAAI Conference on Artificial Intelligence (AAAI-19) 2019.
362 MonoFENet 11.03 % 17.03 % 9.05 % 0.15 s 1 core @ 3.5 Ghz (Python)
W. Bao, B. Xu and Z. Chen: MonoFENet: Monocular 3D Object Detection with Feature Enhancement Networks. IEEE Transactions on Image Processing 2019.
363 MonoCInIS 10.96 % 20.42 % 9.23 % 0,14 s GPU @ 2.5 Ghz (Python)
J. Heylen, M. De Wolf, B. Dawagne, M. Proesmans, L. Van Gool, W. Abbeloos, H. Abdelkawy and D. Reino: MonoCInIS: Camera Independent Monocular 3D Object Detection using Instance Segmentation. Proceedings of the IEEE/CVF International Conference on Computer Vision 2021.
364 A3DODWTDA (image) code 8.66 % 10.37 % 7.06 % 0.8 s GPU @ 3.0 Ghz (Python)
F. Gustafsson and E. Linder-Norén: Automotive 3D Object Detection Without Target Domain Annotations. 2018.
365 TLNet (Stereo)
This method uses stereo information.
code 7.69 % 13.71 % 6.73 % 0.1 s 1 core @ 2.5 Ghz (Python)
Z. Qin, J. Wang and Y. Lu: Triangulation Learning Network: from Monocular to Stereo 3D Object Detection. IEEE Conference on Computer Vision and Pattern Recognition (CVPR) 2019.
366 Shift R-CNN (mono) code 6.82 % 11.84 % 5.27 % 0.25 s GPU @ 1.5 Ghz (Python)
A. Naiden, V. Paunescu, G. Kim, B. Jeon and M. Leordeanu: Shift R-CNN: Deep Monocular 3D Object Detection With Closed-form Geometric Constraints. ICIP 2019.
367 SparVox3D 6.39 % 10.20 % 5.06 % 0.05 s GPU @ 2.0 Ghz (Python)
E. Balatkan and F. Kıraç: Improving Regression Performance on Monocular 3D Object Detection Using Bin-Mixing and Sparse Voxel Data. 2021 6th International Conference on Computer Science and Engineering (UBMK) 2021.
368 GS3D 6.08 % 8.41 % 4.94 % 2 s 1 core @ 2.5 Ghz (C/C++)
B. Li, W. Ouyang, L. Sheng, X. Zeng and X. Wang: GS3D: An Efficient 3D Object Detection Framework for Autonomous Driving. IEEE Conference on Computer Vision and Pattern Recognition (CVPR) 2019.
369 MVRA + I-FRCNN+ 5.84 % 9.05 % 4.50 % 0.18 s GPU @ 2.5 Ghz (Python)
H. Choi, H. Kang and Y. Hyun: Multi-View Reprojection Architecture for Orientation Estimation. The IEEE International Conference on Computer Vision (ICCV) Workshops 2019.
370 WeakM3D code 5.66 % 11.82 % 4.08 % 0.08 s 1 core @ 2.5 Ghz (C/C++)
L. Peng, S. Yan, B. Wu, Z. Yang, X. He and D. Cai: WeakM3D: Towards Weakly Supervised Monocular 3D Object Detection. ICLR 2022.
371 ROI-10D 4.91 % 9.78 % 3.74 % 0.2 s GPU @ 3.5 Ghz (Python)
F. Manhardt, W. Kehl and A. Gaidon: ROI-10D: Monocular Lifting of 2D Detection to 6D Pose and Metric Shape. Computer Vision and Pattern Recognition (CVPR) 2019.
372 3D-GCK 4.57 % 5.79 % 3.64 % 24 ms Tesla V100
N. Gählert, J. Wan, N. Jourdan, J. Finkbeiner, U. Franke and J. Denzler: Single-Shot 3D Detection of Vehicles from Monocular RGB Images via Geometrically Constrained Keypoints in Real-Time. 2020 IEEE Intelligent Vehicles Symposium (IV) 2020.
373 FQNet 3.23 % 5.40 % 2.46 % 0.5 s 1 core @ 2.5 Ghz (Python)
L. Liu, J. Lu, C. Xu, Q. Tian and J. Zhou: Deep Fitting Degree Scoring Network for Monocular 3D Object Detection. Proceedings of the IEEE Conference on Computer Vision and Pattern Recognition 2019.
374 3D-SSMFCNN code 2.63 % 3.20 % 2.40 % 0.1 s GPU @ 1.5 Ghz (C/C++)
L. Novak: Vehicle Detection and Pose Estimation for Autonomous Driving. 2017.
375 VeloFCN
This method makes use of Velodyne laser scans.
0.14 % 0.02 % 0.21 % 1 s GPU @ 2.5 Ghz (Python + C/C++)
B. Li, T. Zhang and T. Xia: Vehicle Detection from 3D Lidar Using Fully Convolutional Network. RSS 2016 .
376 multi-task CNN 0.00 % 0.00 % 0.00 % 25.1 ms GPU @ 2.0 Ghz (Python)
M. Oeljeklaus, F. Hoffmann and T. Bertram: A Fast Multi-Task CNN for Spatial Understanding of Traffic Scenes. IEEE Intelligent Transportation Systems Conference 2018.
377 tmp 0.00 % 0.00 % 0.00 % 0.05 s 1 core @ 2.5 Ghz (C/C++)
378 mBoW
This method makes use of Velodyne laser scans.
0.00 % 0.00 % 0.00 % 10 s 1 core @ 2.5 Ghz (C/C++)
J. Behley, V. Steinhage and A. Cremers: Laser-based Segment Classification Using a Mixture of Bag-of-Words. Proc. of the IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2013.
Table as LaTeX | Only published Methods

Pedestrian


Method Setting Code Moderate Easy Hard Runtime Environment
1 PiFeNet code 53.92 % 63.25 % 50.53 % 0.03 s 1 core @ 2.5 Ghz (C/C++)
D. Le, H. Shi, H. Rezatofighi and J. Cai: Accurate and Real-time 3D Pedestrian Detection Using an Efficient Attentive Pillar Network. IEEE Robotics and Automation Letters 2022.
2 CasA++ code 53.84 % 60.14 % 51.35 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
H. Wu, J. Deng, C. Wen, X. Li and C. Wang: CasA: A Cascade Attention Network for 3D Object Detection from LiDAR point clouds. IEEE Transactions on Geoscience and Remote Sensing 2022.
3 TED code 53.48 % 60.13 % 50.89 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
H. Wu, C. Wen, W. Li, R. Yang and C. Wang: Transformation-Equivariant 3D Object Detection for Autonomous Driving. AAAI 2023.
4 UPIDet code 53.32 % 58.91 % 50.82 % 0.11 s 1 core @ 2.5 Ghz (C/C++)
Y. Zhang, Q. Zhang, J. Hou, Y. Yuan and G. Xing: Unleash the Potential of Image Branch for Cross-modal 3D Object Detection. Thirty-seventh Conference on Neural Information Processing Systems 2023.
5 ImagePG code 52.99 % 60.69 % 50.33 % 1 s 1 core @ 2.5 Ghz (C/C++)
M. Lee, S. Moon, S. Lee, R. Mahjourian and J. Kim: Image-Guided Semantic Pseudo- LiDAR Point Generation for 3D Object Detection. Proceedings of the IEEE/CVF Winter Conference on Applications of Computer Vision (WACV) 2026.
6 EQ-PVRCNN code 52.81 % 61.73 % 49.87 % 0.2 s GPU @ 2.5 Ghz (Python + C/C++)
Z. Yang, L. Jiang, Y. Sun, B. Schiele and J. Jia: A Unified Query-based Paradigm for Point Cloud Understanding. Proceedings of the IEEE Conference on Computer Vision and Pattern Recognition 2022.
7 WinMamba code 52.59 % 59.75 % 49.13 % 0.1 s 1 core @ 2.5 Ghz (Python)
8 VPFNet code 52.41 % 60.07 % 50.28 % 0.2 s 1 core @ 2.5 Ghz (C/C++)
C. Wang, H. Chen and L. Fu: VPFNet: Voxel-Pixel Fusion Network for Multi-class 3D Object Detection. 2021.
C. Wang, H. Chen, Y. Chen, P. Hsiao and L. Fu: VoPiFNet: Voxel-Pixel Fusion Network for Multi-Class 3D Object Detection. IEEE Transactions on Intelligent Transportation Systems 2024.
9 Frustum-PointPillars code 52.23 % 60.98 % 48.30 % 0.06 s 4 cores @ 3.0 Ghz (Python)
A. Paigwar, D. Sierra-Gonzalez, \. Erkent and C. Laugier: Frustum-PointPillars: A Multi-Stage Approach for 3D Object Detection using RGB Camera and LiDAR. International Conference on Computer Vision, ICCV, Workshop on Autonomous Vehicle Vision 2021.
10 LoGoNet code 52.06 % 58.24 % 49.87 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
X. Li, T. Ma, Y. Hou, B. Shi, Y. Yang, Y. Liu, X. Wu, Q. Chen, Y. Li, Y. Qiao and others: LoGoNet: Towards Accurate 3D Object Detection with Local-to-Global Cross-Modal Fusion. CVPR 2023.
11 TANet code 51.38 % 60.85 % 47.54 % 0.035s GPU @ 2.5 Ghz (Python + C/C++)
Z. Liu, X. Zhao, T. Huang, R. Hu, Y. Zhou and X. Bai: TANet: Robust 3D Object Detection from Point Clouds with Triple Attention. AAAI 2020.
12 CasA code 51.37 % 57.95 % 49.08 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
H. Wu, J. Deng, C. Wen, X. Li and C. Wang: CasA: A Cascade Attention Network for 3D Object Detection from LiDAR point clouds. IEEE Transactions on Geoscience and Remote Sensing 2022.
13 SparseFormer code 50.96 % 57.16 % 48.42 % 0.06 s 1 core @ 2.5 Ghz (C/C++)
ERROR: Wrong syntax in BIBTEX file.
14 MLF-DET 50.88 % 56.45 % 47.60 % 0.09 s 1 core @ 2.5 Ghz (C/C++)
Z. Lin, Y. Shen, S. Zhou, S. Chen and N. Zheng: MLF-DET: Multi-Level Fusion for Cross- Modal 3D Object Detection. International Conference on Artificial Neural Networks 2023.
15 MMLab PV-RCNN
This method makes use of Velodyne laser scans.
code 50.57 % 59.86 % 46.74 % 0.08 s 1 core @ 2.5 Ghz (Python + C/C++)
S. Shi, C. Guo, L. Jiang, Z. Wang, J. Shi, X. Wang and H. Li: PV-RCNN: Point-Voxel Feature Set Abstraction for 3D Object Detection. CVPR 2020.
16 DPPFA-Net 50.55 % 57.02 % 47.25 % 0.1 s 1 core @ 2.5 Ghz (Python)
J. Wang, X. Kong, H. Nishikawa, Q. Lian and H. Tomiyama: Dynamic Point-Pixel Feature Alignment for Multi-modal 3D Object Detection. IEEE Internet of Things Journal 2023.
17 HotSpotNet 50.53 % 57.39 % 46.65 % 0.04 s 1 core @ 2.5 Ghz (Python + C/C++)
Q. Chen, L. Sun, Z. Wang, K. Jia and A. Yuille: object as hotspots. Proceedings of the European Conference on Computer Vision (ECCV) 2020.
18 LumiNet 50.44 % 57.64 % 46.74 % 0.1 s 1 core @ 2.5 Ghz (Python)
19 VMVS
This method makes use of Velodyne laser scans.
50.34 % 60.34 % 46.45 % 0.25 s GPU @ 2.5 Ghz (Python)
J. Ku, A. Pon, S. Walsh and S. Waslander: Improving 3D object detection for pedestrians with virtual multi-view synthesis orientation estimation. IROS 2019.
20 AVOD-FPN
This method makes use of Velodyne laser scans.
code 50.32 % 58.49 % 46.98 % 0.1 s Titan X (Pascal)
J. Ku, M. Mozifian, J. Lee, A. Harakeh and S. Waslander: Joint 3D Proposal Generation and Object Detection from View Aggregation. IROS 2018.
21 3DSSD code 49.94 % 60.54 % 45.73 % 0.04 s GPU @ 2.5 Ghz (Python + C/C++)
Z. Yang, Y. Sun, S. Liu and J. Jia: 3DSSD: Point-based 3D Single Stage Object Detector. CVPR 2020.
22 PointPainting
This method makes use of Velodyne laser scans.
49.93 % 58.70 % 46.29 % 0.4 s GPU @ 2.5 Ghz (Python + C/C++)
S. Vora, A. Lang, B. Helou and O. Beijbom: PointPainting: Sequential Fusion for 3D Object Detection. CVPR 2020.
23 SemanticVoxels 49.93 % 58.91 % 47.31 % 0.04 s GPU @ 2.5 Ghz (Python + C/C++)
J. Fei, W. Chen, P. Heidenreich, S. Wirges and C. Stiller: SemanticVoxels: Sequential Fusion for 3D Pedestrian Detection using LiDAR Point Cloud and Semantic Segmentation. MFI 2020.
24 ACDet code 49.82 % 58.35 % 47.17 % 0.05 s 1 core @ 2.5 Ghz (C/C++)
J. Xu, G. Wang, X. Zhang and G. Wan: ACDet: Attentive Cross-view Fusion for LiDAR-based 3D Object Detection. 3DV 2022.
25 MMLab-PartA^2
This method makes use of Velodyne laser scans.
code 49.81 % 59.04 % 45.92 % 0.08 s GPU @ 2.5 Ghz (Python + C/C++)
S. Shi, Z. Wang, J. Shi, X. Wang and H. Li: From Points to Parts: 3D Object Detection from Point Cloud with Part-aware and Part-aggregation Network. IEEE Transactions on Pattern Analysis and Machine Intelligence 2020.
26 USVLab BSAODet code 49.75 % 56.05 % 47.59 % 0.04 s 1 core @ 2.5 Ghz (C/C++)
W. Xiao, Y. Peng, C. Liu, J. Gao, Y. Wu and X. Li: Balanced Sample Assignment and Objective for Single-Model Multi-Class 3D Object Detection. IEEE Transactions on Circuits and Systems for Video Technology 2023.
27 ACFNet 49.74 % 58.07 % 47.27 % 0.11 s 1 core @ 2.5 Ghz (C/C++)
Y. Tian, X. Zhang, X. Wang, J. Xu, J. Wang, R. Ai, W. Gu and W. Ding: ACF-Net: Asymmetric Cascade Fusion for 3D Detection With LiDAR Point Clouds and Images. IEEE Transactions on Intelligent Vehicles 2023.
28 HC-MVMM 49.68 % 54.78 % 47.66 % 0.06 s 1 core @ 2.5 Ghz (Python)
29 F-PointNet
This method makes use of Velodyne laser scans.
code 49.57 % 57.13 % 45.48 % 0.17 s GPU @ 3.0 Ghz (Python)
C. Qi, W. Liu, C. Wu, H. Su and L. Guibas: Frustum PointNets for 3D Object Detection from RGB-D Data. arXiv preprint arXiv:1711.08488 2017.
30 DynaMo3D 49.29 % 58.23 % 46.56 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
31 F-ConvNet
This method makes use of Velodyne laser scans.
code 48.96 % 57.04 % 44.33 % 0.47 s GPU @ 2.5 Ghz (Python + C/C++)
Z. Wang and K. Jia: Frustum ConvNet: Sliding Frustums to Aggregate Local Point-Wise Features for Amodal 3D Object Detection. IROS 2019.
32 HVNet 48.86 % 54.84 % 46.33 % 0.03 s GPU @ 2.0 Ghz (Python)
M. Ye, S. Xu and T. Cao: HVNet: Hybrid Voxel Network for LiDAR Based 3D Object Detection. CVPR 2020.
33 CAT-Det 48.78 % 57.13 % 45.56 % 0.3 s GPU @ 2.5 Ghz (Python + C/C++)
Y. Zhang, J. Chen and D. Huang: CAT-Det: Contrastively Augmented Transformer for Multi-modal 3D Object Detection. CVPR 2022.
34 STD code 48.72 % 60.02 % 44.55 % 0.08 s GPU @ 2.5 Ghz (Python + C/C++)
Z. Yang, Y. Sun, S. Liu, X. Shen and J. Jia: STD: Sparse-to-Dense 3D Object Detector for Point Cloud. ICCV 2019.
35 PointPillars
This method makes use of Velodyne laser scans.
code 48.64 % 57.60 % 45.78 % 16 ms 1080ti GPU and Intel i7 CPU
A. Lang, S. Vora, H. Caesar, L. Zhou, J. Yang and O. Beijbom: PointPillars: Fast Encoders for Object Detection from Point Clouds. CVPR 2019.
36 EPNet++ 48.47 % 56.24 % 45.73 % 0.1 s GPU @ 2.5 Ghz (Python)
Z. Liu, T. Huang, B. Li, X. Chen, X. Wang and X. Bai: EPNet++: Cascade Bi-Directional Fusion for Multi-Modal 3D Object Detection. IEEE Transactions on Pattern Analysis and Machine Intelligence 2022.
37 MGAF-3DSSD code 48.46 % 56.09 % 44.90 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
J. Li, H. Dai, L. Shao and Y. Ding: Anchor-free 3D Single Stage Detector with Mask-Guided Attention for Point Cloud. MM '21: The 29th ACM International Conference on Multimedia (ACM MM) 2021.
38 Fast-CLOCs 48.27 % 57.19 % 44.55 % 0.1 s GPU @ 2.5 Ghz (Python)
S. Pang, D. Morris and H. Radha: Fast-CLOCs: Fast Camera-LiDAR Object Candidates Fusion for 3D Object Detection. Proceedings of the IEEE/CVF Winter Conference on Applications of Computer Vision (WACV) 2022.
39 FromVoxelToPoint code 48.15 % 56.54 % 45.63 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
J. Li, H. Dai, L. Shao and Y. Ding: From Voxel to Point: IoU-guided 3D Object Detection for Point Cloud with Voxel-to- Point Decoder. MM '21: The 29th ACM International Conference on Multimedia (ACM MM) 2021.
40 auto_test 48.14 % 54.66 % 44.52 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
41 EOTL code 47.80 % 56.52 % 43.36 % TBD s 1 core @ 2.5 Ghz (Python + C/C++)
R. Yang, Z. Yan, T. Yang, Y. Wang and Y. Ruichek: Efficient Online Transfer Learning for Road Participants Detection in Autonomous Driving. IEEE Sensors Journal 2023.
42 HMFI code 47.77 % 55.61 % 45.17 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
X. Li, B. Shi, Y. Hou, X. Wu, T. Ma, Y. Li and L. He: Homogeneous Multi-modal Feature Fusion and Interaction for 3D Object Detection. ECCV 2022.
43 fshe_voxeln_1 47.76 % 55.52 % 44.97 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
44 TriPlane-Lite 47.44 % 53.79 % 44.96 % 0.02 s 1 core @ 2.5 Ghz (C/C++)
Anonymous: Under review. Under review 2026.
45 P2V-RCNN 47.36 % 54.15 % 45.10 % 0.1 s 2 cores @ 2.5 Ghz (Python)
J. Li, S. Luo, Z. Zhu, H. Dai, A. Krylov, Y. Ding and L. Shao: P2V-RCNN: Point to Voxel Feature Learning for 3D Object Detection from Point Clouds. IEEE Access 2021.
46 fsh_l_1_4 47.35 % 55.26 % 44.55 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
47 Point-GNN
This method makes use of Velodyne laser scans.
code 47.07 % 55.36 % 44.61 % 0.6 s GPU @ 2.5 Ghz (Python)
W. Shi and R. Rajkumar: Point-GNN: Graph Neural Network for 3D Object Detection in a Point Cloud. CVPR 2020.
48 3ONet 47.05 % 56.76 % 44.62 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
H. Hoang and M. Yoo: 3ONet: 3-D Detector for Occluded Object Under Obstructed Conditions. IEEE Sensors Journal 2023.
49 IFOD 46.98 % 53.36 % 43.98 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
50 SCNet
This method makes use of Velodyne laser scans.
46.73 % 56.87 % 42.74 % 0.04 s GPU @ 3.0 Ghz (Python)
Z. Wang, H. Fu, L. Wang, L. Xiao and B. Dai: SCNet: Subdivision Coding Network for Object Detection Based on 3D Point Cloud. IEEE Access 2019.
51 PASS-PV-RCNN-Plus 46.36 % 51.47 % 44.10 % 1 s 1 core @ 2.5 Ghz (Python)
Anonymous: Leveraging Anchor-based LiDAR 3D Object Detection via Point Assisted Sample Selection. will submit to computer vision conference/journal 2024.
52 MoAd code 46.19 % 54.20 % 43.85 % 0.01 s 1 core @ 2.5 Ghz (C/C++)
53 MMLab-PointRCNN
This method makes use of Velodyne laser scans.
code 46.13 % 54.77 % 42.84 % 0.1 s GPU @ 2.5 Ghz (Python + C/C++)
S. Shi, X. Wang and H. Li: Pointrcnn: 3d object proposal generation and detection from point cloud. Proceedings of the IEEE Conference on Computer Vision and Pattern Recognition 2019.
54 fsh_saf_1 45.94 % 53.73 % 43.61 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
55 ARPNET 45.92 % 55.48 % 42.54 % 0.08 s GPU @ 2.5 Ghz (Python + C/C++)
Y. Ye, C. Zhang and X. Hao: ARPNET: attention region proposal network for 3D object detection. Science China Information Sciences 2019.
56 DSA-PV-RCNN
This method makes use of Velodyne laser scans.
code 45.82 % 52.03 % 43.81 % 0.08 s 1 core @ 2.5 Ghz (Python + C/C++)
P. Bhattacharyya, C. Huang and K. Czarnecki: SA-Det3D: Self-Attention Based Context-Aware 3D Object Detection. 2021.
57 DPFusion code 45.78 % 53.33 % 43.53 % 0.07 s 1 core @ 2.5 Ghz (C/C++)
Y. Mo, Y. Wu, J. Zhao, Y. Hu, J. Wang and J. Yan: Enhancing LiDAR Point Features with Foundation Model Priors for 3D Object Detection. ITSC 2025.
58 kfc 45.71 % 53.30 % 43.53 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
59 SVGA-Net 45.68 % 53.09 % 43.30 % 0.03s 1 core @ 2.5 Ghz (Python + C/C++)
Q. He, Z. Wang, H. Zeng, Y. Zeng and Y. Liu: SVGA-Net: Sparse Voxel-Graph Attention Network for 3D Object Detection from Point Clouds. AAAI 2022.
60 epBRM
This method makes use of Velodyne laser scans.
code 45.49 % 52.48 % 42.75 % 0.10 s 1 core @ 2.5 Ghz (C/C++)
K. Shin: Improving a Quality of 3D Object Detection by Spatial Transformation Mechanism. arXiv preprint arXiv:1910.04853 2019.
61 PG-RCNN code 45.48 % 51.63 % 43.30 % 0.06 s GPU @ 1.5 Ghz (Python)
I. Koo, I. Lee, S. Kim, H. Kim, W. Jeon and C. Kim: PG-RCNN: Semantic Surface Point Generation for 3D Object Detection. 2023.
62 PDV code 45.45 % 51.95 % 43.33 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
J. Hu, T. Kuai and S. Waslander: Point Density-Aware Voxels for LiDAR 3D Object Detection. CVPR 2022.
63 MLOD
This method makes use of Velodyne laser scans.
code 45.40 % 55.09 % 41.42 % 0.12 s GPU @ 1.5 Ghz (Python)
J. Deng and K. Czarnecki: MLOD: A multi-view 3D object detection based on robust feature fusion method. arXiv preprint arXiv:1909.04163 2019.
64 IA-SSD (single) code 45.07 % 52.73 % 42.75 % 0.013 s 1 core @ 2.5 Ghz (C/C++)
Y. Zhang, Q. Hu, G. Xu, Y. Ma, J. Wan and Y. Guo: Not All Points Are Equal: Learning Highly Efficient Point-based Detectors for 3D LiDAR Point Clouds. CVPR 2022.
65 DFAF3D 45.01 % 52.86 % 42.73 % 0.05 s 1 core @ 2.5 Ghz (Python)
Q. Tang, X. Bai, J. Guo, B. Pan and W. Jiang: DFAF3D: A dual-feature-aware anchor-free single-stage 3D detector for point clouds. Image and Vision Computing 2023.
66 SRDL 44.84 % 52.42 % 42.56 % 0.05 s 1 core @ 2.5 Ghz (Python + C/C++)
ERROR: Wrong syntax in BIBTEX file.
67 M3DeTR code 44.78 % 50.63 % 42.57 % n/a s GPU @ 1.0 Ghz (Python)
T. Guan, J. Wang, S. Lan, R. Chandra, Z. Wu, L. Davis and D. Manocha: M3DeTR: Multi-representation, Multi- scale, Mutual-relation 3D Object Detection with Transformers. 2021.
68 SIF 44.28 % 52.05 % 42.03 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
P. An: SIF. Submitted to CVIU 2021.
69 DVFENet 44.12 % 50.98 % 41.62 % 0.05 s 1 core @ 2.5 Ghz (Python + C/C++)
Y. He, G. Xia, Y. Luo, L. Su, Z. Zhang, W. Li and P. Wang: DVFENet: Dual-branch Voxel Feature Extraction Network for 3D Object Detection. Neurocomputing 2021.
70 Faraway-Frustum
This method makes use of Velodyne laser scans.
code 43.85 % 52.15 % 41.68 % 0.1 s GPU @ 2.5 Ghz (Python)
H. Zhang, D. Yang, E. Yurtsever, K. Redmill and U. Ozguner: Faraway-frustum: Dealing with lidar sparsity for 3D object detection using fusion. 2021 IEEE International Intelligent Transportation Systems Conference (ITSC) 2021.
71 S-AT GCN 43.43 % 50.63 % 41.58 % 0.02 s GPU @ 2.0 Ghz (Python)
L. Wang, C. Wang, X. Zhang, T. Lan and J. Li: S-AT GCN: Spatial-Attention Graph Convolution Network based Feature Enhancement for 3D Object Detection. CoRR 2021.
72 BirdNet+
This method makes use of Velodyne laser scans.
code 42.87 % 48.90 % 40.59 % 0.11 s Titan Xp (PyTorch)
A. Barrera, J. Beltrán, C. Guindel, J. Iglesias and F. García: BirdNet+: Two-Stage 3D Object Detection in LiDAR through a Sparsity-Invariant Bird’s Eye View. IEEE Access 2021.
73 L-AUG 42.84 % 50.32 % 40.29 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
T. Cortinhal, I. Gouigah and E. Aksoy: Semantics-aware LiDAR-Only Pseudo Point Cloud Generation for 3D Object Detection. 2023.
74 PCNet3D++ 42.81 % 50.62 % 40.36 % 0.05 s GPU @ 2.5 Ghz (Python)
T. Prasanth, R. Padhy and B. Sivaselvan: PCNet3D++: A pillar-based cascaded 3D object detection model with an enhanced 2D backbone. Image and Vision Computing 2025.
75 DSFNet 42.68 % 51.31 % 39.65 % 0.03 s GPU @ 2.5 Ghz (Python)
T. Prasanth, R. Padhy and B. Sivaselvan: LiDAR Sensor-Based Dual-Scale Fusion Approach for Bird’s-Eye View Sensing in Autonomous Vehicles. IEEE Sensors Letters 2025.
76 IA-SSD (multi) code 42.61 % 51.76 % 40.51 % 0.014 s 1 core @ 2.5 Ghz (C/C++)
Y. Zhang, Q. Hu, G. Xu, Y. Ma, J. Wan and Y. Guo: Not All Points Are Equal: Learning Highly Efficient Point-based Detectors for 3D LiDAR Point Clouds. CVPR 2022.
77 saf_u 42.42 % 49.37 % 40.28 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
78 XView 42.42 % 47.24 % 39.96 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
L. Xie, G. Xu, D. Cai and X. He: X-view: Non-egocentric Multi-View 3D Object Detector. 2021.
79 PCNet3D 42.19 % 50.02 % 39.69 % 0.05 s GPU @ 2.5 Ghz (Python)
T. Prasanth, R. Padhy and B. Sivaselvan: PCNet3D: A Pillar Based Cascaded 3D Object Detection Model Using LiDAR Point Cloud. International Conference on Computer Vision and Image Processing 2024.
80 GraphAlign(ICCV2023) code 41.95 % 46.61 % 40.05 % 0.03 s GPU @ 2.0 Ghz (Python)
Z. Song, H. Wei, L. Bai, L. Yang and C. Jia: GraphAlign: Enhancing accurate feature alignment by graph matching for multi-modal 3D object detection. Proceedings of the IEEE/CVF International Conference on Computer Vision 2023.
81 MSFASA-3DNet 41.94 % 48.10 % 40.05 % 0.03 s GPU @ 2.5 Ghz (Python)
T. Prasanth, R. Padhy and B. Sivaselvan: MSFASA-3DNet: Multi-Scale Feature Aggregation and Spatial Attention for 3D Object Detection. IEEE Transactions on Artificial Intelligence 2026.
82 M3DNet 41.84 % 50.30 % 39.49 % 0.5 s 1 core @ 2.5 Ghz (C/C++)
T. Prasanth, R. Padhy and B. Sivaselvan: M3DNet: Minimalist 3D Detection Backbone for Efficient and Accurate 3D Object Detection. Proceedings of the 18th International Conference on Agents and Artificial Intelligence (ICAART) 2026.
83 LGFE 41.80 % 50.40 % 39.33 % 0.03 s 1 core @ 2.5 Ghz (Python)
84 LGD 41.59 % 50.70 % 37.86 % 0.03 s 1 core @ 2.5 Ghz (Python)
85 SeSame-voxel code 41.59 % 50.12 % 37.79 % N/A s TITAN RTX @ 1.35 Ghz (Python)
H. O, C. Yang and K. Huh: SeSame: Simple, Easy 3D Object Detection with Point-Wise Semantics. Proceedings of the Asian Conference on Computer Vision (ACCV) 2024.
86 HINTED code 41.55 % 53.09 % 39.18 % 0.04 s 1 core @ 2.5 Ghz (C/C++)
Q. Xia, W. Ye, H. Wu, S. Zhao, L. Xing, X. Huang, J. Deng, X. Li, C. Wen and C. Wang: HINTED: Hard Instance Enhanced Detector with Mixed-Density Feature Fusion for Sparsely- Supervised 3D Object Detection. Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition 2024.
87 AFCAP 41.39 % 48.70 % 39.31 % 0.1 s 1 core @ 2.5 Ghz (Python)
88 BASE
This method uses stereo information.
This method makes use of Velodyne laser scans.
41.31 % 50.05 % 37.58 % N/A s GPU @ 2.5 Ghz (Python)
89 VPFnet 41.26 % 49.89 % 39.17 % 0.02 s 1 core @ 2.5 Ghz (C/C++)
90 SeSame-point code 41.22 % 48.25 % 39.18 % N/A s TITAN RTX @ 1.35 Ghz (Python)
H. O, C. Yang and K. Huh: SeSame: Simple, Easy 3D Object Detection with Point-Wise Semantics. Proceedings of the Asian Conference on Computer Vision (ACCV) 2024.
91 PFF3D
This method makes use of Velodyne laser scans.
code 40.94 % 48.74 % 38.54 % 0.05 s GPU @ 3.0 Ghz (Python + C/C++)
L. Wen and K. Jo: Fast and Accurate 3D Object Detection for Lidar-Camera-Based Autonomous Vehicles Using One Shared Voxel-Based Backbone. IEEE Access 2021.
92 M-VPFnet 40.22 % 49.27 % 36.88 % 0.05 s 1 core @ 2.5 Ghz (Python)
93 DSGN++
This method uses stereo information.
code 38.92 % 50.26 % 35.12 % 0.2 s GeForce RTX 2080Ti
Y. Chen, S. Huang, S. Liu, B. Yu and J. Jia: DSGN++: Exploiting Visual-Spatial Relation for Stereo-Based 3D Detectors. IEEE Transactions on Pattern Analysis and Machine Intelligence 2022.
94 AB3DMOT
This method makes use of Velodyne laser scans.
This is an online method (no batch processing).
code 38.79 % 47.51 % 35.85 % 0.0047s 1 core @ 2.5 Ghz (python)
X. Weng and K. Kitani: A Baseline for 3D Multi-Object Tracking. arXiv:1907.03961 2019.
95 BirdNet+ (legacy)
This method makes use of Velodyne laser scans.
code 38.28 % 45.53 % 35.37 % 0.1 s Titan Xp (PyTorch)
A. Barrera, C. Guindel, J. Beltrán and F. García: BirdNet+: End-to-End 3D Object Detection in LiDAR Bird’s Eye View. 2020 IEEE 23rd International Conference on Intelligent Transportation Systems (ITSC) 2020.
96 PL++: PV-RCNN++
This method uses stereo information.
This method makes use of Velodyne laser scans.
37.96 % 44.88 % 35.48 % 0.342 s RTX 4060Ti (Python)
X. Gong, X. Huang, S. Chen and B. Zhang: Enhancing 3D Detection Accuracy in Autonomous Driving through Pseudo-LiDAR Augmentation and Downsampling. 2024 International Conference on Image Processing, Computer Vision and Machine Learning (ICICML) 2024.
97 CSW3D
This method makes use of Velodyne laser scans.
37.96 % 49.27 % 33.83 % 0.03 s 4 cores @ 2.5 Ghz (C/C++)
J. Hu, T. Wu, H. Fu, Z. Wang and K. Ding: Cascaded Sliding Window Based Real-Time 3D Region Proposal for Pedestrian Detection. ROBIO 2019.
98 StereoDistill 37.75 % 50.79 % 34.28 % 0.4 s 1 core @ 2.5 Ghz (Python)
Z. Liu, X. Ye, X. Tan, D. Errui, Y. Zhou and X. Bai: StereoDistill: Pick the Cream from LiDAR for Distilling Stereo-based 3D Object Detection. Proceedings of the AAAI Conference on Artificial Intelligence 2023.
99 SeSame-pillar code 37.31 % 44.21 % 35.17 % N/A s TITAN RTX @ 1.35 Ghz (Python)
H. O, C. Yang and K. Huh: SeSame: Simple, Easy 3D Object Detection with Point-Wise Semantics. Proceedings of the Asian Conference on Computer Vision (ACCV) 2024.
100 DMF
This method uses stereo information.
34.92 % 42.08 % 32.69 % 0.2 s 1 core @ 2.5 Ghz (Python + C/C++)
X. J. Chen and W. Xu: Disparity-Based Multiscale Fusion Network for Transportation Detection. IEEE Transactions on Intelligent Transportation Systems 2022.
101 SparsePool code 34.15 % 43.33 % 31.78 % 0.13 s 8 cores @ 2.5 Ghz (Python)
Z. Wang, W. Zhan and M. Tomizuka: Fusing bird view lidar point cloud and front view camera image for deep object detection. arXiv preprint arXiv:1711.06703 2017.
102 MMLAB LIGA-Stereo
This method uses stereo information.
code 34.13 % 44.71 % 30.42 % 0.4 s 1 core @ 2.5 Ghz (Python + C/C++)
X. Guo, S. Shi, X. Wang and H. Li: LIGA-Stereo: Learning LiDAR Geometry Aware Representations for Stereo-based 3D Detector. Proceedings of the IEEE/CVF International Conference on Computer Vision (ICCV) 2021.
103 SeSame-voxel w/score code 33.76 % 39.42 % 31.31 % N/A s GPU @ 1.5 Ghz (Python)
H. O, C. Yang and K. Huh: SeSame: Simple, Easy 3D Object Detection with Point-Wise Semantics. Proceedings of the Asian Conference on Computer Vision (ACCV) 2024.
104 AVOD
This method makes use of Velodyne laser scans.
code 33.57 % 42.58 % 30.14 % 0.08 s Titan X (pascal)
J. Ku, M. Mozifian, J. Lee, A. Harakeh and S. Waslander: Joint 3D Proposal Generation and Object Detection from View Aggregation. IROS 2018.
105 SparsePool code 33.22 % 41.55 % 29.66 % 0.13 s 8 cores @ 2.5 Ghz (Python)
Z. Wang, W. Zhan and M. Tomizuka: Fusing bird view lidar point cloud and front view camera image for deep object detection. arXiv preprint arXiv:1711.06703 2017.
106 SeSame-pillar w/scor code 32.78 % 39.11 % 30.87 % N/A s 1 core @ 2.5 Ghz (C/C++)
H. O, C. Yang and K. Huh: SeSame: Simple, Easy 3D Object Detection with Point-Wise Semantics. Proceedings of the Asian Conference on Computer Vision (ACCV) 2024.
107 MSVN
This method uses stereo information.
29.62 % 40.47 % 26.40 % 0.15 s 1 core @ 2.5 Ghz (Python)
108 CG-Stereo
This method uses stereo information.
29.56 % 39.24 % 25.87 % 0.57 s GeForce RTX 2080 Ti
C. Li, J. Ku and S. Waslander: Confidence Guided Stereo 3D Object Detection with Split Depth Estimation. IROS 2020.
109 PointRGBNet 29.32 % 38.07 % 26.94 % 0.08 s 4 cores @ 2.5 Ghz (Python + C/C++)
P. Xie Desheng: Real-time Detection of 3D Objects Based on Multi-Sensor Information Fusion. Automotive Engineering 2022.
110 Fade 3D code 29.18 % 36.14 % 27.42 % 0.01 s 1 core @ 2.5 Ghz (C/C++)
W. Ye, Q. Xia, H. Wu, Z. Dong, R. Zhong, C. Wang and C. Wen: Fade3D: Fast and Deployable 3D Object Detection for Autonomous Driving. IEEE Transactions on Intelligent Transportation Systems 2025.
111 Disp R-CNN
This method uses stereo information.
code 29.12 % 42.72 % 25.09 % 0.387 s GPU @ 2.5 Ghz (Python + C/C++)
J. Sun, L. Chen, Y. Xie, S. Zhang, Q. Jiang, X. Zhou and H. Bao: Disp R-CNN: Stereo 3D Object Detection via Shape Prior Guided Instance Disparity Estimation. CVPR 2020.
112 Disp R-CNN (velo)
This method uses stereo information.
code 28.34 % 40.21 % 24.46 % 0.387 s GPU @ 2.5 Ghz (Python + C/C++)
J. Sun, L. Chen, Y. Xie, S. Zhang, Q. Jiang, X. Zhou and H. Bao: Disp R-CNN: Stereo 3D Object Detection via Shape Prior Guided Instance Disparity Estimation. CVPR 2020.
113 EpiStereo 27.57 % 38.08 % 24.01 % 1 s 1 core @ 2.5 Ghz (C/C++)
114 StereoDETR
This method uses stereo information.
code 25.89 % 36.97 % 22.26 % 0.02 s GPU @ 2.5 Ghz (Python)
S. Mu, Z. Gu, Z. Ai, A. Liu, Y. Gao and S. Xu: StereoDETR: Stereo-Based Transformer for 3D Object Detection. IEEE Transactions on Circuits and Systems for Video Technology 2026.
115 SeSame-point w/score code 25.79 % 33.98 % 22.50 % N/A s 1 core @ 1.5 Ghz (Python)
H. O, C. Yang and K. Huh: SeSame: Simple, Easy 3D Object Detection with Point-Wise Semantics. Proceedings of the Asian Conference on Computer Vision (ACCV) 2024.
116 DDStereo code 24.72 % 35.80 % 22.06 % 0.024 s GPU @ 2.5 Ghz (Python)
S. Mu, Z. Gu, Z. Ai, Y. Gao and S. Xu: DDStereo: Efficient Dual Decoder Transformers for Stereo 3D Road Anomaly Detection. European Conference on Computer Vision 2026.
117 BirdNet
This method makes use of Velodyne laser scans.
23.06 % 28.20 % 21.65 % 0.11 s Titan Xp (Caffe)
J. Beltrán, C. Guindel, F. Moreno, D. Cruzado, F. García and A. Escalera: BirdNet: A 3D Object Detection Framework from LiDAR Information. 2018 21st International Conference on Intelligent Transportation Systems (ITSC) 2018.
118 SG3D 21.31 % 30.80 % 18.89 % 0.07 s 1 core @ 2.5 Ghz (C/C++)
119 OC Stereo
This method uses stereo information.
code 20.80 % 29.79 % 18.62 % 0.35 s 1 core @ 2.5 Ghz (Python + C/C++)
A. Pon, J. Ku, C. Li and S. Waslander: Object-Centric Stereo Matching for 3D Object Detection. ICRA 2020.
120 YOLOStereo3D
This method uses stereo information.
code 20.76 % 31.01 % 18.41 % 0.1 s GPU 1080Ti
Y. Liu, L. Wang and M. Liu: YOLOStereo3D: A Step Back to 2D for Efficient Stereo 3D Detection. 2021 International Conference on Robotics and Automation (ICRA) 2021.
121 DSGN
This method uses stereo information.
code 20.75 % 26.61 % 18.86 % 0.67 s NVIDIA Tesla V100
Y. Chen, S. Liu, X. Shen and J. Jia: DSGN: Deep Stereo Geometry Network for 3D Object Detection. CVPR 2020.
122 Complexer-YOLO
This method makes use of Velodyne laser scans.
18.26 % 21.42 % 17.06 % 0.06 s GPU @ 3.5 Ghz (C/C++)
M. Simon, K. Amende, A. Kraus, J. Honer, T. Samann, H. Kaulbersch, S. Milz and H. Michael Gross: Complexer-YOLO: Real-Time 3D Object Detection and Tracking on Semantic Point Clouds. The IEEE Conference on Computer Vision and Pattern Recognition (CVPR) Workshops 2019.
123 EfficientStereo-3D 17.24 % 24.35 % 15.21 % 0.06 s 1 core @ 2.5 Ghz (Python)
124 TopNet-Retina
This method makes use of Velodyne laser scans.
14.57 % 18.04 % 12.48 % 52ms GeForce 1080Ti (tensorflow-gpu, v1.12)
S. Wirges, T. Fischer, C. Stiller and J. Frias: Object Detection and Classification in Occupancy Grid Maps Using Deep Convolutional Networks. 2018 21st International Conference on Intelligent Transportation Systems (ITSC) 2018.
125 MonOri code 14.35 % 20.86 % 12.45 % 0.03 s 4 cores @ 2.5 Ghz (Python)
H. Yao, P. Han, J. Chen, Z. Wang, Y. Qiu, X. Wang, Y. wang, X. Chai, C. Cao and W. Jin: MonOri: Orientation-Guided PnP for Monocular 3-D Object Detection. IEEE Transactions on Neural Networks and Learning Systems 2025.
126 RT3D-GMP
This method uses stereo information.
14.22 % 19.92 % 12.83 % 0.06 s GPU @ 2.5 Ghz (Python + C/C++)
H. Königshof and C. Stiller: Learning-Based Shape Estimation with Grid Map Patches for Realtime 3D Object Detection for Automated Driving. 2020 IEEE 23rd International Conference on Intelligent Transportation Systems (ITSC) 2020.
127 TopNet-HighRes
This method makes use of Velodyne laser scans.
13.50 % 19.43 % 11.93 % 101ms NVIDIA GeForce 1080 Ti (tensorflow-gpu)
S. Wirges, T. Fischer, C. Stiller and J. Frias: Object Detection and Classification in Occupancy Grid Maps Using Deep Convolutional Networks. 2018 21st International Conference on Intelligent Transportation Systems (ITSC) 2018.
128 ESGN
This method uses stereo information.
13.03 % 17.94 % 11.54 % 0.06 s GPU @ 2.5 Ghz (Python + C/C++)
A. Gao, Y. Pang, J. Nie, Z. Shao, J. Cao, Y. Guo and X. Li: ESGN: Efficient Stereo Geometry Network for Fast 3D Object Detection. IEEE Transactions on Circuits and Systems for Video Technology 2022.
129 LeAD-M3D code 12.52 % 19.06 % 10.76 % 0.0079 s 1 core @ 2.5 Ghz (Python)
J. Meier, J. Michel, O. Dhaouadi, Y. Yang, C. Reich, Z. Bauer, S. Roth, M. Pollefeys, J. Kaiser and D. Cremers: LeAD-M3D: Leveraging Asymmetric Distillation for Real-Time Monocular 3D Detection. European Conference on Computer Vision (ECCV) 2026.
130 DD3D code 12.51 % 18.58 % 10.65 % n/a s 1 core @ 2.5 Ghz (C/C++)
D. Park, R. Ambrus, V. Guizilini, J. Li and A. Gaidon: Is Pseudo-Lidar needed for Monocular 3D Object detection?. IEEE/CVF International Conference on Computer Vision (ICCV) .
131 MonoLSS 12.34 % 18.40 % 10.54 % 0.04 s 1 core @ 2.5 Ghz (Python)
Z. Li, J. Jia and Y. Shi: MonoLSS: Learnable Sample Selection For Monocular 3D Detection. International Conference on 3D Vision 2024.
132 PS-fld code 12.23 % 19.03 % 10.53 % 0.25 s 1 core @ 2.5 Ghz (C/C++)
Y. Chen, H. Dai and Y. Ding: Pseudo-Stereo for Monocular 3D Object Detection in Autonomous Driving. Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR) 2022.
133 CIE 11.94 % 17.90 % 10.34 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
Anonymities: Consistency of Implicit and Explicit Features Matters for Monocular 3D Object Detection. arXiv preprint arXiv:2207.07933 2022.
134 MonoHPE 11.70 % 17.57 % 10.12 % 0.04 s 1 core @ 2.5 Ghz (Python)
135 MonoCtrl_MonoLSS 11.53 % 17.32 % 9.87 % 0.04 s 1 core @ 2.5 Ghz (Python)
136 MonoCoP code 11.40 % 16.99 % 9.63 % 0.01 s 1 core @ 2.5 Ghz (C/C++)
Z. Zhang, A. Kumar, G. Ganesan and X. Liu: Unleashing the Power of Chain-of- Prediction for Monocular 3D Object Detection. Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition 2026.
137 CPD(unsupervised) code 11.09 % 13.48 % 10.19 % 0.1 s GPU @ >3.5 Ghz (Python + C/C++)
H. Wu, S. Zhao, X. Huang, C. Wen, X. Li and C. Wang: Commonsense Prototype for Outdoor Unsupervised 3D Object Detection. CVPR 2024.
138 OPA-3D code 11.01 % 17.14 % 9.94 % 0.04 s 1 core @ 3.5 Ghz (Python)
Y. Su, Y. Di, G. Zhai, F. Manhardt, J. Rambach, B. Busam, D. Stricker and F. Tombari: OPA-3D: Occlusion-Aware Pixel-Wise Aggregation for Monocular 3D Object Detection. IEEE Robotics and Automation Letters 2023.
139 Monodgc-3classes code 10.95 % 17.16 % 9.20 % 0.03 s 1 core @ 2.5 Ghz (C/C++)
C. Guo, L. Guo, W. Lin, Y. Ma, K. Ren and Q. Chen: MonoDGC: Image-Plane Dynamic Graph Cross-Former for Monocular 3D Object Detection. 2026.
140 RARE 10.90 % 16.10 % 9.32 % 0.03 s 1 core @ 2.5 Ghz (Python)
141 MonoUNI code 10.90 % 16.54 % 9.17 % 0.04 s 1 core @ 2.5 Ghz (Python)
J. Jia, Z. Li and Y. Shi: MonoUNI: A Unified Vehicle and Infrastructure-side Monocular 3D Object Detection Network with Sufficient Depth Clues. Thirty-seventh Conference on Neural Information Processing Systems 2023.
142 IDEAL-M3D 10.65 % 16.74 % 8.83 % 0.04 s 1 core @ 2.5 Ghz (Python)
J. Meier, F. Günther, R. Marin, O. Dhaouadi, J. Kaiser and D. Cremers: IDEAL-M3D: Instance Diversity- Enriched Active Learning for Monocular 3D Detection. Proceedings of the IEEE/CVF Winter Conference on Applications of Computer Vision (WACV) 2026.
143 MonoDTR 10.59 % 16.66 % 9.00 % 0.04 s 1 core @ 2.5 Ghz (C/C++)
K. Huang, T. Wu, H. Su and W. Hsu: MonoDTR: Monocular 3D Object Detection with Depth-Aware Transformer. CVPR 2022.
144 MonoFRD 10.38 % 15.68 % 8.79 % 0.01 s 1 core @ 2.5 Ghz (C/C++)
Z. Gong, Y. Zhao, F. Zhang, G. Gui, B. Chen, L. Yu, H. Wang, C. Yang and W. Gui: Color intuitive feature guided depth-height fusion and volume rendering for monocular 3D object detection. IEEE Transactions on Intelligent Vehicles(Major Revison) 2024.
145 GUPNet code 10.37 % 15.62 % 8.79 % NA s 1 core @ 2.5 Ghz (Python + C/C++)
Y. Lu, X. Ma, L. Yang, T. Zhang, Y. Liu, Q. Chu, J. Yan and W. Ouyang: Geometry Uncertainty Projection Network for Monocular 3D Object Detection. arXiv preprint arXiv:2107.13774 2021.
146 CMKD code 10.28 % 16.03 % 8.85 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
Y. Hong, H. Dai and Y. Ding: Cross-Modality Knowledge Distillation Network for Monocular 3D Object Detection. ECCV 2022.
147 DEVIANT code 9.77 % 14.49 % 8.28 % 0.04 s 1 GPU (Python)
A. Kumar, G. Brazil, E. Corona, A. Parchami and X. Liu: DEVIANT: Depth EquiVarIAnt NeTwork for Monocular 3D Object Detection. European Conference on Computer Vision (ECCV) 2022.
148 PS-SVDM 9.75 % 15.03 % 8.37 % 1 s 1 core @ 2.5 Ghz (Python)
Y. Shi: SVDM: Single-View Diffusion Model for Pseudo-Stereo 3D Object Detection. arXiv preprint arXiv:2307.02270 2023.
149 MonoNeRD code 9.66 % 15.27 % 8.28 % na s 1 core @ 2.5 Ghz (Python)
J. Xu, L. Peng, H. Cheng, H. Li, W. Qian, K. Li, W. Wang and D. Cai: MonoNeRD: NeRF-like Representations for Monocular 3D Object Detection. ICCV 2023.
150 CaDDN code 9.41 % 14.72 % 8.17 % 0.63 s GPU @ 2.5 Ghz (Python)
C. Reading, A. Harakeh, J. Chae and S. Waslander: Categorical Depth Distribution Network for Monocular 3D Object Detection. CVPR 2021.
151 SGM3D code 9.39 % 15.39 % 8.61 % 0.03 s 1 core @ 2.5 Ghz (C/C++)
Z. Zhou, L. Du, X. Ye, Z. Zou, X. Tan, L. Zhang, X. Xue and J. Feng: SGM3D: Stereo Guided Monocular 3D Object Detection. RA-L 2022.
152 AMNet+DDAD15M code 9.30 % 14.10 % 8.02 % 0.03 s 1 core @ 2.5 Ghz (C/C++)
H. Pan, Y. Jia, J. Wang and W. Sun: MonoAMNet: Three-Stage Real-Time Monocular 3D Object Detection With Adaptive Methods. IEEE Transactions on Intelligent Transportation Systems 2025.
153 AMNet code 9.30 % 14.02 % 7.93 % 0.03 s GPU @ 1.0 Ghz (Python)
H. Pan, Y. Jia, J. Wang and W. Sun: MonoAMNet: Three-Stage Real-Time Monocular 3D Object Detection With Adaptive Methods. IEEE Transactions on Intelligent Transportation Systems 2025.
154 MonoRCNN++ code 9.04 % 13.45 % 7.74 % 0.07 s GPU @ 2.5 Ghz (Python)
X. Shi, Z. Chen and T. Kim: Multivariate Probabilistic Monocular 3D Object Detection. WACV 2023.
155 MonoPro 8.98 % 12.56 % 7.85 % 0.01 s 1 core @ 2.5 Ghz (Python)
156 HomoLoss(monoflex) code 8.81 % 13.26 % 7.41 % 0.04 s 1 core @ 2.5 Ghz (Python)
J. Gu, B. Wu, L. Fan, J. Huang, S. Cao, Z. Xiang and X. Hua: Homography Loss for Monocular 3D Object Detection. Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR) 2022.
157 MonoDDE 8.41 % 12.38 % 7.16 % 0.04 s 1 core @ 2.5 Ghz (Python)
Z. Li, Z. Qu, Y. Zhou, J. Liu, H. Wang and L. Jiang: Diversity Matters: Fully Exploiting Depth Clues for Reliable Monocular 3D Object Detection. CVPR 2022.
158 Mix-Teaching code 8.40 % 12.34 % 7.06 % 30 s 1 core @ 2.5 Ghz (C/C++)
L. Yang, X. Zhang, L. Wang, M. Zhu, C. Zhang and J. Li: Mix-Teaching: A Simple, Unified and Effective Semi-Supervised Learning Framework for Monocular 3D Object Detection. ArXiv 2022.
159 MDSNet 8.18 % 12.05 % 7.03 % 0.05 s 1 core @ 2.5 Ghz (Python)
Z. Xie, Y. Song, J. Wu, Z. Li, C. Song and Z. Xu: MDS-Net: Multi-Scale Depth Stratification 3D Object Detection from Monocular Images. Sensors 2022.
160 PS-SVDM 8.11 % 12.70 % 6.84 % 1 s 1 core @ 2.5 Ghz (Python)
Y. Shi: SVDM: Single-View Diffusion Model for Pseudo-Stereo 3D Object Detection. arXiv preprint arXiv:2307.02270 2023.
161 LPCG-Monoflex code 7.92 % 12.11 % 6.61 % 0.03 s 1 core @ 2.5 Ghz (C/C++)
L. Peng, F. Liu, Z. Yu, S. Yan, D. Deng, Z. Yang, H. Liu and D. Cai: Lidar Point Cloud Guided Monocular 3D Object Detection. ECCV 2022.
162 RefinedMPL 7.92 % 13.09 % 7.25 % 0.15 s GPU @ 2.5 Ghz (Python + C/C++)
J. Vianney, S. Aich and B. Liu: RefinedMPL: Refined Monocular PseudoLiDAR for 3D Object Detection in Autonomous Driving. arXiv preprint arXiv:1911.09712 2019.
163 Cube R-CNN code 7.65 % 11.67 % 6.60 % 0.05 s GPU @ 2.5 Ghz (Python)
G. Brazil, A. Kumar, J. Straub, N. Ravi, J. Johnson and G. Gkioxari: Omni3D: A Large Benchmark and Model for 3D Object Detection in the Wild. CVPR 2023.
164 MonoRUn code 7.59 % 11.70 % 6.34 % 0.07 s GPU @ 2.5 Ghz (Python + C/C++)
H. Chen, Y. Huang, W. Tian, Z. Gao and L. Xiong: MonoRUn: Monocular 3D Object Detection by Reconstruction and Uncertainty Propagation. IEEE Conference on Computer Vision and Pattern Recognition (CVPR) 2021.
165 MonoFlex 7.36 % 10.36 % 6.29 % 0.03 s GPU @ 2.5 Ghz (Python)
Y. Zhang, J. Lu and J. Zhou: Objects are Different: Flexible Monocular 3D Object Detection. CVPR 2021.
166 DA3D+KM3D+v2-99 code 7.06 % 10.32 % 6.10 % 0.120s GPU @ 2.5 Ghz (Python)
Y. Jia, J. Wang, H. Pan and W. Sun: Enhancing Monocular 3-D Object Detection Through Data Augmentation Strategies. IEEE Transactions on Instrumentation and Measurement 2024.
167 MonoPair 7.04 % 10.99 % 6.29 % 0.06 s GPU @ 2.5 Ghz (Python + C/C++)
Y. Chen, L. Tai, K. Sun and M. Li: MonoPair: Monocular 3D Object Detection Using Pairwise Spatial Relationships. The IEEE Conference on Computer Vision and Pattern Recognition (CVPR) 2020.
168 monodle code 6.96 % 10.73 % 6.20 % 0.04 s GPU @ 2.5 Ghz (Python)
X. Ma, Y. Zhang, D. Xu, D. Zhou, S. Yi, H. Li and W. Ouyang: Delving into Localization Errors for Monocular 3D Object Detection. CVPR 2021 .
169 MonOAPC 6.82 % 9.62 % 5.78 % 0035 s 1 core @ 2.5 Ghz (Python)
H. Yao, J. Chen, Z. Wang, X. Wang, P. Han, X. Chai and Y. Qiu: Occlusion-Aware Plane-Constraints for Monocular 3D Object Detection. IEEE Transactions on Intelligent Transportation Systems 2023.
170 TopNet-DecayRate
This method makes use of Velodyne laser scans.
6.59 % 8.78 % 6.25 % 92 ms NVIDIA GeForce 1080 Ti (tensorflow-gpu)
S. Wirges, T. Fischer, C. Stiller and J. Frias: Object Detection and Classification in Occupancy Grid Maps Using Deep Convolutional Networks. 2018 21st International Conference on Intelligent Transportation Systems (ITSC) 2018.
171 Shift R-CNN (mono) code 5.66 % 8.58 % 4.49 % 0.25 s GPU @ 1.5 Ghz (Python)
A. Naiden, V. Paunescu, G. Kim, B. Jeon and M. Leordeanu: Shift R-CNN: Deep Monocular 3D Object Detection With Closed-form Geometric Constraints. ICIP 2019.
172 FMF-occlusion-net 5.62 % 8.69 % 5.25 % 0.16 s 1 core @ 2.5 Ghz (Python + C/C++)
H. Liu, H. Liu, Y. Wang, F. Sun and W. Huang: Fine-grained Multi-level Fusion for Anti- occlusion Monocular 3D Object Detection. IEEE Transactions on Image Processing 2022.
173 Aug3D-RPN 5.22 % 7.14 % 4.21 % 0.08 s 1 core @ 2.5 Ghz (C/C++)
C. He, J. Huang, X. Hua and L. Zhang: Aug3D-RPN: Improving Monocular 3D Object Detection by Synthetic Images with Virtual Depth. 2021.
174 TopNet-UncEst
This method makes use of Velodyne laser scans.
4.60 % 6.88 % 3.79 % 0.09 s NVIDIA GeForce 1080 Ti (tensorflow-gpu)
S. Wirges, M. Braun, M. Lauer and C. Stiller: Capturing Object Detection Uncertainty in Multi-Layer Grid Maps. 2019.
175 MonoPSR code 4.56 % 7.24 % 4.11 % 0.2 s GPU @ 3.5 Ghz (Python)
J. Ku*, A. Pon* and S. Waslander: Monocular 3D Object Detection Leveraging Accurate Proposals and Shape Reconstruction. CVPR 2019.
176 DFR-Net 4.52 % 6.66 % 3.71 % 0.18 s 1080 Ti (Pytorch)
Z. Zou, X. Ye, L. Du, X. Cheng, X. Tan, L. Zhang, J. Feng, X. Xue and E. Ding: The devil is in the task: Exploiting reciprocal appearance-localization features for monocular 3d object detection . ICCV 2021.
177 QD-3DT
This is an online method (no batch processing).
code 4.23 % 6.62 % 3.39 % 0.03 s GPU @ 2.5 Ghz (Python)
H. Hu, Y. Yang, T. Fischer, F. Yu, T. Darrell and M. Sun: Monocular Quasi-Dense 3D Object Tracking. ArXiv:2103.07351 2021.
178 DA3D+KM3D code 4.05 % 5.94 % 3.55 % 0.02 s GPU @ 2.5 Ghz (Python)
Y. Jia, J. Wang, H. Pan and W. Sun: Enhancing Monocular 3-D Object Detection Through Data Augmentation Strategies. IEEE Transactions on Instrumentation and Measurement 2024.
179 M3D-RPN code 4.05 % 5.65 % 3.29 % 0.16 s GPU @ 1.5 Ghz (Python)
G. Brazil and X. Liu: M3D-RPN: Monocular 3D Region Proposal Network for Object Detection . ICCV 2019 .
180 DDMP-3D 4.02 % 5.53 % 3.36 % 0.18 s 1 core @ 2.5 Ghz (Python)
L. Wang, L. Du, X. Ye, Y. Fu, G. Guo, X. Xue, J. Feng and L. Zhang: Depth-conditioned Dynamic Message Propagation for Monocular 3D Object Detection. CVPR 2020.
181 CMAN 3.96 % 5.24 % 3.18 % 0.15 s 1 core @ 2.5 Ghz (Python)
C. Yuanzhouhan Cao: CMAN: Leaning Global Structure Correlation for Monocular 3D Object Detection. IEEE Trans. Intell. Transport. Syst. 2022.
182 D4LCN code 3.86 % 5.06 % 3.59 % 0.2 s GPU @ 2.5 Ghz (Python + C/C++)
M. Ding, Y. Huo, H. Yi, Z. Wang, J. Shi, Z. Lu and P. Luo: Learning Depth-Guided Convolutions for Monocular 3D Object Detection. CVPR 2020.
183 RT3DStereo
This method uses stereo information.
3.65 % 4.72 % 3.00 % 0.08 s GPU @ 2.5 Ghz (C/C++)
H. Königshof, N. Salscheider and C. Stiller: Realtime 3D Object Detection for Automated Driving Using Stereo Vision and Semantic Information. Proc. IEEE Intl. Conf. Intelligent Transportation Systems 2019.
184 DA3D code 3.27 % 4.93 % 2.74 % 0.03 s 1 core @ 2.5 Ghz (Python)
Y. Jia, J. Wang, H. Pan and W. Sun: Enhancing Monocular 3-D Object Detection Through Data Augmentation Strategies. IEEE Transactions on Instrumentation and Measurement 2024.
185 MonoEF 3.05 % 4.61 % 2.85 % 0.03 s 1 core @ 2.5 Ghz (Python)
Y. Zhou, Y. He, H. Zhu, C. Wang, H. Li and Q. Jiang: Monocular 3D Object Detection: An Extrinsic Parameter Free Approach. Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR) 2021.
186 MonoLiG code 2.72 % 3.74 % 2.55 % 0.03 s 1 core @ 2.5 Ghz (C/C++)
A. Hekimoglu, M. Schmidt and A. Ramiro: Monocular 3D Object Detection with LiDAR Guided Semi Supervised Active Learning. 2023.
187 SS3D 2.09 % 2.48 % 1.61 % 48 ms Tesla V100 (Python)
E. Jörgensen, C. Zach and F. Kahl: Monocular 3D Object Detection and Box Fitting Trained End-to-End Using Intersection-over-Union Loss. CoRR 2019.
188 SparVox3D 2.05 % 2.90 % 1.69 % 0.05 s GPU @ 2.0 Ghz (Python)
E. Balatkan and F. Kıraç: Improving Regression Performance on Monocular 3D Object Detection Using Bin-Mixing and Sparse Voxel Data. 2021 6th International Conference on Computer Science and Engineering (UBMK) 2021.
189 PGD-FCOS3D code 1.88 % 2.82 % 1.54 % 0.03 s 1 core @ 2.5 Ghz (C/C++)
T. Wang, X. Zhu, J. Pang and D. Lin: Probabilistic and Geometric Depth: Detecting Objects in Perspective. Conference on Robot Learning (CoRL) 2021.
190 Plane-Constraints code 1.16 % 1.87 % 1.13 % 0.05 s 4 cores @ 3.0 Ghz (Python)
H. Yao, J. Chen, Z. Wang, X. Wang, X. Chai, Y. Qiu and P. Han: Vertex points are not enough: Monocular 3D object detection via intra-and inter-plane constraints. Neural Networks 2023.
191 mBoW
This method makes use of Velodyne laser scans.
0.00 % 0.00 % 0.00 % 10 s 1 core @ 2.5 Ghz (C/C++)
J. Behley, V. Steinhage and A. Cremers: Laser-based Segment Classification Using a Mixture of Bag-of-Words. Proc. of the IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2013.
192 tmp 0.00 % 0.00 % 0.00 % 0.05 s 1 core @ 2.5 Ghz (C/C++)
Table as LaTeX | Only published Methods

Cyclist


Method Setting Code Moderate Easy Hard Runtime Environment
1 ImagePG code 78.92 % 89.97 % 71.71 % 1 s 1 core @ 2.5 Ghz (C/C++)
M. Lee, S. Moon, S. Lee, R. Mahjourian and J. Kim: Image-Guided Semantic Pseudo- LiDAR Point Generation for 3D Object Detection. Proceedings of the IEEE/CVF Winter Conference on Applications of Computer Vision (WACV) 2026.
2 UPIDet code 78.19 % 89.65 % 71.13 % 0.11 s 1 core @ 2.5 Ghz (C/C++)
Y. Zhang, Q. Zhang, J. Hou, Y. Yuan and G. Xing: Unleash the Potential of Image Branch for Cross-modal 3D Object Detection. Thirty-seventh Conference on Neural Information Processing Systems 2023.
3 CasA++ code 76.99 % 88.93 % 70.10 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
H. Wu, J. Deng, C. Wen, X. Li and C. Wang: CasA: A Cascade Attention Network for 3D Object Detection from LiDAR point clouds. IEEE Transactions on Geoscience and Remote Sensing 2022.
4 TED code 76.95 % 89.54 % 70.31 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
H. Wu, C. Wen, W. Li, R. Yang and C. Wang: Transformation-Equivariant 3D Object Detection for Autonomous Driving. AAAI 2023.
5 WinMamba code 76.92 % 88.86 % 69.85 % 0.1 s 1 core @ 2.5 Ghz (Python)
6 CasA code 75.74 % 88.99 % 68.47 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
H. Wu, J. Deng, C. Wen, X. Li and C. Wang: CasA: A Cascade Attention Network for 3D Object Detection from LiDAR point clouds. IEEE Transactions on Geoscience and Remote Sensing 2022.
7 LoGoNet code 74.92 % 85.85 % 67.62 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
X. Li, T. Ma, Y. Hou, B. Shi, Y. Yang, Y. Liu, X. Wu, Q. Chen, Y. Li, Y. Qiao and others: LoGoNet: Towards Accurate 3D Object Detection with Local-to-Global Cross-Modal Fusion. CVPR 2023.
8 MLF-DET 74.88 % 86.20 % 66.75 % 0.09 s 1 core @ 2.5 Ghz (C/C++)
Z. Lin, Y. Shen, S. Zhou, S. Chen and N. Zheng: MLF-DET: Multi-Level Fusion for Cross- Modal 3D Object Detection. International Conference on Artificial Neural Networks 2023.
9 USVLab BSAODet code 74.38 % 85.01 % 67.38 % 0.04 s 1 core @ 2.5 Ghz (C/C++)
W. Xiao, Y. Peng, C. Liu, J. Gao, Y. Wu and X. Li: Balanced Sample Assignment and Objective for Single-Model Multi-Class 3D Object Detection. IEEE Transactions on Circuits and Systems for Video Technology 2023.
10 HMFI code 74.06 % 85.69 % 67.11 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
X. Li, B. Shi, Y. Hou, X. Wu, T. Ma, Y. Li and L. He: Homogeneous Multi-modal Feature Fusion and Interaction for 3D Object Detection. ECCV 2022.
11 auto_test 73.91 % 86.21 % 65.29 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
12 EQ-PVRCNN code 73.30 % 86.25 % 65.49 % 0.2 s GPU @ 2.5 Ghz (Python + C/C++)
Z. Yang, L. Jiang, Y. Sun, B. Schiele and J. Jia: A Unified Query-based Paradigm for Point Cloud Understanding. Proceedings of the IEEE Conference on Computer Vision and Pattern Recognition 2022.
13 kfc 72.69 % 84.61 % 64.18 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
14 DSA-PV-RCNN
This method makes use of Velodyne laser scans.
code 72.61 % 83.93 % 65.82 % 0.08 s 1 core @ 2.5 Ghz (Python + C/C++)
P. Bhattacharyya, C. Huang and K. Czarnecki: SA-Det3D: Self-Attention Based Context-Aware 3D Object Detection. 2021.
15 CAT-Det 72.51 % 85.35 % 65.55 % 0.3 s GPU @ 2.5 Ghz (Python + C/C++)
Y. Zhang, J. Chen and D. Huang: CAT-Det: Contrastively Augmented Transformer for Multi-modal 3D Object Detection. CVPR 2022.
16 BtcDet
This method makes use of Velodyne laser scans.
code 71.76 % 84.48 % 64.70 % 0.09 s GPU @ 2.5 Ghz (Python + C/C++)
Q. Xu, Y. Zhong and U. Neumann: Behind the Curtain: Learning Occluded Shapes for 3D Object Detection. Proceedings of the AAAI Conference on Artificial Intelligence 2022.
17 HC-MVMM 71.68 % 84.04 % 66.19 % 0.06 s 1 core @ 2.5 Ghz (Python)
18 ACFNet 71.68 % 85.76 % 65.33 % 0.11 s 1 core @ 2.5 Ghz (C/C++)
Y. Tian, X. Zhang, X. Wang, J. Xu, J. Wang, R. Ai, W. Gu and W. Ding: ACF-Net: Asymmetric Cascade Fusion for 3D Detection With LiDAR Point Clouds and Images. IEEE Transactions on Intelligent Vehicles 2023.
19 RagNet3D code 71.64 % 85.10 % 65.02 % 0.05 s 1 core @ 2.5 Ghz (C/C++)
J. Chen, Y. Han, Z. Yan, J. Qian, J. Li and J. Yang: Ragnet3d: Learning Distinguishable Representation for Pooled Grids in 3d Object Detection. Available at SSRN 4979473 .
20 PointPainting
This method makes use of Velodyne laser scans.
71.54 % 83.91 % 62.97 % 0.4 s GPU @ 2.5 Ghz (Python + C/C++)
S. Vora, A. Lang, B. Helou and O. Beijbom: PointPainting: Sequential Fusion for 3D Object Detection. CVPR 2020.
21 PASS-PV-RCNN-Plus 71.51 % 83.03 % 63.85 % 1 s 1 core @ 2.5 Ghz (Python)
Anonymous: Leveraging Anchor-based LiDAR 3D Object Detection via Point Assisted Sample Selection. will submit to computer vision conference/journal 2024.
22 RangeIoUDet
This method makes use of Velodyne laser scans.
71.49 % 85.99 % 63.62 % 0.02 s GPU @ 2.5 Ghz (Python + C/C++)
Z. Liang, Z. Zhang, M. Zhang, X. Zhao and S. Pu: RangeIoUDet: Range Image Based Real-Time 3D Object Detector Optimized by Intersection Over Union. CVPR 2021.
23 ACDet code 71.48 % 87.76 % 64.69 % 0.05 s 1 core @ 2.5 Ghz (C/C++)
J. Xu, G. Wang, X. Zhang and G. Wan: ACDet: Attentive Cross-view Fusion for LiDAR-based 3D Object Detection. 3DV 2022.
24 IA-SSD (single) code 71.44 % 85.91 % 63.41 % 0.013 s 1 core @ 2.5 Ghz (C/C++)
Y. Zhang, Q. Hu, G. Xu, Y. Ma, J. Wan and Y. Guo: Not All Points Are Equal: Learning Highly Efficient Point-based Detectors for 3D LiDAR Point Clouds. CVPR 2022.
25 PDV code 71.31 % 85.54 % 64.40 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
J. Hu, T. Kuai and S. Waslander: Point Density-Aware Voxels for LiDAR 3D Object Detection. CVPR 2022.
26 3ONet 71.29 % 85.17 % 62.99 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
H. Hoang and M. Yoo: 3ONet: 3-D Detector for Occluded Object Under Obstructed Conditions. IEEE Sensors Journal 2023.
27 DFAF3D 71.27 % 85.75 % 64.25 % 0.05 s 1 core @ 2.5 Ghz (Python)
Q. Tang, X. Bai, J. Guo, B. Pan and W. Jiang: DFAF3D: A dual-feature-aware anchor-free single-stage 3D detector for point clouds. Image and Vision Computing 2023.
28 HVNet 71.17 % 83.97 % 63.65 % 0.03 s GPU @ 2.0 Ghz (Python)
M. Ye, S. Xu and T. Cao: HVNet: Hybrid Voxel Network for LiDAR Based 3D Object Detection. CVPR 2020.
29 M3DeTR code 70.89 % 85.03 % 63.14 % n/a s GPU @ 1.0 Ghz (Python)
T. Guan, J. Wang, S. Lan, R. Chandra, Z. Wu, L. Davis and D. Manocha: M3DeTR: Multi-representation, Multi- scale, Mutual-relation 3D Object Detection with Transformers. 2021.
30 PG-RCNN code 70.65 % 84.94 % 64.03 % 0.06 s GPU @ 1.5 Ghz (Python)
I. Koo, I. Lee, S. Kim, H. Kim, W. Jeon and C. Kim: PG-RCNN: Semantic Surface Point Generation for 3D Object Detection. 2023.
31 SparseFormer code 70.50 % 83.65 % 63.24 % 0.06 s 1 core @ 2.5 Ghz (C/C++)
ERROR: Wrong syntax in BIBTEX file.
32 DPFusion code 70.26 % 83.57 % 62.01 % 0.07 s 1 core @ 2.5 Ghz (C/C++)
Y. Mo, Y. Wu, J. Zhao, Y. Hu, J. Wang and J. Yan: Enhancing LiDAR Point Features with Foundation Model Priors for 3D Object Detection. ITSC 2025.
33 SPG_mini
This method makes use of Velodyne laser scans.
code 70.09 % 82.66 % 63.61 % 0.09 s GPU @ 2.5 Ghz (Python)
Q. Xu, Y. Zhou, W. Wang, C. Qi and D. Anguelov: SPG: Unsupervised Domain Adaptation for 3D Object Detection via Semantic Point Generation. Proceedings of the IEEE conference on computer vision and pattern recognition (ICCV) 2021.
34 GraphAlign(ICCV2023) code 69.43 % 80.71 % 63.57 % 0.03 s GPU @ 2.0 Ghz (Python)
Z. Song, H. Wei, L. Bai, L. Yang and C. Jia: GraphAlign: Enhancing accurate feature alignment by graph matching for multi-modal 3D object detection. Proceedings of the IEEE/CVF International Conference on Computer Vision 2023.
35 MoAd code 69.29 % 81.71 % 62.66 % 0.01 s 1 core @ 2.5 Ghz (C/C++)
36 MMLab PV-RCNN
This method makes use of Velodyne laser scans.
code 68.89 % 82.49 % 62.41 % 0.08 s 1 core @ 2.5 Ghz (Python + C/C++)
S. Shi, C. Guo, L. Jiang, Z. Wang, J. Shi, X. Wang and H. Li: PV-RCNN: Point-Voxel Feature Set Abstraction for 3D Object Detection. CVPR 2020.
37 F-ConvNet
This method makes use of Velodyne laser scans.
code 68.88 % 84.16 % 60.05 % 0.47 s GPU @ 2.5 Ghz (Python + C/C++)
Z. Wang and K. Jia: Frustum ConvNet: Sliding Frustums to Aggregate Local Point-Wise Features for Amodal 3D Object Detection. IROS 2019.
38 MMLab-PartA^2
This method makes use of Velodyne laser scans.
code 68.73 % 83.43 % 61.85 % 0.08 s GPU @ 2.5 Ghz (Python + C/C++)
S. Shi, Z. Wang, J. Shi, X. Wang and H. Li: From Points to Parts: 3D Object Detection from Point Cloud with Part-aware and Part-aggregation Network. IEEE Transactions on Pattern Analysis and Machine Intelligence 2020.
39 HotSpotNet 68.51 % 83.29 % 61.84 % 0.04 s 1 core @ 2.5 Ghz (Python + C/C++)
Q. Chen, L. Sun, Z. Wang, K. Jia and A. Yuille: object as hotspots. Proceedings of the European Conference on Computer Vision (ECCV) 2020.
40 LumiNet 68.42 % 85.56 % 61.65 % 0.1 s 1 core @ 2.5 Ghz (Python)
41 fsh_l_1_4 68.34 % 84.83 % 60.58 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
42 P2V-RCNN 68.06 % 81.09 % 60.73 % 0.1 s 2 cores @ 2.5 Ghz (Python)
J. Li, S. Luo, Z. Zhu, H. Dai, A. Krylov, Y. Ding and L. Shao: P2V-RCNN: Point to Voxel Feature Learning for 3D Object Detection from Point Clouds. IEEE Access 2021.
43 fshe_voxeln_1 67.93 % 82.61 % 60.78 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
44 H^23D R-CNN code 67.90 % 82.76 % 60.49 % 0.03 s 1 core @ 2.5 Ghz (C/C++)
J. Deng, W. Zhou, Y. Zhang and H. Li: From Multi-View to Hollow-3D: Hallucinated Hollow-3D R-CNN for 3D Object Detection. IEEE Transactions on Circuits and Systems for Video Technology 2021.
45 VPFNet code 67.66 % 80.83 % 61.36 % 0.2 s 1 core @ 2.5 Ghz (C/C++)
C. Wang, H. Chen and L. Fu: VPFNet: Voxel-Pixel Fusion Network for Multi-class 3D Object Detection. 2021.
C. Wang, H. Chen, Y. Chen, P. Hsiao and L. Fu: VoPiFNet: Voxel-Pixel Fusion Network for Multi-Class 3D Object Detection. IEEE Transactions on Intelligent Transportation Systems 2024.
46 3DSSD code 67.62 % 85.04 % 61.14 % 0.04 s GPU @ 2.5 Ghz (Python + C/C++)
Z. Yang, Y. Sun, S. Liu and J. Jia: 3DSSD: Point-based 3D Single Stage Object Detector. CVPR 2020.
47 Fast-CLOCs 67.55 % 83.34 % 59.61 % 0.1 s GPU @ 2.5 Ghz (Python)
S. Pang, D. Morris and H. Radha: Fast-CLOCs: Fast Camera-LiDAR Object Candidates Fusion for 3D Object Detection. Proceedings of the IEEE/CVF Winter Conference on Applications of Computer Vision (WACV) 2022.
48 DVFENet 67.40 % 82.29 % 60.71 % 0.05 s 1 core @ 2.5 Ghz (Python + C/C++)
Y. He, G. Xia, Y. Luo, L. Su, Z. Zhang, W. Li and P. Wang: DVFENet: Dual-branch Voxel Feature Extraction Network for 3D Object Detection. Neurocomputing 2021.
49 FromVoxelToPoint code 67.36 % 82.68 % 59.15 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
J. Li, H. Dai, L. Shao and Y. Ding: From Voxel to Point: IoU-guided 3D Object Detection for Point Cloud with Voxel-to- Point Decoder. MM '21: The 29th ACM International Conference on Multimedia (ACM MM) 2021.
50 Point-GNN
This method makes use of Velodyne laser scans.
code 67.28 % 81.17 % 59.67 % 0.6 s GPU @ 2.5 Ghz (Python)
W. Shi and R. Rajkumar: Point-GNN: Graph Neural Network for 3D Object Detection in a Point Cloud. CVPR 2020.
51 HINTED code 67.27 % 81.53 % 60.88 % 0.04 s 1 core @ 2.5 Ghz (C/C++)
Q. Xia, W. Ye, H. Wu, S. Zhao, L. Xing, X. Huang, J. Deng, X. Li, C. Wen and C. Wang: HINTED: Hard Instance Enhanced Detector with Mixed-Density Feature Fusion for Sparsely- Supervised 3D Object Detection. Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition 2024.
52 MMLab-PointRCNN
This method makes use of Velodyne laser scans.
code 67.24 % 82.56 % 60.28 % 0.1 s GPU @ 2.5 Ghz (Python + C/C++)
S. Shi, X. Wang and H. Li: Pointrcnn: 3d object proposal generation and detection from point cloud. Proceedings of the IEEE Conference on Computer Vision and Pattern Recognition 2019.
53 STD code 67.23 % 81.36 % 59.35 % 0.08 s GPU @ 2.5 Ghz (Python + C/C++)
Z. Yang, Y. Sun, S. Liu, X. Shen and J. Jia: STD: Sparse-to-Dense 3D Object Detector for Point Cloud. ICCV 2019.
54 SVGA-Net 66.82 % 81.25 % 59.37 % 0.03s 1 core @ 2.5 Ghz (Python + C/C++)
Q. He, Z. Wang, H. Zeng, Y. Zeng and Y. Liu: SVGA-Net: Sparse Voxel-Graph Attention Network for 3D Object Detection from Point Clouds. AAAI 2022.
55 S-AT GCN 66.71 % 78.53 % 60.19 % 0.02 s GPU @ 2.0 Ghz (Python)
L. Wang, C. Wang, X. Zhang, T. Lan and J. Li: S-AT GCN: Spatial-Attention Graph Convolution Network based Feature Enhancement for 3D Object Detection. CoRR 2021.
56 ARPNET 66.39 % 82.32 % 58.80 % 0.08 s GPU @ 2.5 Ghz (Python + C/C++)
Y. Ye, C. Zhang and X. Hao: ARPNET: attention region proposal network for 3D object detection. Science China Information Sciences 2019.
57 IA-SSD (multi) code 66.29 % 81.30 % 59.58 % 0.014 s 1 core @ 2.5 Ghz (C/C++)
Y. Zhang, Q. Hu, G. Xu, Y. Ma, J. Wan and Y. Guo: Not All Points Are Equal: Learning Highly Efficient Point-based Detectors for 3D LiDAR Point Clouds. CVPR 2022.
58 MGAF-3DSSD code 66.00 % 83.03 % 57.57 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
J. Li, H. Dai, L. Shao and Y. Ding: Anchor-free 3D Single Stage Detector with Mask-Guided Attention for Point Cloud. MM '21: The 29th ACM International Conference on Multimedia (ACM MM) 2021.
59 AB3DMOT
This method makes use of Velodyne laser scans.
This is an online method (no batch processing).
code 65.85 % 80.00 % 58.69 % 0.0047s 1 core @ 2.5 Ghz (Python)
X. Weng and K. Kitani: A Baseline for 3D Multi-Object Tracking. arXiv:1907.03961 2019.
60 EOTL code 65.76 % 81.44 % 56.47 % TBD s 1 core @ 2.5 Ghz (Python + C/C++)
R. Yang, Z. Yan, T. Yang, Y. Wang and Y. Ruichek: Efficient Online Transfer Learning for Road Participants Detection in Autonomous Driving. IEEE Sensors Journal 2023.
61 AFCAP 65.32 % 78.65 % 57.70 % 0.1 s 1 core @ 2.5 Ghz (Python)
62 fsh_saf_1 65.22 % 81.47 % 58.11 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
63 MSFASA-3DNet 65.12 % 79.61 % 58.84 % 0.03 s GPU @ 2.5 Ghz (Python)
T. Prasanth, R. Padhy and B. Sivaselvan: MSFASA-3DNet: Multi-Scale Feature Aggregation and Spatial Attention for 3D Object Detection. IEEE Transactions on Artificial Intelligence 2026.
64 VPFnet 65.00 % 80.64 % 56.81 % 0.02 s 1 core @ 2.5 Ghz (C/C++)
65 LinkNet3D 64.64 % 79.47 % 57.99 % 0.04 s GPU @ 2.5 Ghz (Python)
T. Prasanth, R. Padhy, B. Sivaselvan and S. Bakshi: LinkNet3D: An efficient end-to-end network for 3D object detection. Computers and Electrical Engineering 2026.
66 saf_u 64.56 % 81.53 % 57.10 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
67 Faraway-Frustum
This method makes use of Velodyne laser scans.
code 64.54 % 79.65 % 57.84 % 0.1 s GPU @ 2.5 Ghz (Python)
H. Zhang, D. Yang, E. Yurtsever, K. Redmill and U. Ozguner: Faraway-frustum: Dealing with lidar sparsity for 3D object detection using fusion. 2021 IEEE International Intelligent Transportation Systems Conference (ITSC) 2021.
68 SRDL 64.52 % 79.64 % 57.90 % 0.05 s 1 core @ 2.5 Ghz (Python + C/C++)
ERROR: Wrong syntax in BIBTEX file.
69 IFOD 64.36 % 78.14 % 56.99 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
70 PCNet3D++ 64.20 % 80.19 % 57.09 % 0.05 s GPU @ 2.5 Ghz (Python)
T. Prasanth, R. Padhy and B. Sivaselvan: PCNet3D++: A pillar-based cascaded 3D object detection model with an enhanced 2D backbone. Image and Vision Computing 2025.
71 SIF 64.13 % 79.32 % 57.38 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
P. An: SIF. Submitted to CVIU 2021.
72 DSFNet 63.85 % 76.70 % 56.67 % 0.03 s GPU @ 2.5 Ghz (Python)
T. Prasanth, R. Padhy and B. Sivaselvan: LiDAR Sensor-Based Dual-Scale Fusion Approach for Bird’s-Eye View Sensing in Autonomous Vehicles. IEEE Sensors Letters 2025.
73 TANet code 63.77 % 79.16 % 56.21 % 0.035s GPU @ 2.5 Ghz (Python + C/C++)
Z. Liu, X. Zhao, T. Huang, R. Hu, Y. Zhou and X. Bai: TANet: Robust 3D Object Detection from Point Clouds with Triple Attention. AAAI 2020.
74 XView 63.06 % 81.32 % 56.65 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
L. Xie, G. Xu, D. Cai and X. He: X-view: Non-egocentric Multi-View 3D Object Detector. 2021.
75 EPNet++ 62.94 % 78.57 % 56.62 % 0.1 s GPU @ 2.5 Ghz (Python)
Z. Liu, T. Huang, B. Li, X. Chen, X. Wang and X. Bai: EPNet++: Cascade Bi-Directional Fusion for Multi-Modal 3D Object Detection. IEEE Transactions on Pattern Analysis and Machine Intelligence 2022.
76 PointPillars
This method makes use of Velodyne laser scans.
code 62.73 % 79.90 % 55.58 % 16 ms 1080ti GPU and Intel i7 CPU
A. Lang, S. Vora, H. Caesar, L. Zhou, J. Yang and O. Beijbom: PointPillars: Fast Encoders for Object Detection from Point Clouds. CVPR 2019.
77 L-AUG 62.56 % 75.41 % 56.86 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
T. Cortinhal, I. Gouigah and E. Aksoy: Semantics-aware LiDAR-Only Pseudo Point Cloud Generation for 3D Object Detection. 2023.
78 PCNet3D 62.48 % 78.52 % 55.54 % 0.05 s GPU @ 2.5 Ghz (Python)
T. Prasanth, R. Padhy and B. Sivaselvan: PCNet3D: A Pillar Based Cascaded 3D Object Detection Model Using LiDAR Point Cloud. International Conference on Computer Vision and Image Processing 2024.
79 SeSame-point code 61.70 % 75.73 % 55.27 % N/A s TITAN RTX @ 1.35 Ghz (Python)
H. O, C. Yang and K. Huh: SeSame: Simple, Easy 3D Object Detection with Point-Wise Semantics. Proceedings of the Asian Conference on Computer Vision (ACCV) 2024.
80 TriPlane-Lite 61.47 % 72.65 % 56.23 % 0.02 s 1 core @ 2.5 Ghz (C/C++)
Anonymous: Under review. Under review 2026.
81 F-PointNet
This method makes use of Velodyne laser scans.
code 61.37 % 77.26 % 53.78 % 0.17 s GPU @ 3.0 Ghz (Python)
C. Qi, W. Liu, C. Wu, H. Su and L. Guibas: Frustum PointNets for 3D Object Detection from RGB-D Data. arXiv preprint arXiv:1711.08488 2017.
82 LGD 61.21 % 78.01 % 53.99 % 0.03 s 1 core @ 2.5 Ghz (Python)
83 M3DNet 61.04 % 75.48 % 54.48 % 0.5 s 1 core @ 2.5 Ghz (C/C++)
T. Prasanth, R. Padhy and B. Sivaselvan: M3DNet: Minimalist 3D Detection Backbone for Efficient and Accurate 3D Object Detection. Proceedings of the 18th International Conference on Agents and Artificial Intelligence (ICAART) 2026.
84 SeSame-pillar code 60.21 % 72.22 % 53.67 % N/A s TITAN RTX @ 1.35 Ghz (Python)
H. O, C. Yang and K. Huh: SeSame: Simple, Easy 3D Object Detection with Point-Wise Semantics. Proceedings of the Asian Conference on Computer Vision (ACCV) 2024.
85 epBRM
This method makes use of Velodyne laser scans.
code 59.79 % 75.13 % 53.36 % 0.10 s 1 core @ 2.5 Ghz (C/C++)
K. Shin: Improving a Quality of 3D Object Detection by Spatial Transformation Mechanism. arXiv preprint arXiv:1910.04853 2019.
86 BirdNet+
This method makes use of Velodyne laser scans.
code 59.58 % 70.84 % 54.20 % 0.11 s Titan Xp (PyTorch)
A. Barrera, J. Beltrán, C. Guindel, J. Iglesias and F. García: BirdNet+: Two-Stage 3D Object Detection in LiDAR through a Sparsity-Invariant Bird’s Eye View. IEEE Access 2021.
87 SeSame-voxel code 59.36 % 76.95 % 53.14 % N/A s TITAN RTX @ 1.35 Ghz (Python)
H. O, C. Yang and K. Huh: SeSame: Simple, Easy 3D Object Detection with Point-Wise Semantics. Proceedings of the Asian Conference on Computer Vision (ACCV) 2024.
88 LGFE 59.27 % 74.70 % 51.91 % 0.03 s 1 core @ 2.5 Ghz (Python)
89 BASE
This method uses stereo information.
This method makes use of Velodyne laser scans.
59.03 % 77.48 % 52.68 % N/A s GPU @ 2.5 Ghz (Python)
90 DynaMo3D 58.97 % 72.97 % 53.26 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
91 DMF
This method uses stereo information.
57.99 % 71.92 % 51.55 % 0.2 s 1 core @ 2.5 Ghz (Python + C/C++)
X. J. Chen and W. Xu: Disparity-Based Multiscale Fusion Network for Transportation Detection. IEEE Transactions on Intelligent Transportation Systems 2022.
92 PointRGBNet 57.59 % 73.09 % 51.78 % 0.08 s 4 cores @ 2.5 Ghz (Python + C/C++)
P. Xie Desheng: Real-time Detection of 3D Objects Based on Multi-Sensor Information Fusion. Automotive Engineering 2022.
93 AVOD-FPN
This method makes use of Velodyne laser scans.
code 57.12 % 69.39 % 51.09 % 0.1 s Titan X (Pascal)
J. Ku, M. Mozifian, J. Lee, A. Harakeh and S. Waslander: Joint 3D Proposal Generation and Object Detection from View Aggregation. IROS 2018.
94 PiFeNet code 56.94 % 72.80 % 50.04 % 0.03 s 1 core @ 2.5 Ghz (C/C++)
D. Le, H. Shi, H. Rezatofighi and J. Cai: Accurate and Real-time 3D Pedestrian Detection Using an Efficient Attentive Pillar Network. IEEE Robotics and Automation Letters 2022.
95 SCNet
This method makes use of Velodyne laser scans.
56.39 % 73.73 % 49.99 % 0.04 s GPU @ 3.0 Ghz (Python)
Z. Wang, H. Fu, L. Wang, L. Xiao and B. Dai: SCNet: Subdivision Coding Network for Object Detection Based on 3D Point Cloud. IEEE Access 2019.
96 PFF3D
This method makes use of Velodyne laser scans.
code 55.71 % 72.67 % 49.58 % 0.05 s GPU @ 3.0 Ghz (Python + C/C++)
L. Wen and K. Jo: Fast and Accurate 3D Object Detection for Lidar-Camera-Based Autonomous Vehicles Using One Shared Voxel-Based Backbone. IEEE Access 2021.
97 MLOD
This method makes use of Velodyne laser scans.
code 55.06 % 73.03 % 48.21 % 0.12 s GPU @ 1.5 Ghz (Python)
J. Deng and K. Czarnecki: MLOD: A multi-view 3D object detection based on robust feature fusion method. arXiv preprint arXiv:1909.04163 2019.
98 M-VPFnet 55.02 % 71.53 % 48.22 % 0.05 s 1 core @ 2.5 Ghz (Python)
99 Fade 3D code 55.00 % 71.51 % 48.65 % 0.01 s 1 core @ 2.5 Ghz (C/C++)
W. Ye, Q. Xia, H. Wu, Z. Dong, R. Zhong, C. Wang and C. Wen: Fade3D: Fast and Deployable 3D Object Detection for Autonomous Driving. IEEE Transactions on Intelligent Transportation Systems 2025.
100 PL++: PV-RCNN++
This method uses stereo information.
This method makes use of Velodyne laser scans.
53.64 % 67.88 % 46.87 % 0.342 s RTX 4060Ti (Python)
X. Gong, X. Huang, S. Chen and B. Zhang: Enhancing 3D Detection Accuracy in Autonomous Driving through Pseudo-LiDAR Augmentation and Downsampling. 2024 International Conference on Image Processing, Computer Vision and Machine Learning (ICICML) 2024.
101 BirdNet+ (legacy)
This method makes use of Velodyne laser scans.
code 52.15 % 72.45 % 46.57 % 0.1 s Titan Xp (PyTorch)
A. Barrera, C. Guindel, J. Beltrán and F. García: BirdNet+: End-to-End 3D Object Detection in LiDAR Bird’s Eye View. 2020 IEEE 23rd International Conference on Intelligent Transportation Systems (ITSC) 2020.
102 DSGN++
This method uses stereo information.
code 49.37 % 68.29 % 43.79 % 0.2 s GeForce RTX 2080Ti
Y. Chen, S. Huang, S. Liu, B. Yu and J. Jia: DSGN++: Exploiting Visual-Spatial Relation for Stereo-Based 3D Detectors. IEEE Transactions on Pattern Analysis and Machine Intelligence 2022.
103 StereoDistill 48.37 % 69.46 % 42.69 % 0.4 s 1 core @ 2.5 Ghz (Python)
Z. Liu, X. Ye, X. Tan, D. Errui, Y. Zhou and X. Bai: StereoDistill: Pick the Cream from LiDAR for Distilling Stereo-based 3D Object Detection. Proceedings of the AAAI Conference on Artificial Intelligence 2023.
104 AVOD
This method makes use of Velodyne laser scans.
code 48.15 % 64.11 % 42.37 % 0.08 s Titan X (pascal)
J. Ku, M. Mozifian, J. Lee, A. Harakeh and S. Waslander: Joint 3D Proposal Generation and Object Detection from View Aggregation. IROS 2018.
105 SeSame-voxel w/score code 45.61 % 58.94 % 40.68 % N/A s GPU @ 1.5 Ghz (Python)
H. O, C. Yang and K. Huh: SeSame: Simple, Easy 3D Object Detection with Point-Wise Semantics. Proceedings of the Asian Conference on Computer Vision (ACCV) 2024.
106 MSVN
This method uses stereo information.
41.59 % 62.39 % 36.65 % 0.15 s 1 core @ 2.5 Ghz (Python)
107 BirdNet
This method makes use of Velodyne laser scans.
41.56 % 58.64 % 36.94 % 0.11 s Titan Xp (Caffe)
J. Beltrán, C. Guindel, F. Moreno, D. Cruzado, F. García and A. Escalera: BirdNet: A 3D Object Detection Framework from LiDAR Information. 2018 21st International Conference on Intelligent Transportation Systems (ITSC) 2018.
108 SparsePool code 40.74 % 56.52 % 36.68 % 0.13 s 8 cores @ 2.5 Ghz (Python)
Z. Wang, W. Zhan and M. Tomizuka: Fusing bird view lidar point cloud and front view camera image for deep object detection. arXiv preprint arXiv:1711.06703 2017.
109 MMLAB LIGA-Stereo
This method uses stereo information.
code 40.60 % 58.95 % 35.27 % 0.4 s 1 core @ 2.5 Ghz (Python + C/C++)
X. Guo, S. Shi, X. Wang and H. Li: LIGA-Stereo: Learning LiDAR Geometry Aware Representations for Stereo-based 3D Detector. Proceedings of the IEEE/CVF International Conference on Computer Vision (ICCV) 2021.
110 TopNet-Retina
This method makes use of Velodyne laser scans.
36.83 % 47.48 % 33.58 % 52ms GeForce 1080Ti (tensorflow-gpu, v1.12)
S. Wirges, T. Fischer, C. Stiller and J. Frias: Object Detection and Classification in Occupancy Grid Maps Using Deep Convolutional Networks. 2018 21st International Conference on Intelligent Transportation Systems (ITSC) 2018.
111 CG-Stereo
This method uses stereo information.
36.25 % 55.33 % 32.17 % 0.57 s GeForce RTX 2080 Ti
C. Li, J. Ku and S. Waslander: Confidence Guided Stereo 3D Object Detection with Split Depth Estimation. IROS 2020.
112 SparsePool code 35.24 % 43.55 % 30.15 % 0.13 s 8 cores @ 2.5 Ghz (Python)
Z. Wang, W. Zhan and M. Tomizuka: Fusing bird view lidar point cloud and front view camera image for deep object detection. arXiv preprint arXiv:1711.06703 2017.
113 EpiStereo 28.11 % 43.96 % 24.54 % 1 s 1 core @ 2.5 Ghz (C/C++)
114 Disp R-CNN (velo)
This method uses stereo information.
code 27.04 % 44.19 % 23.58 % 0.387 s GPU @ 2.5 Ghz (Python + C/C++)
J. Sun, L. Chen, Y. Xie, S. Zhang, Q. Jiang, X. Zhou and H. Bao: Disp R-CNN: Stereo 3D Object Detection via Shape Prior Guided Instance Disparity Estimation. CVPR 2020.
115 Disp R-CNN
This method uses stereo information.
code 27.04 % 44.19 % 23.58 % 0.387 s GPU @ 2.5 Ghz (Python + C/C++)
J. Sun, L. Chen, Y. Xie, S. Zhang, Q. Jiang, X. Zhou and H. Bao: Disp R-CNN: Stereo 3D Object Detection via Shape Prior Guided Instance Disparity Estimation. CVPR 2020.
116 StereoDETR
This method uses stereo information.
code 26.78 % 42.19 % 22.74 % 0.02 s GPU @ 2.5 Ghz (Python)
S. Mu, Z. Gu, Z. Ai, A. Liu, Y. Gao and S. Xu: StereoDETR: Stereo-Based Transformer for 3D Object Detection. IEEE Transactions on Circuits and Systems for Video Technology 2026.
117 Complexer-YOLO
This method makes use of Velodyne laser scans.
25.43 % 32.00 % 22.88 % 0.06 s GPU @ 3.5 Ghz (C/C++)
M. Simon, K. Amende, A. Kraus, J. Honer, T. Samann, H. Kaulbersch, S. Milz and H. Michael Gross: Complexer-YOLO: Real-Time 3D Object Detection and Tracking on Semantic Point Clouds. The IEEE Conference on Computer Vision and Pattern Recognition (CVPR) Workshops 2019.
118 DDStereo code 24.36 % 37.95 % 20.87 % 0.024 s GPU @ 2.5 Ghz (Python)
S. Mu, Z. Gu, Z. Ai, Y. Gao and S. Xu: DDStereo: Efficient Dual Decoder Transformers for Stereo 3D Road Anomaly Detection. European Conference on Computer Vision 2026.
119 SG3D 21.25 % 36.57 % 18.61 % 0.07 s 1 core @ 2.5 Ghz (C/C++)
120 DSGN
This method uses stereo information.
code 21.04 % 31.23 % 18.93 % 0.67 s NVIDIA Tesla V100
Y. Chen, S. Liu, X. Shen and J. Jia: DSGN: Deep Stereo Geometry Network for 3D Object Detection. CVPR 2020.
121 SeSame-pillar w/scor code 19.53 % 15.92 % 17.61 % N/A s 1 core @ 2.5 Ghz (C/C++)
H. O, C. Yang and K. Huh: SeSame: Simple, Easy 3D Object Detection with Point-Wise Semantics. Proceedings of the Asian Conference on Computer Vision (ACCV) 2024.
122 OC Stereo
This method uses stereo information.
code 19.23 % 32.47 % 17.11 % 0.35 s 1 core @ 2.5 Ghz (Python + C/C++)
A. Pon, J. Ku, C. Li and S. Waslander: Object-Centric Stereo Matching for 3D Object Detection. ICRA 2020.
123 TopNet-DecayRate
This method makes use of Velodyne laser scans.
16.00 % 23.02 % 13.24 % 92 ms NVIDIA GeForce 1080 Ti (tensorflow-gpu)
S. Wirges, T. Fischer, C. Stiller and J. Frias: Object Detection and Classification in Occupancy Grid Maps Using Deep Convolutional Networks. 2018 21st International Conference on Intelligent Transportation Systems (ITSC) 2018.
124 RT3D-GMP
This method uses stereo information.
13.92 % 20.59 % 12.74 % 0.06 s GPU @ 2.5 Ghz (Python + C/C++)
H. Königshof and C. Stiller: Learning-Based Shape Estimation with Grid Map Patches for Realtime 3D Object Detection for Automated Driving. 2020 IEEE 23rd International Conference on Intelligent Transportation Systems (ITSC) 2020.
125 EfficientStereo-3D 11.99 % 20.23 % 10.68 % 0.06 s 1 core @ 2.5 Ghz (Python)
126 TopNet-UncEst
This method makes use of Velodyne laser scans.
9.18 % 12.31 % 8.14 % 0.09 s NVIDIA GeForce 1080 Ti (tensorflow-gpu)
S. Wirges, M. Braun, M. Lauer and C. Stiller: Capturing Object Detection Uncertainty in Multi-Layer Grid Maps. 2019.
127 ESGN
This method uses stereo information.
9.02 % 15.78 % 7.96 % 0.06 s GPU @ 2.5 Ghz (Python + C/C++)
A. Gao, Y. Pang, J. Nie, Z. Shao, J. Cao, Y. Guo and X. Li: ESGN: Efficient Stereo Geometry Network for Fast 3D Object Detection. IEEE Transactions on Circuits and Systems for Video Technology 2022.
128 SeSame-point w/score code 8.90 % 10.65 % 7.68 % N/A s 1 core @ 1.5 Ghz (Python)
H. O, C. Yang and K. Huh: SeSame: Simple, Easy 3D Object Detection with Point-Wise Semantics. Proceedings of the Asian Conference on Computer Vision (ACCV) 2024.
129 MonoPro 8.61 % 13.16 % 7.97 % 0.01 s 1 core @ 2.5 Ghz (Python)
130 CMKD code 8.15 % 14.66 % 7.23 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
Y. Hong, H. Dai and Y. Ding: Cross-Modality Knowledge Distillation Network for Monocular 3D Object Detection. ECCV 2022.
131 MonOri code 7.86 % 12.34 % 7.05 % 0.03 s 4 cores @ 2.5 Ghz (Python)
H. Yao, P. Han, J. Chen, Z. Wang, Y. Qiu, X. Wang, Y. wang, X. Chai, C. Cao and W. Jin: MonOri: Orientation-Guided PnP for Monocular 3-D Object Detection. IEEE Transactions on Neural Networks and Learning Systems 2025.
132 PS-fld code 7.29 % 12.80 % 6.05 % 0.25 s 1 core @ 2.5 Ghz (C/C++)
Y. Chen, H. Dai and Y. Ding: Pseudo-Stereo for Monocular 3D Object Detection in Autonomous Driving. Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR) 2022.
133 LeAD-M3D code 7.15 % 12.20 % 6.14 % 0.0079 s 1 core @ 2.5 Ghz (Python)
J. Meier, J. Michel, O. Dhaouadi, Y. Yang, C. Reich, Z. Bauer, S. Roth, M. Pollefeys, J. Kaiser and D. Cremers: LeAD-M3D: Leveraging Asymmetric Distillation for Real-Time Monocular 3D Detection. European Conference on Computer Vision (ECCV) 2026.
134 MonoCtrl_MonoLSS 6.77 % 10.88 % 6.12 % 0.04 s 1 core @ 2.5 Ghz (Python)
135 MonoLiG code 6.49 % 9.48 % 5.46 % 0.03 s 1 core @ 2.5 Ghz (C/C++)
A. Hekimoglu, M. Schmidt and A. Ramiro: Monocular 3D Object Detection with LiDAR Guided Semi Supervised Active Learning. 2023.
136 TopNet-HighRes
This method makes use of Velodyne laser scans.
6.48 % 9.99 % 6.76 % 101ms NVIDIA GeForce 1080 Ti (tensorflow-gpu)
S. Wirges, T. Fischer, C. Stiller and J. Frias: Object Detection and Classification in Occupancy Grid Maps Using Deep Convolutional Networks. 2018 21st International Conference on Intelligent Transportation Systems (ITSC) 2018.
137 MonoCoP code 6.27 % 10.61 % 5.25 % 0.01 s 1 core @ 2.5 Ghz (C/C++)
Z. Zhang, A. Kumar, G. Ganesan and X. Liu: Unleashing the Power of Chain-of- Prediction for Monocular 3D Object Detection. Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition 2026.
138 CPD(unsupervised) code 6.27 % 9.11 % 5.34 % 0.1 s GPU @ >3.5 Ghz (Python + C/C++)
H. Wu, S. Zhao, X. Huang, C. Wen, X. Li and C. Wang: Commonsense Prototype for Outdoor Unsupervised 3D Object Detection. CVPR 2024.
139 DA3D+KM3D+v2-99 code 5.82 % 9.73 % 4.88 % 0.120s GPU @ 2.5 Ghz (Python)
Y. Jia, J. Wang, H. Pan and W. Sun: Enhancing Monocular 3-D Object Detection Through Data Augmentation Strategies. IEEE Transactions on Instrumentation and Measurement 2024.
140 MonoPSR code 5.78 % 9.87 % 4.57 % 0.2 s GPU @ 3.5 Ghz (Python)
J. Ku*, A. Pon* and S. Waslander: Monocular 3D Object Detection Leveraging Accurate Proposals and Shape Reconstruction. CVPR 2019.
141 DD3D code 5.69 % 9.20 % 5.20 % n/a s 1 core @ 2.5 Ghz (C/C++)
D. Park, R. Ambrus, V. Guizilini, J. Li and A. Gaidon: Is Pseudo-Lidar needed for Monocular 3D Object detection?. IEEE/CVF International Conference on Computer Vision (ICCV) .
142 RARE 5.56 % 9.75 % 4.37 % 0.03 s 1 core @ 2.5 Ghz (Python)
143 MonoLSS 5.52 % 8.88 % 4.98 % 0.04 s 1 core @ 2.5 Ghz (Python)
Z. Li, J. Jia and Y. Shi: MonoLSS: Learnable Sample Selection For Monocular 3D Detection. International Conference on 3D Vision 2024.
144 IDEAL-M3D 5.39 % 8.85 % 4.87 % 0.04 s 1 core @ 2.5 Ghz (Python)
J. Meier, F. Günther, R. Marin, O. Dhaouadi, J. Kaiser and D. Cremers: IDEAL-M3D: Instance Diversity- Enriched Active Learning for Monocular 3D Detection. Proceedings of the IEEE/CVF Winter Conference on Applications of Computer Vision (WACV) 2026.
145 CaDDN code 5.38 % 9.67 % 4.75 % 0.63 s GPU @ 2.5 Ghz (Python)
C. Reading, A. Harakeh, J. Chae and S. Waslander: Categorical Depth Distribution Network for Monocular 3D Object Detection. CVPR 2021.
146 Mix-Teaching code 5.36 % 8.56 % 4.62 % 30 s 1 core @ 2.5 Ghz (C/C++)
L. Yang, X. Zhang, L. Wang, M. Zhu, C. Zhang and J. Li: Mix-Teaching: A Simple, Unified and Effective Semi-Supervised Learning Framework for Monocular 3D Object Detection. ArXiv 2022.
147 PS-SVDM 5.34 % 9.20 % 4.31 % 1 s 1 core @ 2.5 Ghz (Python)
Y. Shi: SVDM: Single-View Diffusion Model for Pseudo-Stereo 3D Object Detection. arXiv preprint arXiv:2307.02270 2023.
148 Monodgc-3classes code 5.03 % 8.68 % 4.41 % 0.03 s 1 core @ 2.5 Ghz (C/C++)
C. Guo, L. Guo, W. Lin, Y. Ma, K. Ren and Q. Chen: MonoDGC: Image-Plane Dynamic Graph Cross-Former for Monocular 3D Object Detection. 2026.
149 MonoUNI code 5.03 % 8.25 % 4.50 % 0.04 s 1 core @ 2.5 Ghz (Python)
J. Jia, Z. Li and Y. Shi: MonoUNI: A Unified Vehicle and Infrastructure-side Monocular 3D Object Detection Network with Sufficient Depth Clues. Thirty-seventh Conference on Neural Information Processing Systems 2023.
150 LPCG-Monoflex code 4.90 % 8.14 % 3.86 % 0.03 s 1 core @ 2.5 Ghz (C/C++)
L. Peng, F. Liu, Z. Yu, S. Yan, D. Deng, Z. Yang, H. Liu and D. Cai: Lidar Point Cloud Guided Monocular 3D Object Detection. ECCV 2022.
151 MonoHPE 4.82 % 7.58 % 4.78 % 0.04 s 1 core @ 2.5 Ghz (Python)
152 Plane-Constraints code 4.79 % 8.67 % 3.90 % 0.05 s 4 cores @ 3.0 Ghz (Python)
H. Yao, J. Chen, Z. Wang, X. Wang, X. Chai, Y. Qiu and P. Han: Vertex points are not enough: Monocular 3D object detection via intra-and inter-plane constraints. Neural Networks 2023.
153 AMNet code 4.62 % 7.89 % 4.00 % 0.03 s GPU @ 1.0 Ghz (Python)
H. Pan, Y. Jia, J. Wang and W. Sun: MonoAMNet: Three-Stage Real-Time Monocular 3D Object Detection With Adaptive Methods. IEEE Transactions on Intelligent Transportation Systems 2025.
154 MonoFRD 4.55 % 8.44 % 4.14 % 0.01 s 1 core @ 2.5 Ghz (C/C++)
Z. Gong, Y. Zhao, F. Zhang, G. Gui, B. Chen, L. Yu, H. Wang, C. Yang and W. Gui: Color intuitive feature guided depth-height fusion and volume rendering for monocular 3D object detection. IEEE Transactions on Intelligent Vehicles(Major Revison) 2024.
155 MonoDDE 4.36 % 6.68 % 3.76 % 0.04 s 1 core @ 2.5 Ghz (Python)
Z. Li, Z. Qu, Y. Zhou, J. Liu, H. Wang and L. Jiang: Diversity Matters: Fully Exploiting Depth Clues for Reliable Monocular 3D Object Detection. CVPR 2022.
156 MonoDTR 4.11 % 5.84 % 3.48 % 0.04 s 1 core @ 2.5 Ghz (C/C++)
K. Huang, T. Wu, H. Su and W. Hsu: MonoDTR: Monocular 3D Object Detection with Depth-Aware Transformer. CVPR 2022.
157 RT3DStereo
This method uses stereo information.
4.10 % 7.03 % 3.88 % 0.08 s GPU @ 2.5 Ghz (C/C++)
H. Königshof, N. Salscheider and C. Stiller: Realtime 3D Object Detection for Automated Driving Using Stereo Vision and Semantic Information. Proc. IEEE Intl. Conf. Intelligent Transportation Systems 2019.
158 HomoLoss(monoflex) code 4.09 % 6.81 % 3.78 % 0.04 s 1 core @ 2.5 Ghz (Python)
J. Gu, B. Wu, L. Fan, J. Huang, S. Cao, Z. Xiang and X. Hua: Homography Loss for Monocular 3D Object Detection. Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR) 2022.
159 DFR-Net 4.00 % 5.99 % 3.95 % 0.18 s 1080 Ti (Pytorch)
Z. Zou, X. Ye, L. Du, X. Cheng, X. Tan, L. Zhang, J. Feng, X. Xue and E. Ding: The devil is in the task: Exploiting reciprocal appearance-localization features for monocular 3d object detection . ICCV 2021.
160 DEVIANT code 3.97 % 6.42 % 3.51 % 0.04 s 1 GPU (Python)
A. Kumar, G. Brazil, E. Corona, A. Parchami and X. Liu: DEVIANT: Depth EquiVarIAnt NeTwork for Monocular 3D Object Detection. European Conference on Computer Vision (ECCV) 2022.
161 GUPNet code 3.85 % 6.94 % 3.64 % NA s 1 core @ 2.5 Ghz (Python + C/C++)
Y. Lu, X. Ma, L. Yang, T. Zhang, Y. Liu, Q. Chu, J. Yan and W. Ouyang: Geometry Uncertainty Projection Network for Monocular 3D Object Detection. arXiv preprint arXiv:2107.13774 2021.
162 OPA-3D code 3.75 % 6.01 % 3.56 % 0.04 s 1 core @ 3.5 Ghz (Python)
Y. Su, Y. Di, G. Zhai, F. Manhardt, J. Rambach, B. Busam, D. Stricker and F. Tombari: OPA-3D: Occlusion-Aware Pixel-Wise Aggregation for Monocular 3D Object Detection. IEEE Robotics and Automation Letters 2023.
163 CIE 3.74 % 6.13 % 3.18 % 0.1 s 1 core @ 2.5 Ghz (C/C++)
Anonymities: Consistency of Implicit and Explicit Features Matters for Monocular 3D Object Detection. arXiv preprint arXiv:2207.07933 2022.
164 PS-SVDM 3.64 % 6.84 % 3.04 % 1 s 1 core @ 2.5 Ghz (Python)
Y. Shi: SVDM: Single-View Diffusion Model for Pseudo-Stereo 3D Object Detection. arXiv preprint arXiv:2307.02270 2023.
165 SGM3D code 3.63 % 7.05 % 3.33 % 0.03 s 1 core @ 2.5 Ghz (C/C++)
Z. Zhou, L. Du, X. Ye, Z. Zou, X. Tan, L. Zhang, X. Xue and J. Feng: SGM3D: Stereo Guided Monocular 3D Object Detection. RA-L 2022.
166 AMNet+DDAD15M code 3.61 % 5.54 % 3.19 % 0.03 s 1 core @ 2.5 Ghz (C/C++)
H. Pan, Y. Jia, J. Wang and W. Sun: MonoAMNet: Three-Stage Real-Time Monocular 3D Object Detection With Adaptive Methods. IEEE Transactions on Intelligent Transportation Systems 2025.
167 Cube R-CNN code 3.35 % 5.01 % 3.23 % 0.05 s GPU @ 2.5 Ghz (Python)
G. Brazil, A. Kumar, J. Straub, N. Ravi, J. Johnson and G. Gkioxari: Omni3D: A Large Benchmark and Model for 3D Object Detection in the Wild. CVPR 2023.
168 Aug3D-RPN 3.33 % 5.44 % 2.82 % 0.08 s 1 core @ 2.5 Ghz (C/C++)
C. He, J. Huang, X. Hua and L. Zhang: Aug3D-RPN: Improving Monocular 3D Object Detection by Synthetic Images with Virtual Depth. 2021.
169 MonOAPC 3.31 % 6.54 % 3.05 % 0035 s 1 core @ 2.5 Ghz (Python)
H. Yao, J. Chen, Z. Wang, X. Wang, P. Han, X. Chai and Y. Qiu: Occlusion-Aware Plane-Constraints for Monocular 3D Object Detection. IEEE Transactions on Intelligent Transportation Systems 2023.
170 monodle code 3.28 % 5.34 % 2.83 % 0.04 s GPU @ 2.5 Ghz (Python)
X. Ma, Y. Zhang, D. Xu, D. Zhou, S. Yi, H. Li and W. Ouyang: Delving into Localization Errors for Monocular 3D Object Detection. CVPR 2021 .
171 MDSNet 3.22 % 5.99 % 2.62 % 0.05 s 1 core @ 2.5 Ghz (Python)
Z. Xie, Y. Song, J. Wu, Z. Li, C. Song and Z. Xu: MDS-Net: Multi-Scale Depth Stratification 3D Object Detection from Monocular Images. Sensors 2022.
172 DDMP-3D 3.14 % 4.92 % 2.44 % 0.18 s 1 core @ 2.5 Ghz (Python)
L. Wang, L. Du, X. Ye, Y. Fu, G. Guo, X. Xue, J. Feng and L. Zhang: Depth-conditioned Dynamic Message Propagation for Monocular 3D Object Detection. CVPR 2020.
173 QD-3DT
This is an online method (no batch processing).
code 3.02 % 5.71 % 2.73 % 0.03 s GPU @ 2.5 Ghz (Python)
H. Hu, Y. Yang, T. Fischer, F. Yu, T. Darrell and M. Sun: Monocular Quasi-Dense 3D Object Tracking. ArXiv:2103.07351 2021.
174 MonoPair 2.87 % 4.76 % 2.42 % 0.06 s GPU @ 2.5 Ghz (Python + C/C++)
Y. Chen, L. Tai, K. Sun and M. Li: MonoPair: Monocular 3D Object Detection Using Pairwise Spatial Relationships. The IEEE Conference on Computer Vision and Pattern Recognition (CVPR) 2020.
175 MonoNeRD code 2.80 % 5.24 % 2.55 % na s 1 core @ 2.5 Ghz (Python)
J. Xu, L. Peng, H. Cheng, H. Li, W. Qian, K. Li, W. Wang and D. Cai: MonoNeRD: NeRF-like Representations for Monocular 3D Object Detection. ICCV 2023.
176 MonoFlex 2.67 % 4.41 % 2.50 % 0.03 s GPU @ 2.5 Ghz (Python)
Y. Zhang, J. Lu and J. Zhou: Objects are Different: Flexible Monocular 3D Object Detection. CVPR 2021.
177 RefinedMPL 2.42 % 4.23 % 2.14 % 0.15 s GPU @ 2.5 Ghz (Python + C/C++)
J. Vianney, S. Aich and B. Liu: RefinedMPL: Refined Monocular PseudoLiDAR for 3D Object Detection in Autonomous Driving. arXiv preprint arXiv:1911.09712 2019.
178 MonoRCNN++ code 2.31 % 3.50 % 2.01 % 0.07 s GPU @ 2.5 Ghz (Python)
X. Shi, Z. Chen and T. Kim: Multivariate Probabilistic Monocular 3D Object Detection. WACV 2023.
179 SS3D 1.89 % 3.45 % 1.44 % 48 ms Tesla V100 (Python)
E. Jörgensen, C. Zach and F. Kahl: Monocular 3D Object Detection and Box Fitting Trained End-to-End Using Intersection-over-Union Loss. CoRR 2019.
180 DA3D code 1.89 % 3.46 % 1.51 % 0.03 s 1 core @ 2.5 Ghz (Python)
Y. Jia, J. Wang, H. Pan and W. Sun: Enhancing Monocular 3-D Object Detection Through Data Augmentation Strategies. IEEE Transactions on Instrumentation and Measurement 2024.
181 D4LCN code 1.82 % 2.72 % 1.79 % 0.2 s GPU @ 2.5 Ghz (Python + C/C++)
M. Ding, Y. Huo, H. Yi, Z. Wang, J. Shi, Z. Lu and P. Luo: Learning Depth-Guided Convolutions for Monocular 3D Object Detection. CVPR 2020.
182 PGD-FCOS3D code 1.79 % 3.54 % 1.56 % 0.03 s 1 core @ 2.5 Ghz (C/C++)
T. Wang, X. Zhu, J. Pang and D. Lin: Probabilistic and Geometric Depth: Detecting Objects in Perspective. Conference on Robot Learning (CoRL) 2021.
183 FMF-occlusion-net 1.65 % 1.91 % 1.75 % 0.16 s 1 core @ 2.5 Ghz (Python + C/C++)
H. Liu, H. Liu, Y. Wang, F. Sun and W. Huang: Fine-grained Multi-level Fusion for Anti- occlusion Monocular 3D Object Detection. IEEE Transactions on Image Processing 2022.
184 CMAN 1.48 % 1.76 % 1.17 % 0.15 s 1 core @ 2.5 Ghz (Python)
C. Yuanzhouhan Cao: CMAN: Leaning Global Structure Correlation for Monocular 3D Object Detection. IEEE Trans. Intell. Transport. Syst. 2022.
185 DA3D+KM3D code 1.44 % 2.88 % 1.37 % 0.02 s GPU @ 2.5 Ghz (Python)
Y. Jia, J. Wang, H. Pan and W. Sun: Enhancing Monocular 3-D Object Detection Through Data Augmentation Strategies. IEEE Transactions on Instrumentation and Measurement 2024.
186 MonoEF 1.18 % 2.36 % 1.15 % 0.03 s 1 core @ 2.5 Ghz (Python)
Y. Zhou, Y. He, H. Zhu, C. Wang, H. Li and Q. Jiang: Monocular 3D Object Detection: An Extrinsic Parameter Free Approach. Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR) 2021.
187 M3D-RPN code 0.81 % 1.25 % 0.78 % 0.16 s GPU @ 1.5 Ghz (Python)
G. Brazil and X. Liu: M3D-RPN: Monocular 3D Region Proposal Network for Object Detection . ICCV 2019 .
188 MonoRUn code 0.73 % 1.14 % 0.66 % 0.07 s GPU @ 2.5 Ghz (Python + C/C++)
H. Chen, Y. Huang, W. Tian, Z. Gao and L. Xiong: MonoRUn: Monocular 3D Object Detection by Reconstruction and Uncertainty Propagation. IEEE Conference on Computer Vision and Pattern Recognition (CVPR) 2021.
189 Shift R-CNN (mono) code 0.38 % 0.76 % 0.41 % 0.25 s GPU @ 1.5 Ghz (Python)
A. Naiden, V. Paunescu, G. Kim, B. Jeon and M. Leordeanu: Shift R-CNN: Deep Monocular 3D Object Detection With Closed-form Geometric Constraints. ICIP 2019.
190 tmp 0.00 % 0.00 % 0.00 % 0.05 s 1 core @ 2.5 Ghz (C/C++)
191 mBoW
This method makes use of Velodyne laser scans.
0.00 % 0.00 % 0.00 % 10 s 1 core @ 2.5 Ghz (C/C++)
J. Behley, V. Steinhage and A. Cremers: Laser-based Segment Classification Using a Mixture of Bag-of-Words. Proc. of the IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2013.
Table as LaTeX | Only published Methods

Related Datasets

Citation

When using this dataset in your research, we will be happy if you cite us:
@inproceedings{Geiger2012CVPR,
  author = {Andreas Geiger and Philip Lenz and Raquel Urtasun},
  title = {Are we ready for Autonomous Driving? The KITTI Vision Benchmark Suite},
  booktitle = {Conference on Computer Vision and Pattern Recognition (CVPR)},
  year = {2012}
}


eXTReMe Tracker