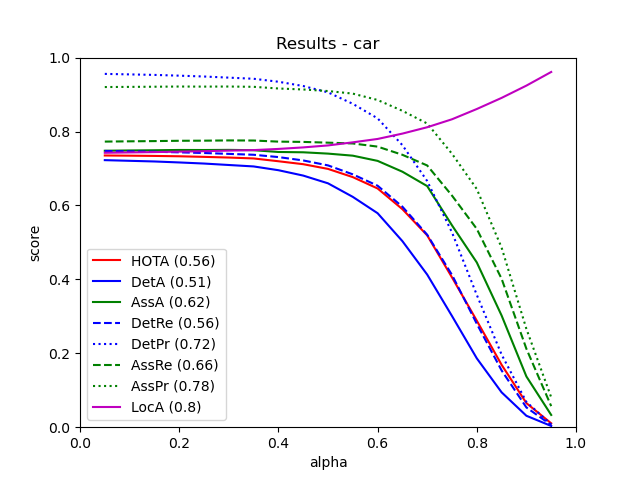
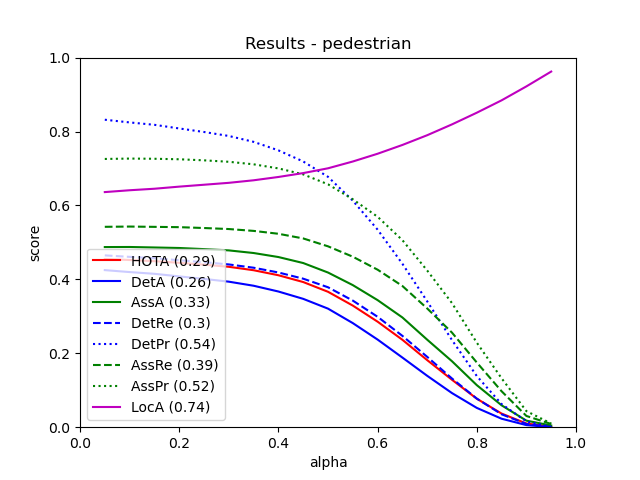
From all 29 test sequences, our benchmark computes the HOTA tracking metrics (HOTA, DetA, AssA, DetRe, DetPr, AssRe, AssPr, LocA) [1] as well as the CLEARMOT, MT/PT/ML, identity switches, and fragmentation [2,3] metrics.
The tables below show all of these metrics.
| Benchmark |
HOTA |
DetA |
AssA |
DetRe |
DetPr |
AssRe |
AssPr |
LocA |
| CAR |
55.92 % |
51.46 % |
61.78 % |
56.43 % |
72.17 % |
66.01 % |
78.27 % |
79.58 % |
| PEDESTRIAN |
29.24 % |
25.79 % |
33.35 % |
29.92 % |
53.53 % |
39.24 % |
52.44 % |
74.08 % |
| Benchmark |
TP |
FP |
FN |
| CAR |
24596 |
9796 |
2295 |
| PEDESTRIAN |
9201 |
13949 |
3737 |
| Benchmark |
MOTA |
MOTP |
MODA |
IDSW |
sMOTA |
| CAR |
63.36 % |
76.11 % |
64.84 % |
509 |
46.28 % |
| PEDESTRIAN |
21.07 % |
69.75 % |
23.60 % |
587 |
9.05 % |
| Benchmark |
MT rate |
PT rate |
ML rate |
FRAG |
| CAR |
42.31 % |
37.08 % |
20.61 % |
540 |
| PEDESTRIAN |
14.43 % |
30.93 % |
54.64 % |
707 |
| Benchmark |
# Dets |
# Tracks |
| CAR |
26891 |
702 |
| PEDESTRIAN |
12938 |
216 |
This table as LaTeX
|
[1] J. Luiten, A. Os̆ep, P. Dendorfer, P. Torr, A. Geiger, L. Leal-Taixé, B. Leibe:
HOTA: A Higher Order Metric for Evaluating Multi-object Tracking. IJCV 2020.
[2] K. Bernardin, R. Stiefelhagen:
Evaluating Multiple Object Tracking Performance: The CLEAR MOT Metrics. JIVP 2008.
[3] Y. Li, C. Huang, R. Nevatia:
Learning to associate: HybridBoosted multi-target tracker for crowded scene. CVPR 2009.