Important note: On September 7, 2026, the KITTI and KITTI-360 servers had to be restored to the backed-up state of August 7, 2026. Results within this period have to be resubmitted.

Method

LiteDynStereo: Efficient Stereo Matching Network with Dynamic Iteration Skipping [ LiteDynStereo]
https://github.com/lingshijiang/LiteDynStereo

Submitted on 9 Nov. 2026 14:35 by
荣桓 鄢 (China Three Gorges University)

Running time:0.62 s
Environment:GPU @ 2.5 Ghz (Python)

Method Description:
LiteDynStereo is a dual-branch stereo matching
method that integrates monocular structural priors
with binocular geometric constraints. It
adaptively skips redundant basic stereo updates
based on disparity convergence, with a stopping
threshold calibrated by disparity variance and
iteration progress. Seven cross-modal refinement
iterations are retained after the basic-update
stage. Reprojection-error-derived confidence
coefficients modulate the geometric conditions
during refinement.
Parameters:
Minimum basic iterations: 10
Maximum basic iterations: 25
Cross-modal refinement iterations: 7
Base convergence threshold: 0.05
Batch size: 1
Framework: Python/PyTorch
Hardware: NVIDIA RTX 3090
Latex Bibtex:
@unpublished{yan2026litedynstereo,
title={{LiteDynStereo}: Efficient Stereo
Matching Network with Dynamic Iteration Skipping},
author={RongHuan Yan and Weixin Tian and Kaggwa
Matthew},
year={2026},
note={Manuscript under review}
}

Detailed Results

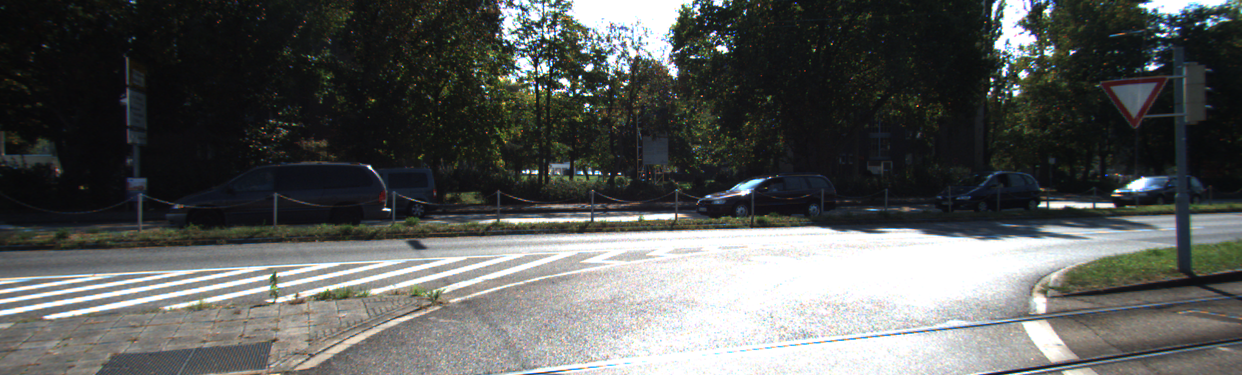
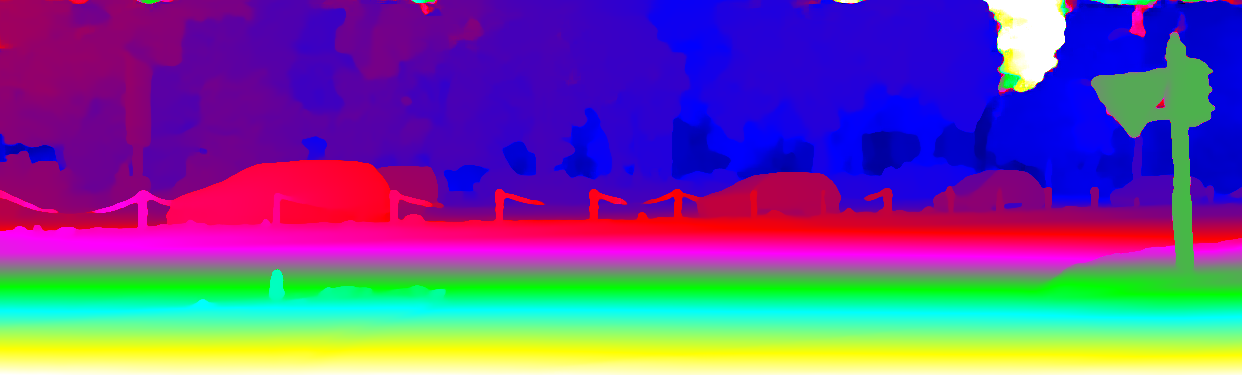
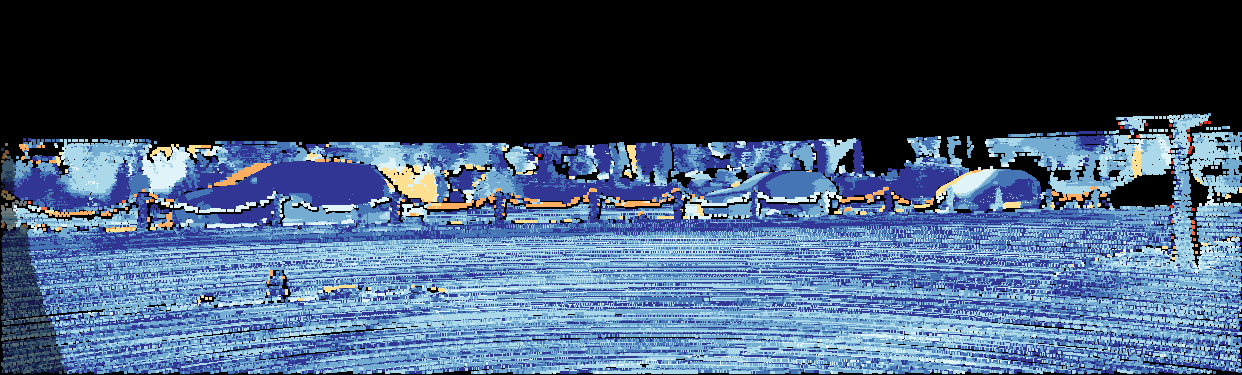
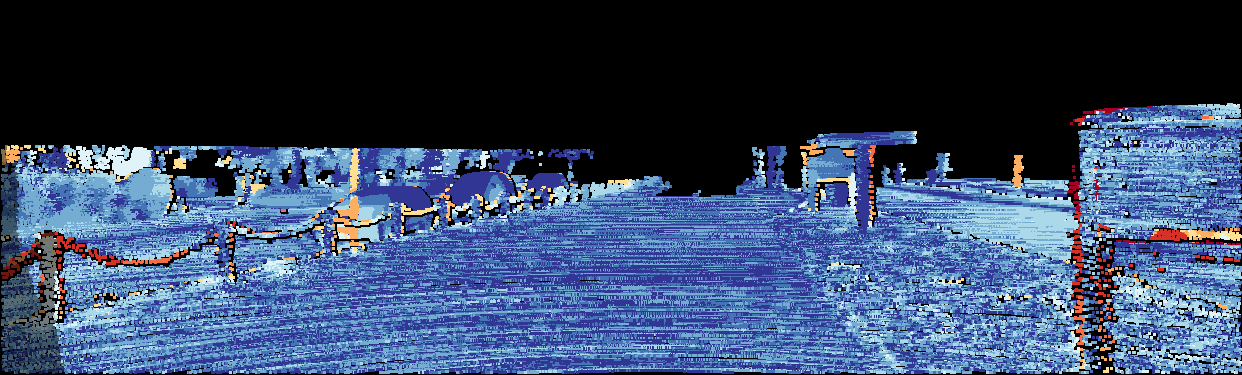
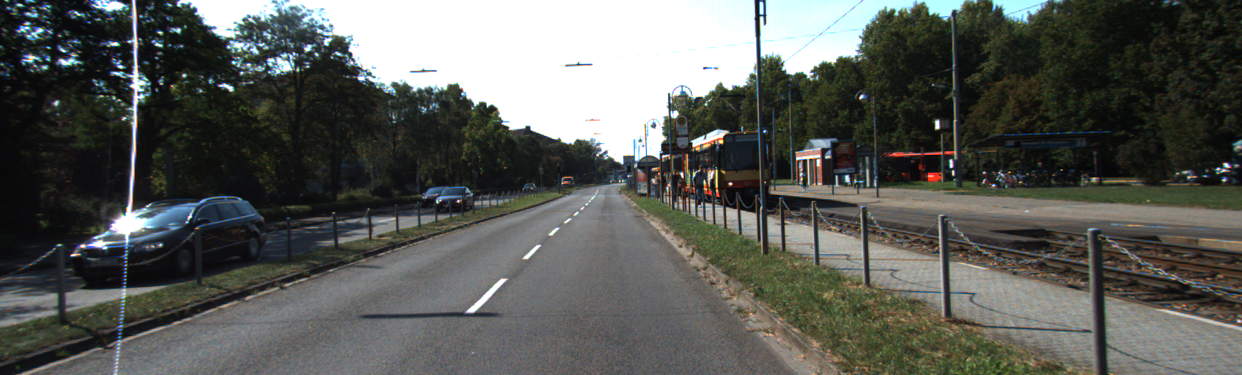
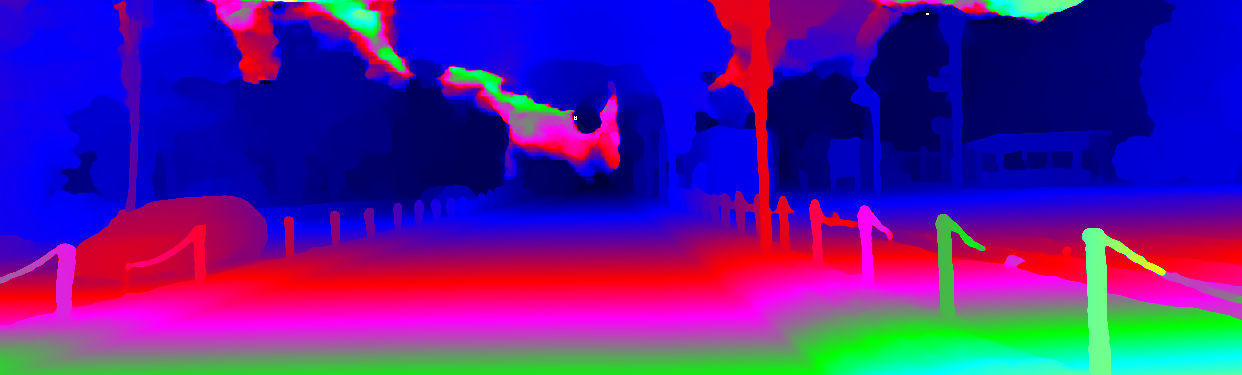
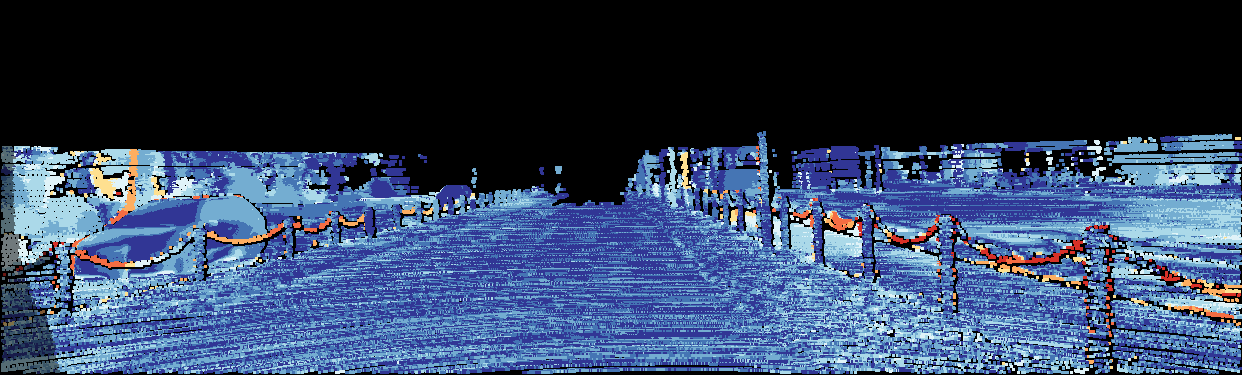
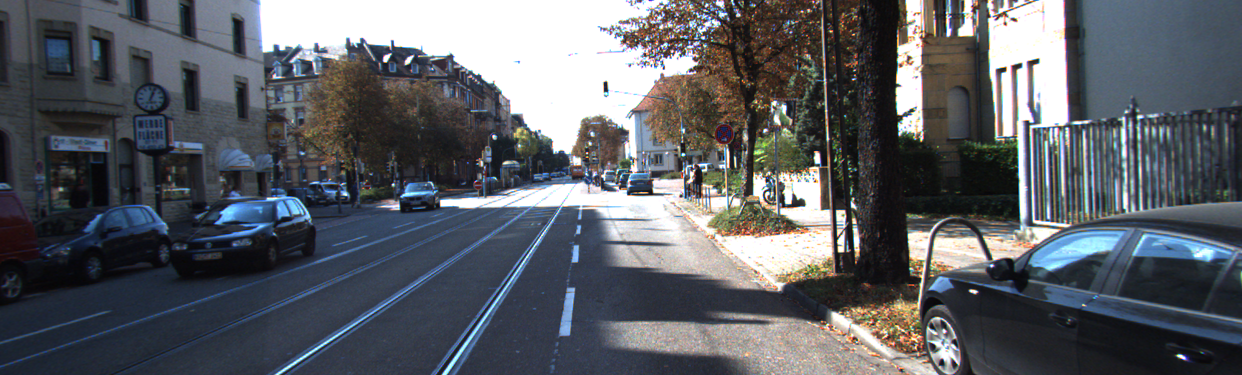
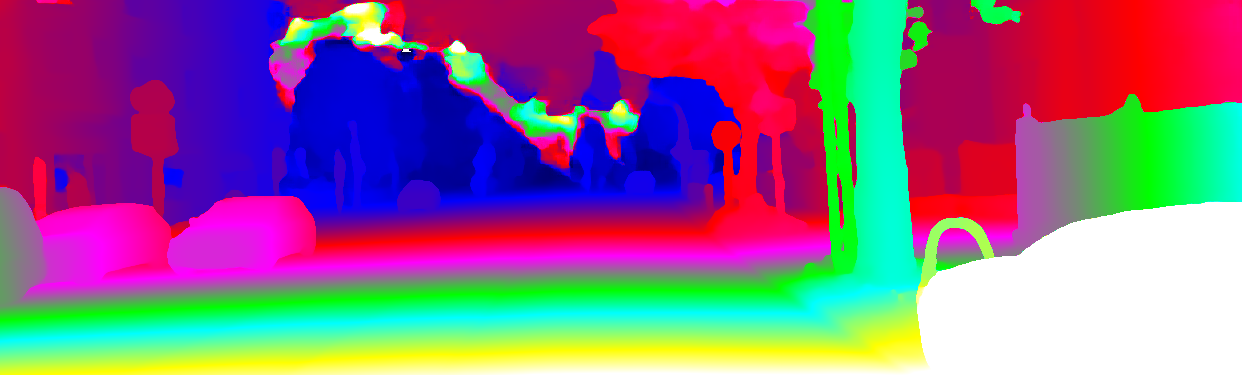
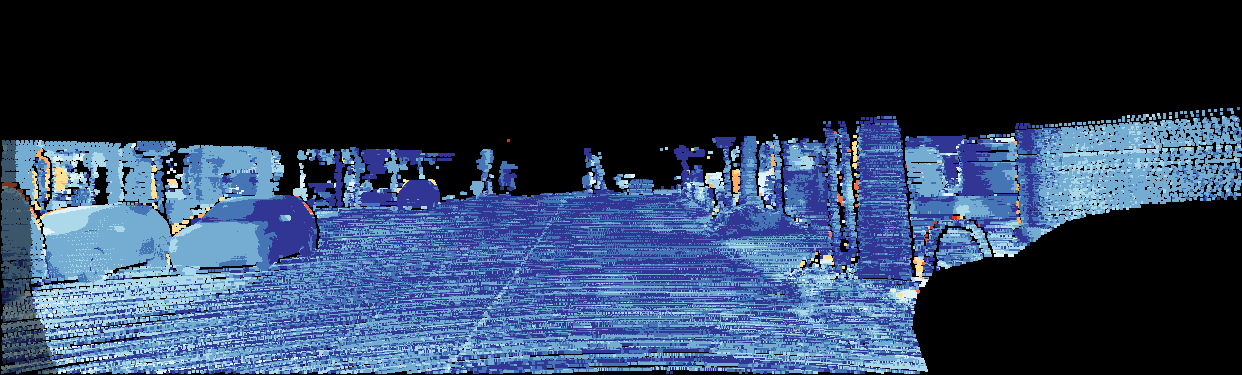
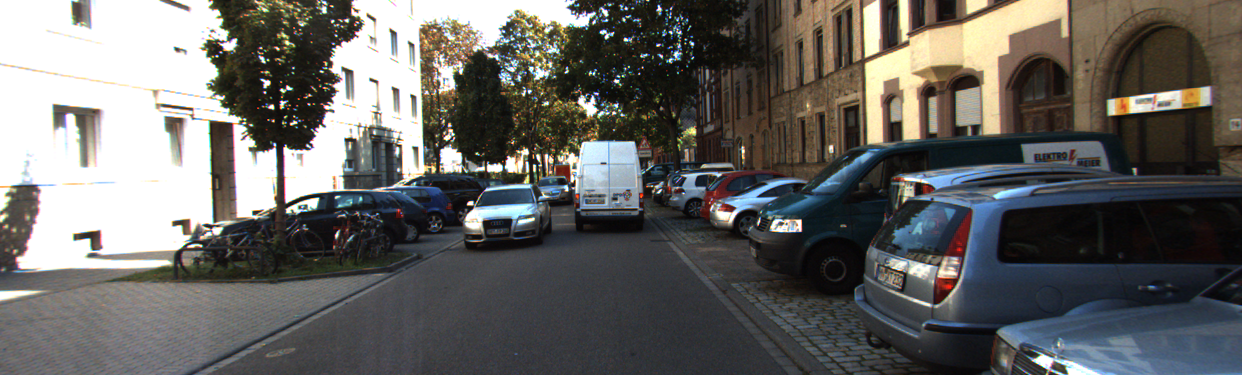
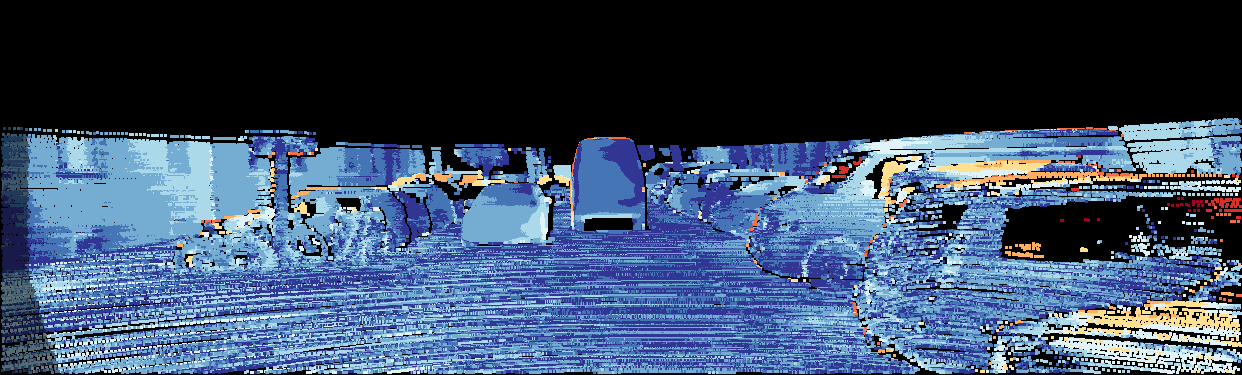
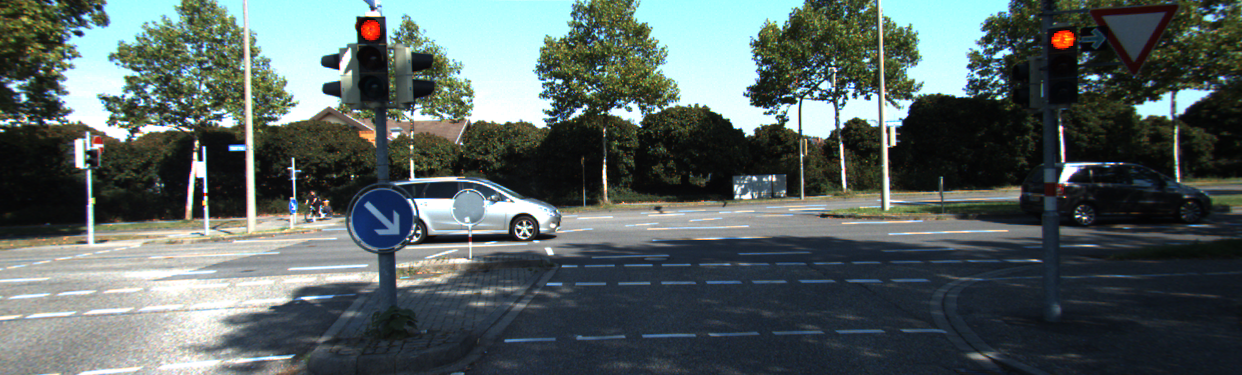
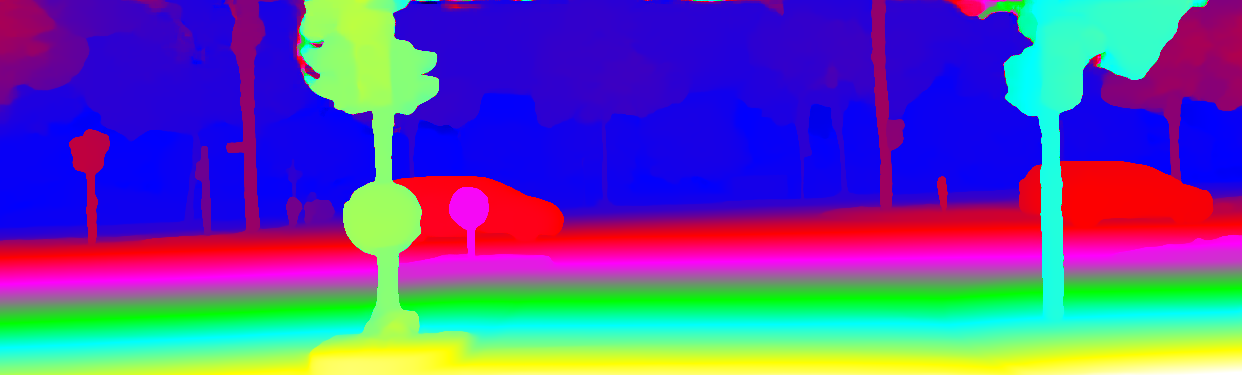
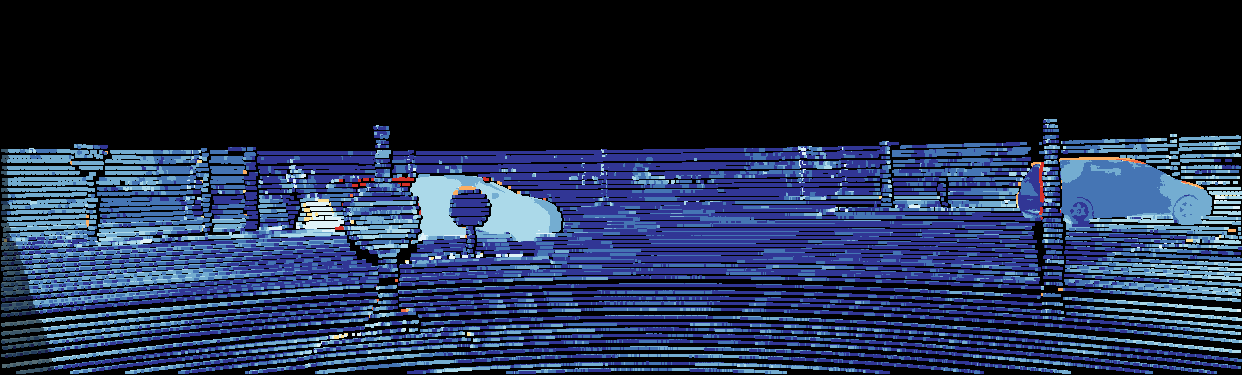
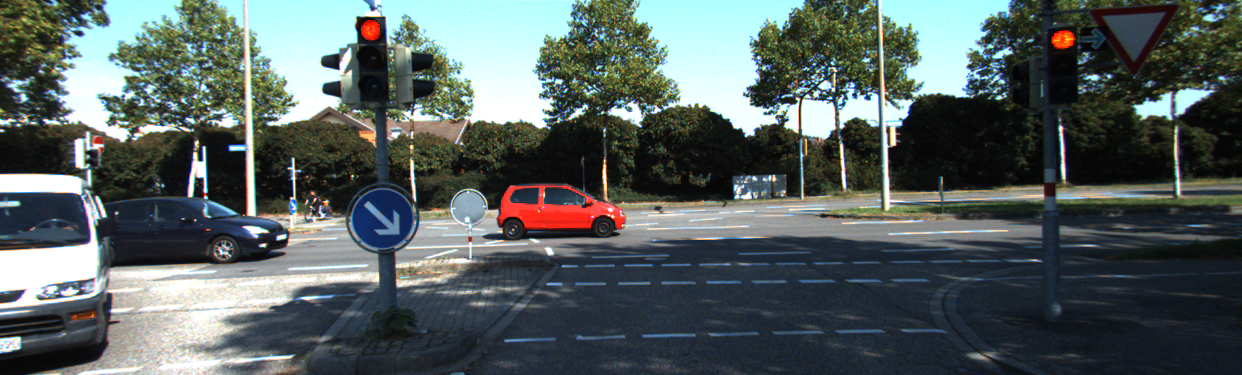
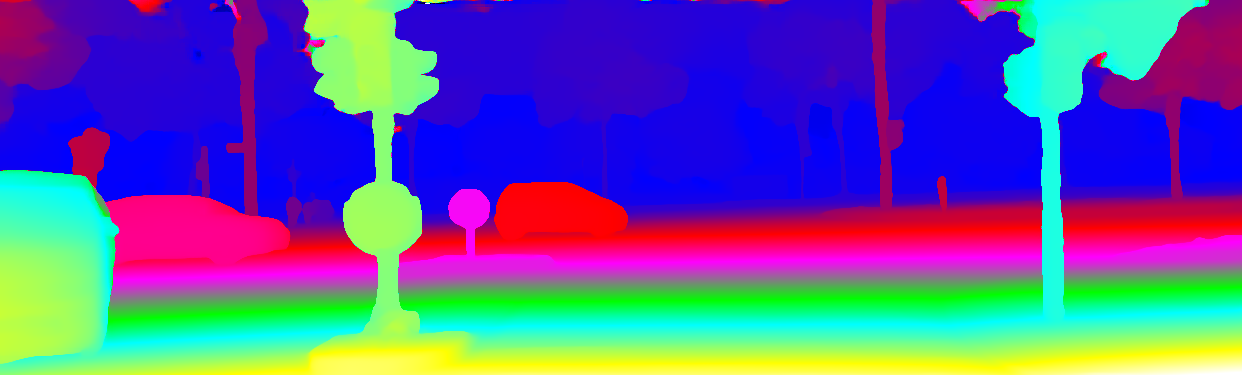
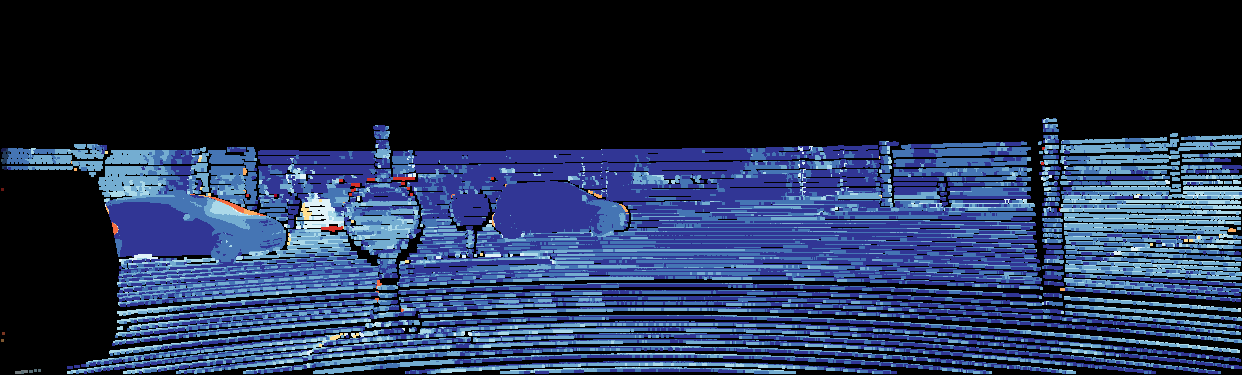
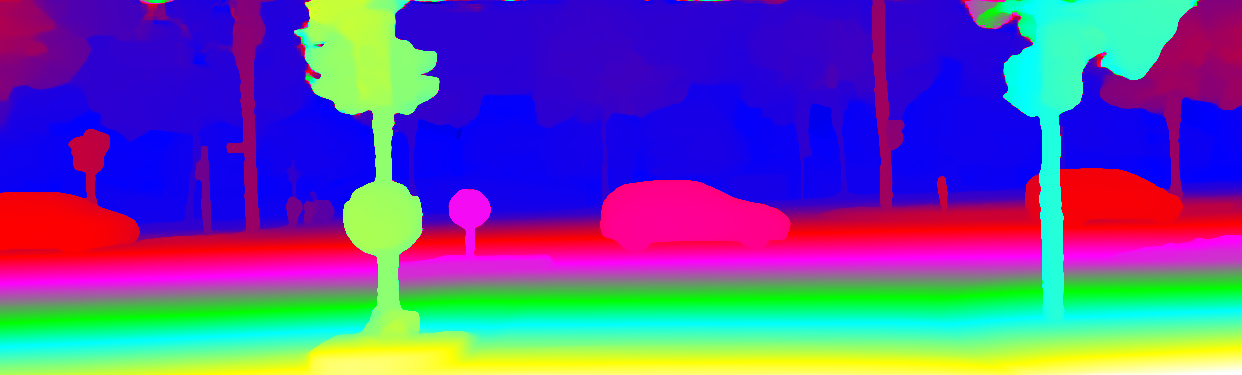
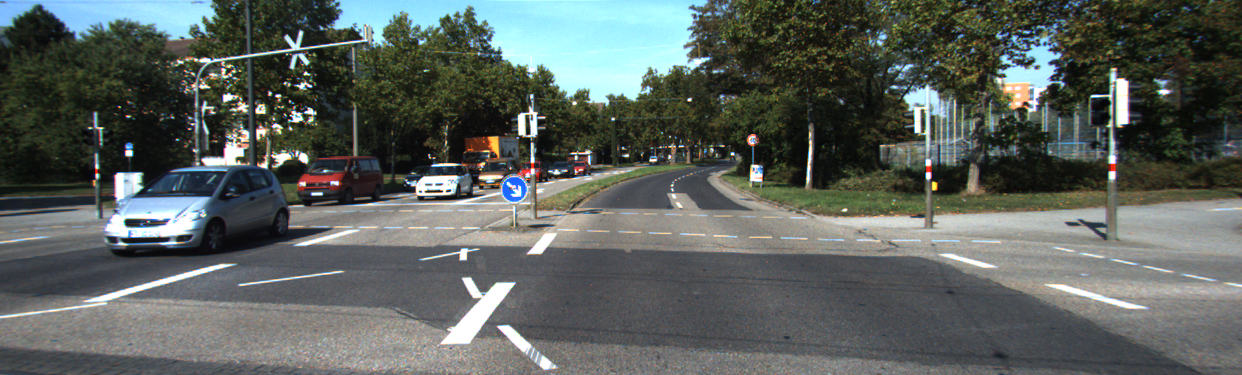
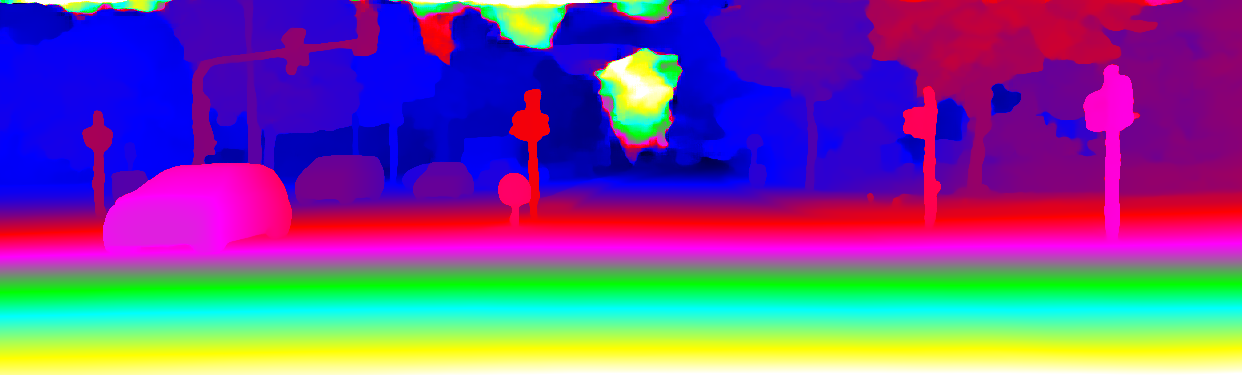
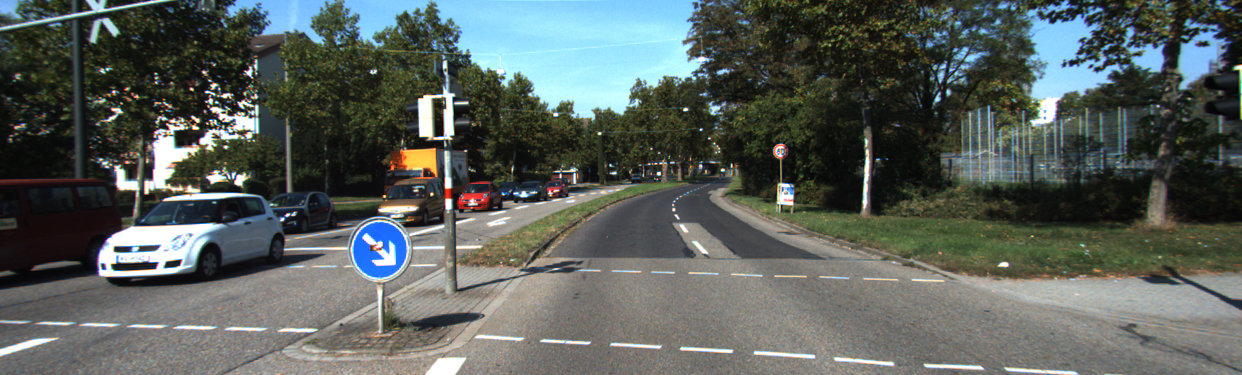
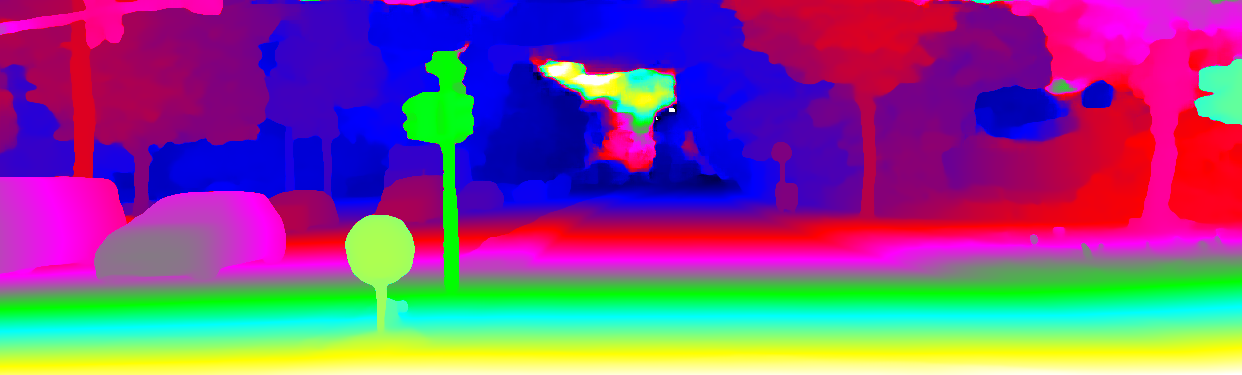
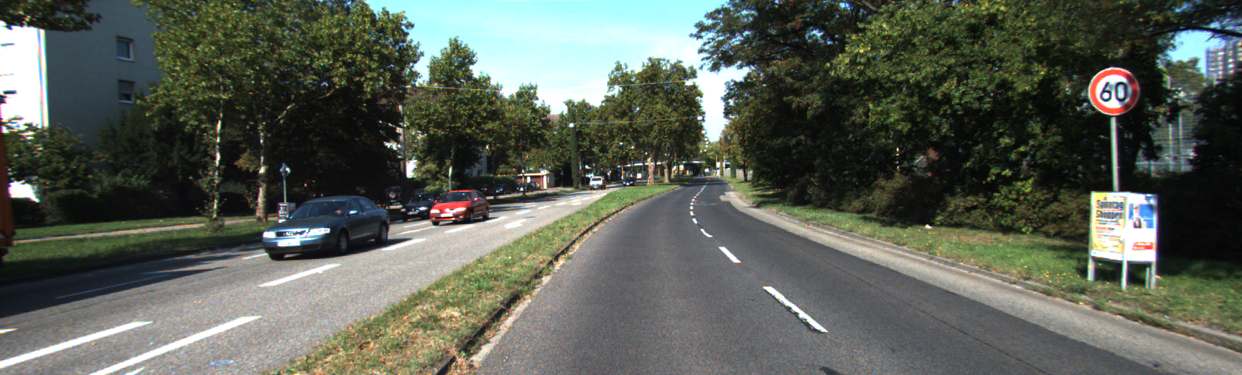
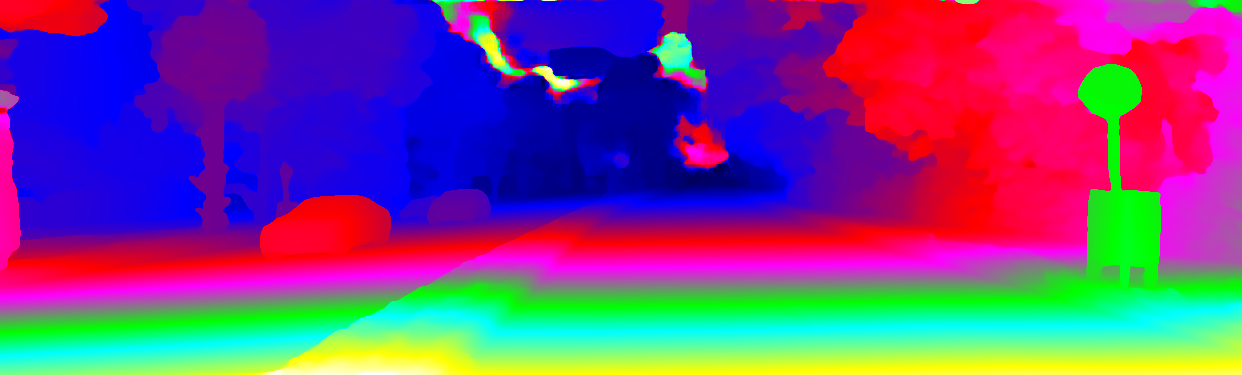
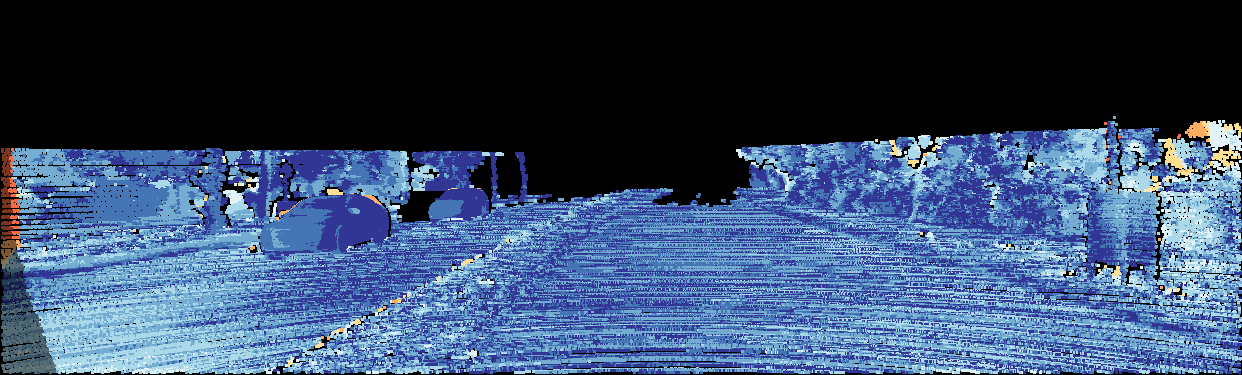
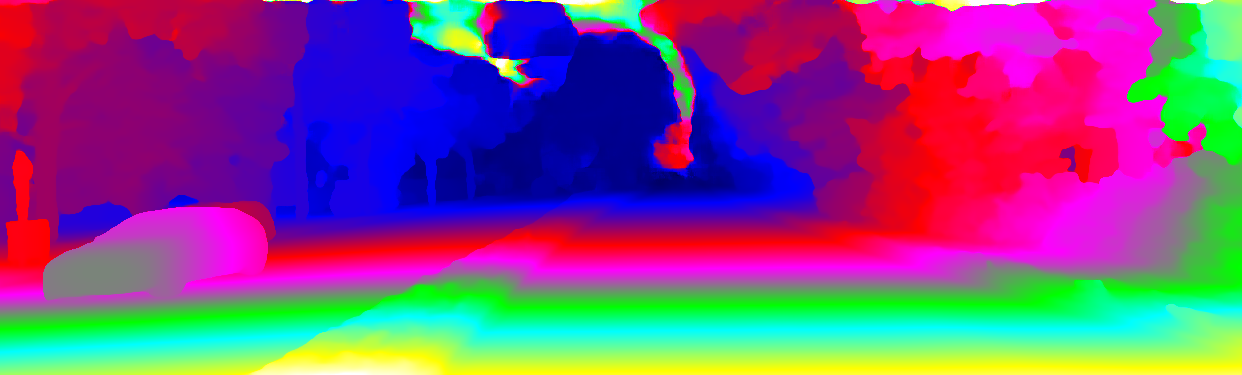
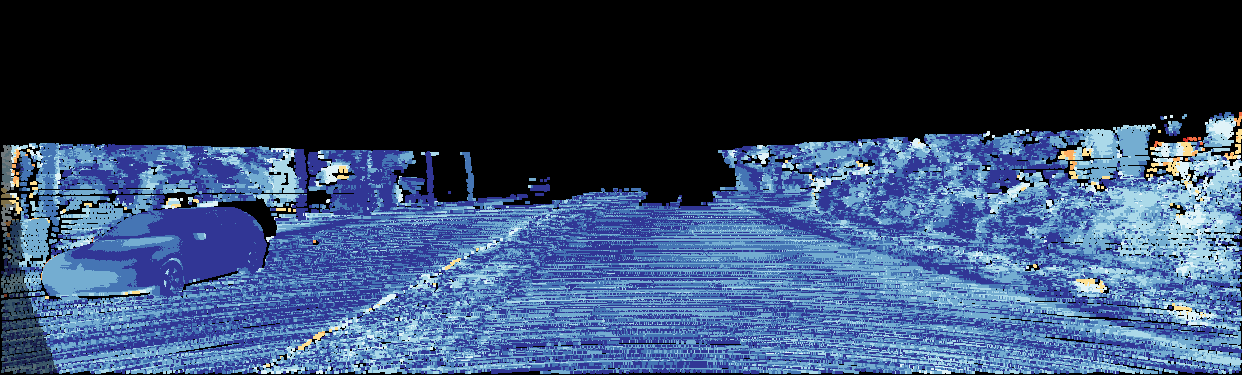
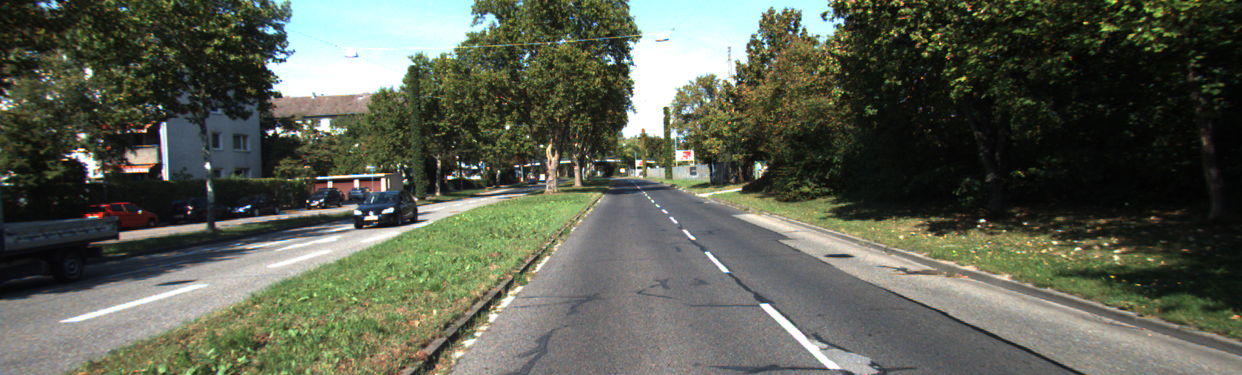
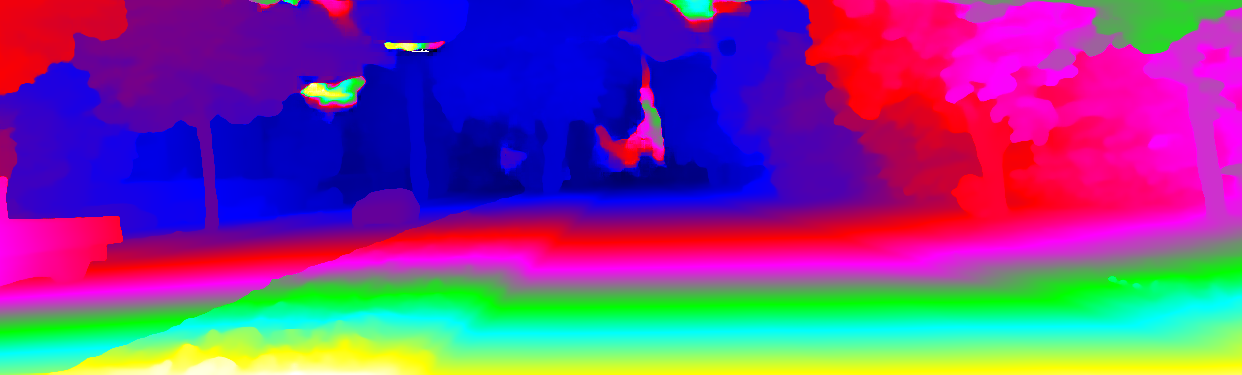
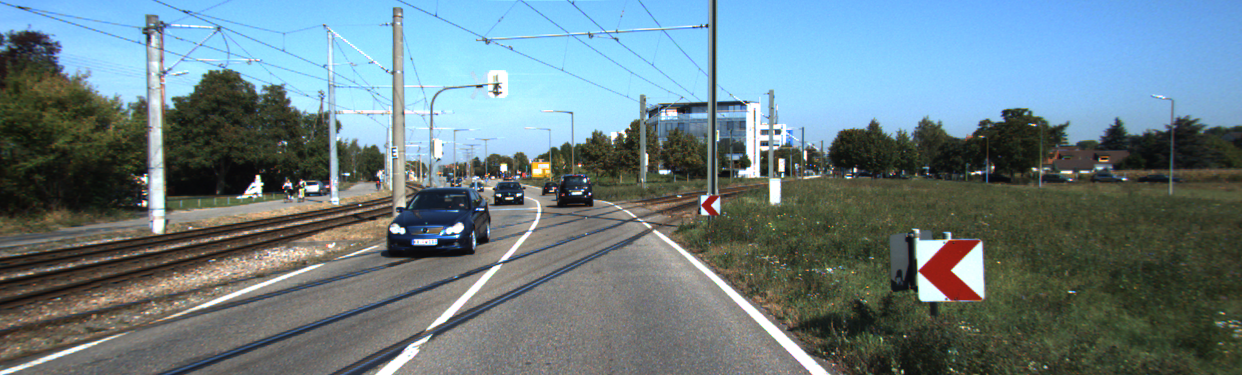
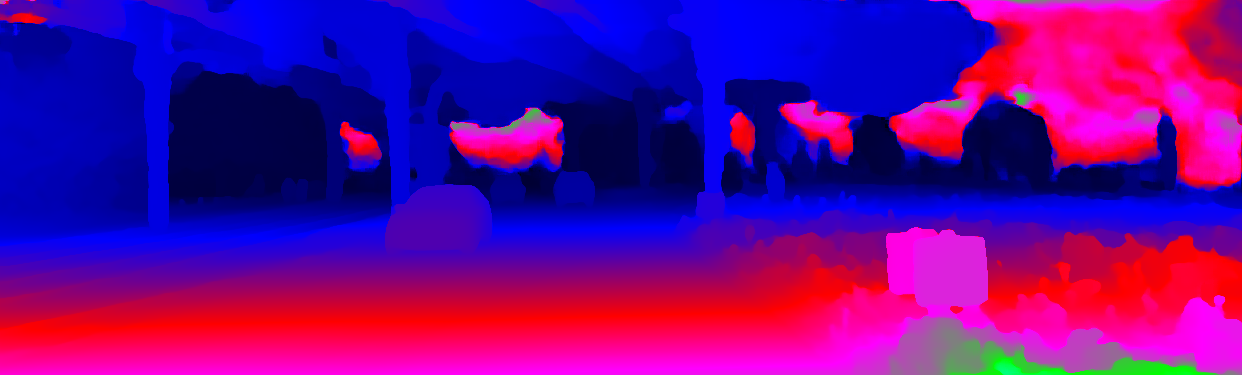
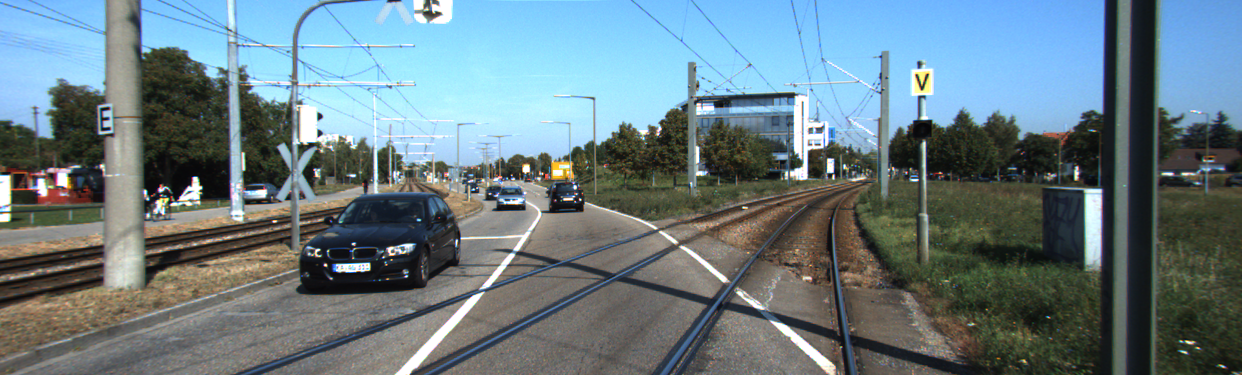
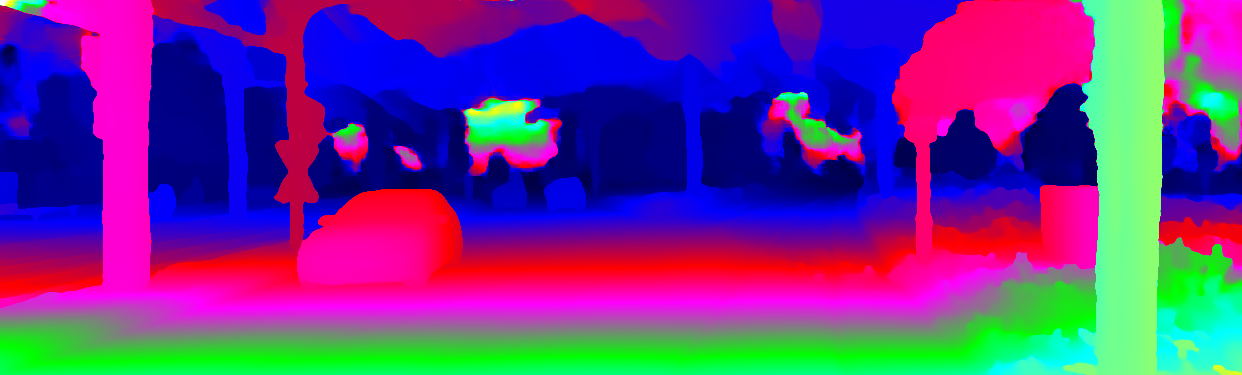
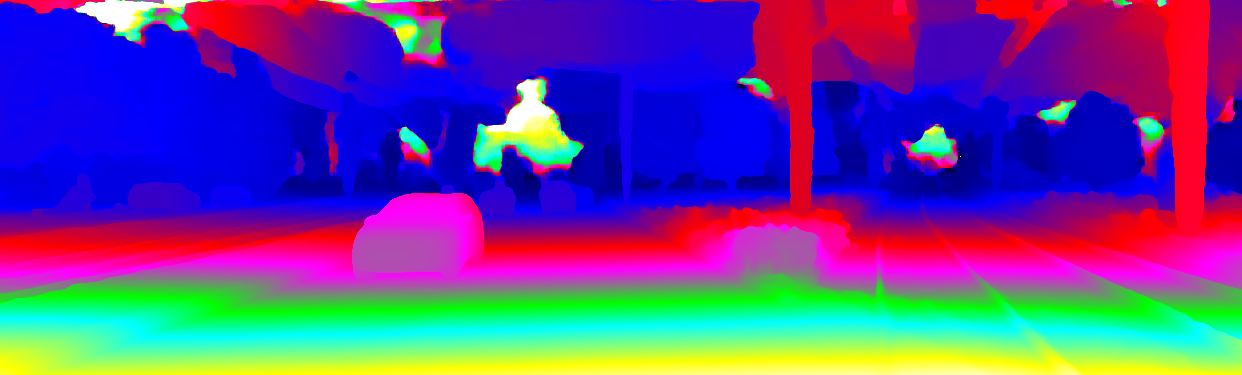
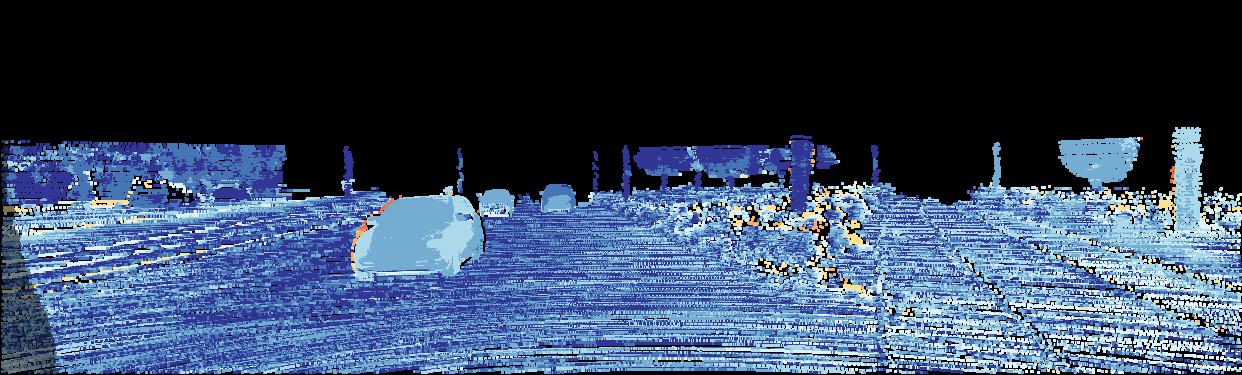
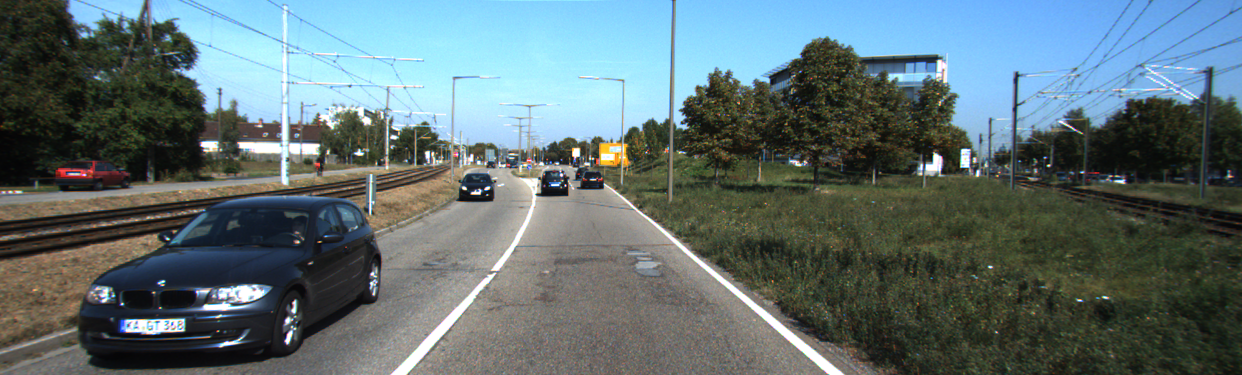
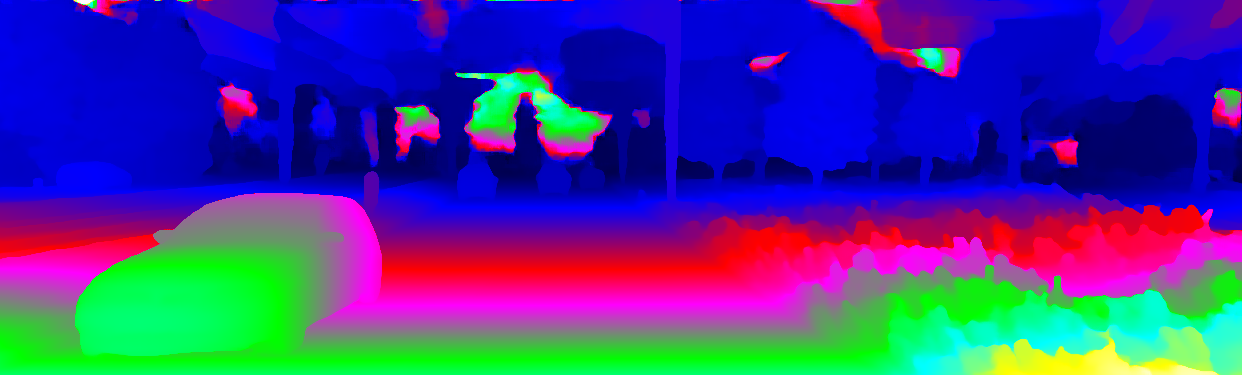
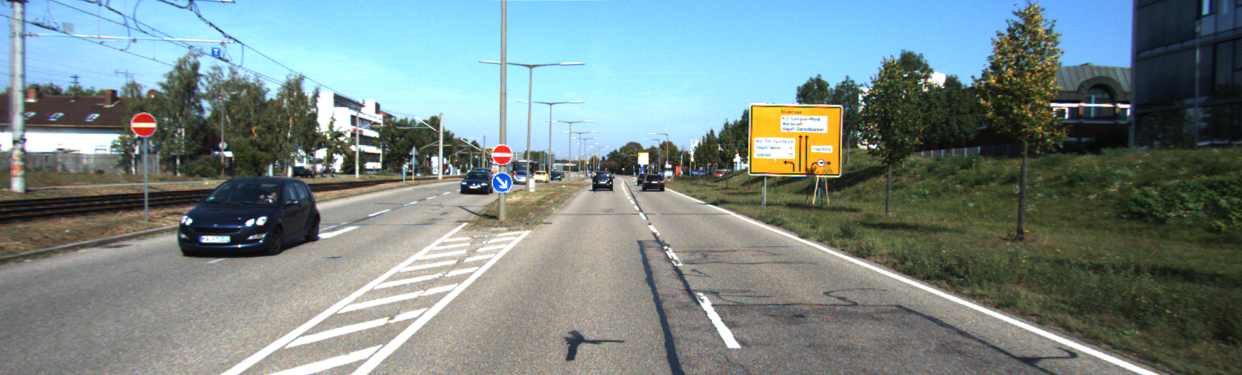
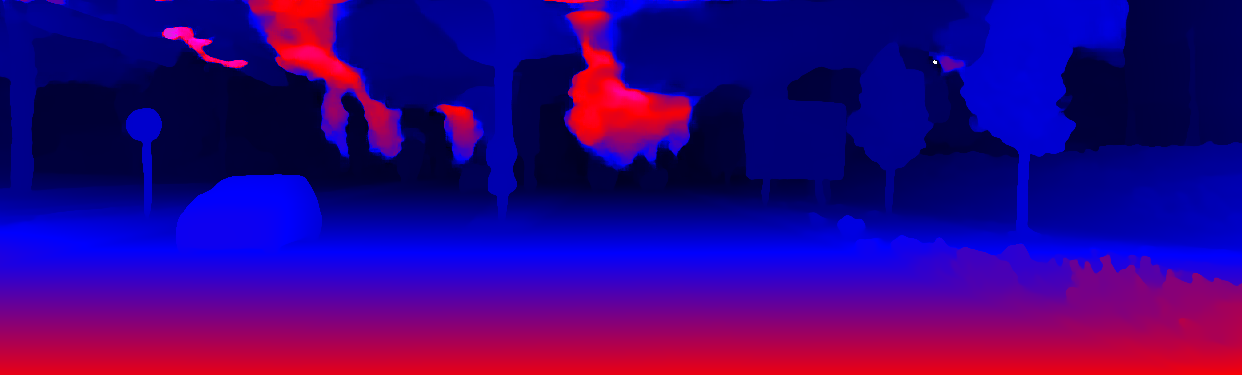
This page provides detailed results for the method(s) selected. For the first 20 test images, the percentage of erroneous pixels is depicted in the table. We use the error metric described in Object Scene Flow for Autonomous Vehicles (CVPR 2015), which considers a pixel to be correctly estimated if the disparity or flow end-point error is <3px or <5% (for scene flow this criterion needs to be fulfilled for both disparity maps and the flow map). Underneath, the left input image, the estimated results and the error maps are shown (for disp_0/disp_1/flow/scene_flow, respectively). The error map uses the log-color scale described in Object Scene Flow for Autonomous Vehicles (CVPR 2015), depicting correct estimates (<3px or <5% error) in blue and wrong estimates in red color tones. Dark regions in the error images denote the occluded pixels which fall outside the image boundaries. The false color maps of the results are scaled to the largest ground truth disparity values / flow magnitudes.

Test Set Average

Error D1-bg D1-fg D1-all
All / All 1.24 3.07 1.54
All / Est 1.24 3.07 1.54
Noc / All 1.13 3.01 1.44
Noc / Est 1.13 3.01 1.44
This table as LaTeX

Test Image 0

Error D1-bg D1-fg D1-all
All / All 1.47 1.57 1.48
All / Est 1.47 1.57 1.48
Noc / All 1.47 1.57 1.48
Noc / Est 1.47 1.57 1.48
This table as LaTeX

Input Image

D1 Result

D1 Error


Test Image 1

Error D1-bg D1-fg D1-all
All / All 1.72 3.30 1.90
All / Est 1.72 3.30 1.90
Noc / All 1.66 3.30 1.84
Noc / Est 1.66 3.30 1.84
This table as LaTeX

Input Image

D1 Result

D1 Error


Test Image 2

Error D1-bg D1-fg D1-all
All / All 1.70 8.99 2.06
All / Est 1.70 8.99 2.06
Noc / All 1.60 8.99 1.96
Noc / Est 1.60 8.99 1.96
This table as LaTeX

Input Image

D1 Result

D1 Error


Test Image 3

Error D1-bg D1-fg D1-all
All / All 1.68 1.27 1.64
All / Est 1.68 1.27 1.64
Noc / All 1.68 1.27 1.64
Noc / Est 1.68 1.27 1.64
This table as LaTeX

Input Image

D1 Result

D1 Error


Test Image 4

Error D1-bg D1-fg D1-all
All / All 0.58 0.65 0.59
All / Est 0.58 0.65 0.59
Noc / All 0.56 0.65 0.58
Noc / Est 0.56 0.65 0.58
This table as LaTeX

Input Image

D1 Result

D1 Error


Test Image 5

Error D1-bg D1-fg D1-all
All / All 1.45 2.36 1.53
All / Est 1.45 2.36 1.53
Noc / All 1.42 2.36 1.51
Noc / Est 1.42 2.36 1.51
This table as LaTeX

Input Image

D1 Result

D1 Error


Test Image 6

Error D1-bg D1-fg D1-all
All / All 2.49 2.09 2.45
All / Est 2.49 2.09 2.45
Noc / All 2.54 2.09 2.50
Noc / Est 2.54 2.09 2.50
This table as LaTeX

Input Image

D1 Result

D1 Error


Test Image 7

Error D1-bg D1-fg D1-all
All / All 0.27 2.94 0.79
All / Est 0.27 2.94 0.79
Noc / All 0.27 2.94 0.80
Noc / Est 0.27 2.94 0.80
This table as LaTeX

Input Image

D1 Result

D1 Error


Test Image 8

Error D1-bg D1-fg D1-all
All / All 0.24 1.71 0.51
All / Est 0.24 1.71 0.51
Noc / All 0.24 1.71 0.51
Noc / Est 0.24 1.71 0.51
This table as LaTeX

Input Image

D1 Result

D1 Error


Test Image 9

Error D1-bg D1-fg D1-all
All / All 0.36 1.20 0.57
All / Est 0.36 1.20 0.57
Noc / All 0.36 1.26 0.58
Noc / Est 0.36 1.26 0.58
This table as LaTeX

Input Image

D1 Result

D1 Error


Test Image 10

Error D1-bg D1-fg D1-all
All / All 1.08 2.29 1.36
All / Est 1.08 2.29 1.36
Noc / All 1.09 2.29 1.37
Noc / Est 1.09 2.29 1.37
This table as LaTeX

Input Image

D1 Result

D1 Error


Test Image 11

Error D1-bg D1-fg D1-all
All / All 0.59 0.31 0.54
All / Est 0.59 0.31 0.54
Noc / All 0.59 0.31 0.54
Noc / Est 0.59 0.31 0.54
This table as LaTeX

Input Image

D1 Result

D1 Error


Test Image 12

Error D1-bg D1-fg D1-all
All / All 0.69 1.15 0.72
All / Est 0.69 1.15 0.72
Noc / All 0.53 1.15 0.57
Noc / Est 0.53 1.15 0.57
This table as LaTeX

Input Image

D1 Result

D1 Error


Test Image 13

Error D1-bg D1-fg D1-all
All / All 0.53 0.18 0.49
All / Est 0.53 0.18 0.49
Noc / All 0.50 0.18 0.46
Noc / Est 0.50 0.18 0.46
This table as LaTeX

Input Image

D1 Result

D1 Error


Test Image 14

Error D1-bg D1-fg D1-all
All / All 1.46 0.39 1.44
All / Est 1.46 0.39 1.44
Noc / All 1.23 0.39 1.22
Noc / Est 1.23 0.39 1.22
This table as LaTeX

Input Image

D1 Result

D1 Error


Test Image 15

Error D1-bg D1-fg D1-all
All / All 2.43 0.37 2.24
All / Est 2.43 0.37 2.24
Noc / All 2.48 0.37 2.28
Noc / Est 2.48 0.37 2.28
This table as LaTeX

Input Image

D1 Result

D1 Error


Test Image 16

Error D1-bg D1-fg D1-all
All / All 3.33 0.00 2.84
All / Est 3.33 0.00 2.84
Noc / All 3.15 0.00 2.68
Noc / Est 3.15 0.00 2.68
This table as LaTeX

Input Image

D1 Result

D1 Error


Test Image 17

Error D1-bg D1-fg D1-all
All / All 0.88 0.00 0.79
All / Est 0.88 0.00 0.79
Noc / All 0.86 0.00 0.77
Noc / Est 0.86 0.00 0.77
This table as LaTeX

Input Image

D1 Result

D1 Error


Test Image 18

Error D1-bg D1-fg D1-all
All / All 4.07 0.73 2.48
All / Est 4.07 0.73 2.48
Noc / All 4.00 0.73 2.43
Noc / Est 4.00 0.73 2.43
This table as LaTeX

Input Image

D1 Result

D1 Error


Test Image 19

Error D1-bg D1-fg D1-all
All / All 0.63 0.73 0.64
All / Est 0.63 0.73 0.64
Noc / All 0.63 0.73 0.64
Noc / Est 0.63 0.73 0.64
This table as LaTeX

Input Image

D1 Result

D1 Error


eXTReMe Tracker