Important note: On September 7, 2026, the KITTI and KITTI-360 servers had to be restored to the backed-up state of August 7, 2026. Results within this period have to be resubmitted.

Method

PIXOR++ - LIDAR only [la] [UberATG-PIXOR++]


Submitted on 16 Sep. 2018 00:32 by
Bin Yang (University of Toronto)

Running time:0.035 s
Environment:GPU @ 2.5 Ghz (Python)

Method Description:
An improved PIXOR detector trained from scratch on KITTI
LIDAR training data only.
Parameters:
See the paper.
Latex Bibtex:
@inproceedings{Yang2018CoRL,
title = {HDNET: Exploiting HD Maps for
3D Object Detection},
author = {Bin Yang and Ming Liang and Raquel Urtasun},
booktitle = {2nd Conference on Robot Learning (CoRL)},
year = {2018}}

Detailed Results

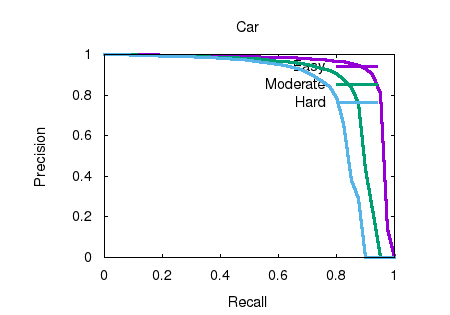
Object detection and orientation estimation results. Results for object detection are given in terms of average precision (AP) and results for joint object detection and orientation estimation are provided in terms of average orientation similarity (AOS).


Benchmark Easy Moderate Hard
Car (Bird's Eye View) 93.28 % 86.01 % 80.11 %
This table as LaTeX


Bird's eye view results.
This figure as: png eps pdf txt gnuplot


eXTReMe Tracker