Important note: On September 7, 2026, the KITTI and KITTI-360 servers had to be restored to the backed-up state of August 7, 2026. Results within this period have to be resubmitted.

Method

Point-Linked TriPlane (Lite) [TriPlane-Lite]


Submitted on 6 Oct. 2026 12:39 by
Haynes Li (University of Turku)

Running time:0.02 s
Environment:1 core @ 2.5 Ghz (C/C++)

Method Description:
LiDAR-only single-stage bird's-eye-view detector
with 0.92M parameters. Trained from scratch on KITTI
train+val (7,481 frames) with classification and
regression; single model, no extra data, no test-
time augmentation or ensembling.
Parameters:
BEV range x in [0, 70.4] m, y in [-40, 40] m, z in
[-3, 1] m; Adam, lr 1e-3, global batch 64, 60 epochs
(step decay at 42).
Latex Bibtex:
@inproceedings{anonymous2026pltp,
title = {Under review},
author = {Anonymous},
booktitle = {Under review},
year = {2026}
}

Detailed Results

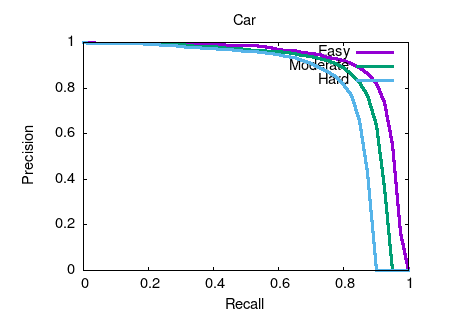
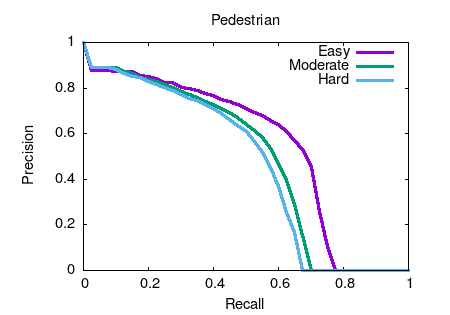
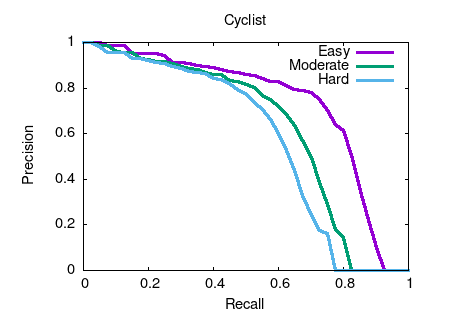
Object detection and orientation estimation results. Results for object detection are given in terms of average precision (AP) and results for joint object detection and orientation estimation are provided in terms of average orientation similarity (AOS).


Benchmark Easy Moderate Hard
Car (Bird's Eye View) 90.75 % 86.27 % 81.21 %
Pedestrian (Bird's Eye View) 53.79 % 47.44 % 44.96 %
Cyclist (Bird's Eye View) 72.65 % 61.47 % 56.23 %
This table as LaTeX


Bird's eye view results.
This figure as: png eps txt gnuplot


Bird's eye view results.
This figure as: png eps txt gnuplot


Bird's eye view results.
This figure as: png eps txt gnuplot


eXTReMe Tracker